
- Catalogs
- Wuxi Danikor Automation Technology Co.,Ltd
- Danikor Torque Arms


Danikor Torque Arms
Danikor Torque Arms
Overview
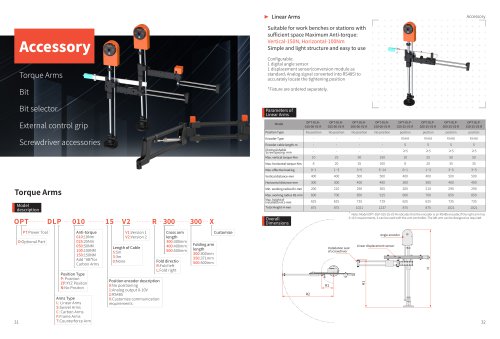
This document provides technical specifications and configuration options for various types of mechanical arms used in industrial applications, including Linear Arms and Torque Arms. It details parameters, encoder types, torque capacities, and accessory options.
1. Arm Types and Descriptions
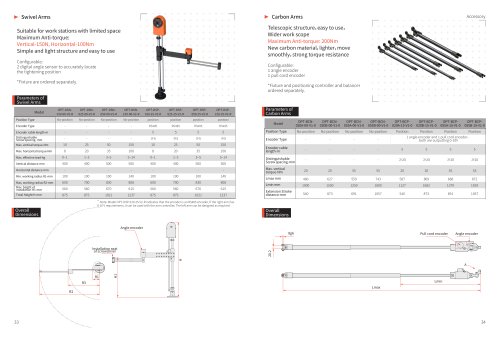
- Linear Arms (L): Suitable for workbenches or stations with ample space. They feature a simple, lightweight structure and are easy to use. Maximum anti-torque capacities are 150 Nm vertically and 100 Nm horizontally.
- Swivel Arms (S), Carbon Arms (C), Frame Arms (F), Counterforce Arms (T): Other arm types mentioned but not detailed in this excerpt.
2. Positioning and Encoder Options
- Position Types: P (Position), ZP (XYZ Position), N (No Position), O (Optional Part), PT (Power Tool Anti-torque).
- Encoder Types: No positioning, Analog output (0-10V), RS485 communication, and customizable communication options.
- Models with RS485 encoders are indicated with "R" in the model code.
- Encoder cable lengths are configurable, typically 1m or 3m, or none.
3. Torque and Load Parameters
- Maximum vertical torque ranges from 10 Nm to 150 Nm depending on the model.
- Maximum horizontal torque ranges from 10 Nm to 100 Nm.
- Maximum effective load and torque values vary by model and are specified in tables (not fully visible).
4. Model Coding and Customization
- Model codes follow a pattern such as OPT-DLP-XXX-XX-VX-R, where:
- OPT: Product prefix
- DLP/DLN: Arm type (Linear or Torque)
- XXX: Torque or size parameter
- XX: Positioning or encoder type
- VX: Version number
- R: RS485 encoder
- Additional suffixes like "AB" indicate Carbon Arms.
- Cable length and fold direction (R for fold left, L for fold right) are customizable.
5. Accessories and Additional Components
- Bit selectors, external control grips, screwdriver accessories, and installation seats are available as separate orders.
- Linear displacement sensors and angle encoders are used for precise positioning.
6. Dimensional Parameters
- Key dimensions include vertical distance, horizontal distance, minimum and maximum working radius (R1 and R2), installation height (H1), and total height (H).
- Folding arm lengths and cross arm lengths are specified for different models.
Critical Notes and Recommendations
- Models with RS485 encoders can be integrated with arm controllers, with flexibility in left or right arm design.
- Fixtures are ordered separately and are necessary for installation.
- Analog signals from displacement sensors are converted to RS485 for accurate tightening position detection.
Catalog excerpts

Linear Arms Suitable for work benches or stations with sufficient space Maximum Anti-torque: Vertical-150N, Horizontal-lOONm Simple and light structure and easy to use 1 digital angle sensor 1 displacement sensor(conversion module as standard, Analog signal converted into RS485) to accurately locate the tightening position ‘Fixture are ordered separately. Torque Arms Model Anti-torque 010:10Nm 025:25Nm 050:50NM 100:100NM 150:150NM Add "AB"for Carbon Arms Position Type P: Position ZP:XYZ Positon N:No Positon Fold directio R:Fold left L:Fold right Customize Folding arm length 300:300mm Arms Type L: Linear Arms S:Swivel Arms C: Carbon Arms F:Frame Arms T:Counterforce Arm Position encoder description 0:No positioning 1:Analog output 0-10V 2:RS485 X:Customize communication requirements
Open the catalog to page 1All Wuxi Danikor Automation Technology Co.,Ltd catalogs and technical brochures
 Danikor Prodcuts Catalog
2 Pages
 Danikor Company Profile
46 Pages
 Flexible Feeding System
2 Pages
 Industrial Torque Screwdriver
29 Pages
 Screw Dispenser/Screw Presenter
2 Pages
 TTA PTT-ASF Series
5 Pages
 Step Feeder
4 Pages
 Flexible Feed System
7 Pages
 Vibration Bowl Feeder
3 Pages
 Disc Feeder
5 Pages
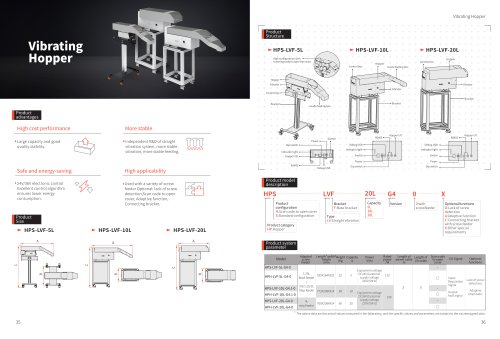 Danikor Vibrating Hopper
1 Page
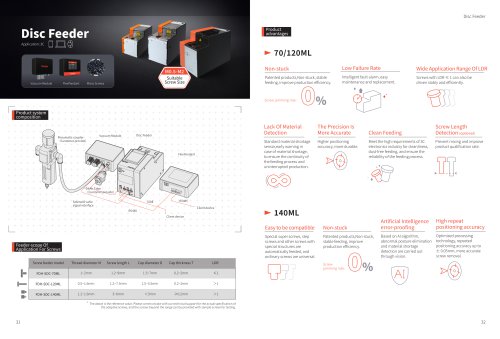 Danikor Disc Feeder
1 Page
 Danikor Step Feeder
1 Page
 Danikor Vacuum module
1 Page
 Danikor Frame Arms
1 Page
 Flexible Feeding System
2 Pages
 Smart Electric Screwdriver
14 Pages


- Danikor feeder
- Measurement software
- Danikor electric screwdriver
- Danikor brushless electric screwdriver
- Danikor corded electric screwdriver
- Danikor straight electric screwdriver
- Danikor automatic feeder
- Danikor DC electric screwdriver
- Vibratory feeder
- Danikor bulk material feeder
- Cordless electric screwdriver
- Pistol electric screwdriver
- Danikor electric screwdriver with torque control
- Calibration software
- Danikor semi-automatic electric screwdriver
- Danikor automatic electric screwdriver
- Danikor screwing unit
- Battery-powered electric screwdriver
- Danikor compact feeder