
- Catalogs
- TWK-ELEKTRONIK GmbH
- Rotary encoder TBN42/C3 manual
Rotary encoder TBN42/C3 manual

Rotary encoder TBN42/C3 manual
This document provides detailed specifications for absolute rotary encoders and switching cam encoders with a CANopen interface, specifically models NOCN, HBN, and TBN/TRN. These encoders are designed for high-resolution applications and comply with CANopen EN50325-5 standards, including both safety and non-safety interfaces.
The encoders are intended for precise angular or linear position measurements in safety-relevant systems. Installation and operation should be performed by qualified electricians following the provided documentation.
The document details various encoder types, including switching cam encoders and rotary encoders with slewing ring functionality. It covers electrical specifications, environmental data, and mechanical requirements, emphasizing dust and moisture resistance, vibration shock tolerance, and electromagnetic compatibility (EMC).
The encoders support CANopen communication with redundant position registration systems and error handling mechanisms. Error codes for sensor, cam, supply voltage, and device errors are specified, along with CANopen emergency messages.
This section outlines the CANopen profile, including safety-relevant data objects (SRDOs), process data objects (PDOs), and communication service data objects. It details node ID configuration, baud rates, and other parameters for integrating the encoders into a CANopen network.
Guidance is provided for initial setup, including adjusting node-ID and baud-rate settings to align with controller specifications. Instructions for setting the encoder to preoperational mode and configuring it for operational use are included.
The encoders are designed for safety-relevant systems, functioning in harsh environments to provide position data via a CAN interface. They connect to control systems that evaluate transmitted data and react to errors to prevent hazardous states.
The encoder consists of a position registration module, evaluation unit, switching cam encoder module, and an absolute encoder module. It features redundant position registration and secure data transfer via CANopen Safety.
1. Switching Cam Encoder: Includes switching outputs and uses all CANopen objects described in the specifications.
2. Rotary Encoder: Excludes switching outputs and certain CANopen objects. Available in singleturn or multiturn versions.
3. Rotary Encoder with Slewing Ring Functionality: Special software for slewing ring applications, using specific CANopen objects for gear parameters.
The document outlines various objects and parameters for configuration, including cam settings, diagnosis objects, and parameterization examples. Detailed instructions are provided for setting parameters like code sequence, number of teeth, and measuring range.
Includes recommendations for parameterization and examples for setting safety position and speed configuration parameters, cam limits, and behavior in case of errors.
The document outlines error codes and types for a redundant sensor system, detailing channel numbers and error types, including communication and sensor errors.
Detailed specifications for various error types and codes, including cam errors, supply voltage errors, and device errors, are provided.
An overview of objects contained in the encoder profile, including communication profile area, safety CAN objects, and encoder objects, is provided.
SRDO1 and SRDO2 are defined for transmitting position and speed data, respectively, with specified formats and cyclic transmission.
The document describes the output of measured position and speed values in PDOs, detailing the byte structure for data transmission.
Procedures for modifying the encoder via SDO communication are outlined, including setting the device to preoperational and waiting for response messages.
Objects provide manufacturer-specific information such as device name, hardware version, and software version.
Procedures for storing and restoring parameters, including the use of passwords and sub-index specifications for different parameter groups, are detailed.
- Loading Default Parameters: Default parameters are loaded from ROM upon entering the correct password. Node IDs exceeding 32 require manual entry of COB IDs.
- COB-ID-EMCY: Used for emergency messages, set to COB-ID-EMCY + node ID after loading defaults.
- Inhibit Time EMCY: Limits bus load during rapid EMCY messages.
- Producer Heartbeat Time: Heartbeat messages are transmitted at defined intervals if set above zero.
- Identity Object: Contains manufacturer ID, product code, revision number, and serial number.
- Error Behaviour Object: Defines actions in case of errors, with specific settings for redundancy and cam errors.
- SRDOs: Active when configuration_valid is set to 0xA5. The enable bit in the COB ID structure determines SRDO activation.
- SRDO Communication Parameters: Modifications require recalculating and transmitting a new CRC checksum.
- Transmit PDO Asynchronous: Processes asynchronous and cyclical events.
- Transmit PDO Synchronous: Processes synchronous events without an inhibit timer or event timer.
- SRDO Mapping Parameters: Defines coding for each mapping object with specified lengths in hex.
- Transmit PDO Mapping: Similar to SRDO mapping, defining coding for each mapping object.
- Configuration Valid: Reset each time a safety relevant parameter is accessed. Entering 0xA5 validates the configuration.
Procedures for managing checksums and configuration validity for safety CAN parameters are outlined. A special TWK program is recommended for calculating the CRC checksum.
The node ID and bit rate for the CAN bus are configurable parameters, requiring a power reset to take effect.
Objects are defined for specific configurations, such as cam_valid_flag and gear_valid_flag, which ensure the validity of cam and gear parameters.
Parameters for position and speed, including operating parameters, measuring units per revolution, and total measuring range, are specified.
Safety objects define the behavior of the position registration system, requiring recalculating and transmitting a new CRC checksum for changes.
- Object 6101 - Safety Speed Configuration Parameters: Manages speed measurement behavior in safety areas.
- Object 6120 - Safety Standard Position Value: Contains the current position used in SRDO mapping.
- Object 6121 - Safety Inverted Position Value: Contains bit-inverted position values.
- Object 6124 - Safety Speed Value: Holds the current measured speed value for SRDO mapping.
- Object 6125 - Safety Inverted Speed Value: Contains bit-inverted speed values.
- Object 61FE - Safety Configuration Valid: A confirmation flag for valid configuration.
- Object 61FF - Safety Configuration Signature: Contains the checksum for safety encoder parameters.
- General Information: Cam parameters are writable only in the PRE-OPERATIONAL state with the cam function deactivated.
- Object 6300 - Cam State Register: Indicates active cam range.
- Object 6301 - Cam Enable Register: Allows enabling/disabling cams.
- Object 6302 - Cam Polarity Register: Changes cam polarity.
- Object 6310 - Cam 1 Low Limit: Activates cam state when reached.
- Object 6320 - Cam 1 High Limit: Deactivates cam state when exceeded.
- Object 6330 - Cam 1 Hysteresis: Prevents constant state changes due to minor position changes.
Uses a generator polynomial and processes objects in ascending order. The TWK program is recommended for CRC calculation.
This document outlines the specifications for NOCN, HBN, and TBN/TRN systems, focusing on various parameters and configurations for safety encoders.
Each cam has a hysteresis setting with a number of available channels set to 1 and a hysteresis channel value of 10.
- Singleturn resolution: 4096
- Number of distinguishable revolutions: 4096
- Supported alarms and warnings are specified with hexadecimal values.
Includes cam and gear safety configurations with specific sub-indexes and CRC checksums for validation.
Recommended steps for parameterizing safety encoders include setting position parameters, cam parameters, and SRDO parameters.
Specific steps are provided for setting gear parameters, including the number of teeth for slewing rings and pinions.
Screenshots and examples are provided for calculating CRC checksums using the TWK program.
Detailed examples are provided for setting safety position configuration parameters.
- Configuration Activation: Steps to activate and deactivate configuration flags using specific command specifiers and byte sequences.
- Parameter Setting: Instructions for setting safety speed integration time, cam limits, hysteresis, enable and polarity registers, and SRDO communication and speed parameters.
- Checksum Calculation: Procedures for calculating CRC checksums using the TWK program.
- Operational Settings: Steps to set devices to preoperational and operational states.
- Redundant Encoder Behavior: Describes the behavior of full redundant encoders in case of errors.
- Error Recognition: Guidance on recognizing error/emergency messages in traces and object 1003.
- Node ID: Set to 0x11 (17dez).
- Bit Rate: Set to 0x2 (500 kbps).
- COB-IDs: Specific COB-IDs for SRDO1 and SRDO2 are calculated based on node ID.
Catalog excerpts

SUPREME SENSORING TWK Document no: NOC 13100 UE Date: 12.06.2019 Specifications - NOCN, HBN and TBN/TRN for absolute rotary encoders and switching cam encoders with CANopen interface Specifications Rotary encoders Switching cam rotary encoders Slewing ring rotary encoders High resolution rotary encoders Type NOCN, HBN and TBN/TRN with CANopen safety / non-safety interface Profile (S0, S1, S2), S3, S4, C2, C3 CANopen EN50325-5 (Formerly CiA DS304) TWK-ELEKTRONIK GmbH BismarckstraBe 108 [email protected] visit us at | twk.de
Open the catalog to page 1
Specifications NOCN, HBN and TBN/TRN Safety instructions Scope This specification is valid exclusively for the following absolute encoders / switching cam encoders with CANopen (safety) interface: - NOCN, HBN and TBN/TRN with safety architecture (SIL2) Documentation The following documents must be observed: - The owner's system-specific operating instructions - This specification NOC13100 - Data sheet numbers NOC13099 NOC13292 HBN13218 TBN/TRN14271 (and other ones) - The connection assignment enclosed with every device Proper use The TWK-ELEKTRONIK GmbH absolute encoders and linear transducers...
Open the catalog to page 2
Specifications NOCN, HBN and TBN/TRN Date: 12.06.2019 Page 3 of 86 Document no. NOC 13100 UE
Open the catalog to page 3
Specifications NOCN, HBN and TBN/TRN Date: 12.06.2019 Page 4 of 86 Document no. NOC 13100 UE
Open the catalog to page 4
Specifications NOCN, HBN and TBN/TRN Only valid for NOCN with cams. Only valid for NOCN with slewing ring functionality
Open the catalog to page 5
Date: 12.06.2019 Page 6 of 86 Document no. NOC 13100 UE
Open the catalog to page 6
Specifications NOCN, HBN and TBN/TRN 1 Intended use The rotary encoder resp. switching cam encoder is intended for use in safety-relevant systems. The version without cams provides a safety rotary encoder in singleturn or multiturn design with a huge number of different flange an shaft designs (See datasheets NOC13099, NOC13292, HBN13218 and TBN/TRN14271, etc.). Thanks to its robust design, the switching cam encoder can be used in applications with harsh environmental conditions. Thanks to the combination of two relays per cam and the use of corresponding monitoring functions, the device offers...
Open the catalog to page 7
Specifications NOCN, HBN and TBN/TRN 3 Device versions The device designation nomenclature is defined in the NOC13099, NOC13292, HBN13218 and TBN/TRN14271 data sheet. Rotary encoder NOCN including switching outputs. All of the CANopen objects described in these specifications are used including all valid flags (13FE, 30FE and 61FE). All programming examples in chapter 11 and 12 are used. Rotary encoder Rotary encoder NOCN without switching outputs and high resolution encoder HBN, TBN/TRN. None of the CANopen objects described in these specifications concerning the switching outputs (Cams) are...
Open the catalog to page 8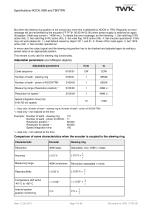
Specifications NOCN, HBN and TBN/TRN But when the slewing ring position is not correct any more this is detected by NOCN or TRN. Regularily an error message will be transmitted by the encoder (FF FF 81 00 80 04 02 00) when power supply is switched on again (Exception: Shaft was turned n * 4096 rev.). To delete this error message, do the following: 1. Set valid flag 31FE active (A5). 2. Set valid flag 61FE active (A5). 3. Set valid flag 13FE active (A5). 4. Set encoder operational. If this may not work please do: 1. Load default values by object 1011, sub 01.2. Power off/on reset again. 3. Set...
Open the catalog to page 9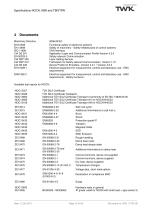
Specifications NOCN, HBN and TBN/TRN SUPREME SENSORING 4 Documents Machinery Directive 2006/42/EC Functional safety of electronic systems Safety of machinery - Safety-related parts of control systems CAN Interface. Application Layer and Communication Profile Version 4.2.0 Safety-relevant Communication. Layer Setting Service. Framework for Safety-relevant Communication Version 1.01. Device Profile for Encoders, Version 4.0.1 / Version 4.0.2 Electrical equipment for measurement, control and laboratory use - EMC requirements Electrical equipment for measurement, control and laboratory use - EMC...
Open the catalog to page 10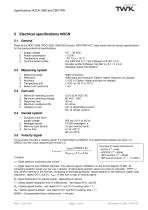
Specifications NOCN, HBN and TBN/TRN SUPREME SENSORING 5 Electrical specifications NOCN 5.1 General Refer to the NOC13099, NOC13292, HBN13218 and/or TBN/TRN14271 data sheet and the variant specifications for the precise electrical specifications. 1. Supply voltage 2. Power consumption 3. Temperature range 4. Communication profile 5.2 Measuring system 1. Measuring range 2. Resolution 3. Accuracy 4. Temperature drift 5. Sensor unit cycle time 9 V ... 36 VDC < 2.5 W - 40° C to + 70° C Full CAN Part A (11-bit) CANopen CiA 301 V 4.2 Encoder profile CANopen CiA 406 V 4.0.1 / V 4.0.2 CANopen Safety...
Open the catalog to page 11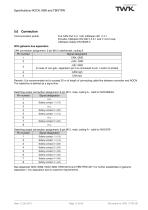
Specifications NOCN, HBN and TBN/TRN Communication profile Full CAN Part A (11-bit) CANopen 301 V 4.1 Encoder CANopen DS 406 V 4.0.1 and V 4.0.2 resp. CANopen Safety EN 50325-5 With galvanic bus separation CAN connection assignment: 5-pin M12 male/female, coding A See datasheet NOC13099, NOC13292, HBN13218 and TBN/TRN14271 for further possibilities of galvanic separation / non separation due to customer requirements. Date: 12.06.2019 Page 12 of 86 Document no. NOC 13100 UE
Open the catalog to page 12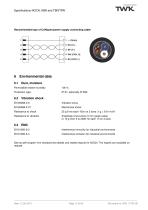
Specifications NOCN, HBN and TBN/TRN SUPREME SENSORING Recommended type of CANopen/power supply connecting cable: 6 Environmental data 6.1 Dust, moisture Permissible relative humidity Protection type: 6.2 Vibration shock EN 60068-2-6 EN 60068-2-27 Resistance to shock Resistance to vibration 6.3 EMC EN 61000-6-2 EN 61000-6-4 Vibration sinus Mechanical shock 25 g 6 ms each 100x on 3 axes (1 g = 9.81 m/s2) Amplitude of excursion 5 mm (peak value) or 10 g from 5 to 2000 Hz each 1 h on 3 axes Interference immunity for industrial environments Interference emission for industrial environments See as...
Open the catalog to page 13
Specifications NOCN, HBN and TBN/TRN 7 Mechanical system The mechanical dimensions are specified in data sheet NOC13099, NOC13292, HBN13218 and/or TBN/TRN14271 or in related drawings due to special mechanical designs. Date: 12.06.2019 Page 14 of 86 Document no. NOC 13100 UE
Open the catalog to page 14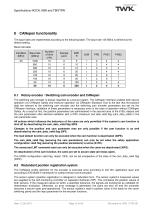
Specifications NOCN, HBN and TBN/TRN 8 CANopen functionality The baud rates are implemented according to the following table. The baud rate 125 kBit/s is defined as the default setting. Baud rate table 8.1 Rotary encoder / Switching cam encoder and CANopen The switching cam encoder is always regarded as a secure system. The CANopen interface enables both secure operation via CANopen Safety and insecure operation via CANopen Standard. Due to the fact that the position data are relevant to the switching cam encoder and the switching cam encoder parameters are set via the CANopen interface, validation...
Open the catalog to page 15All TWK-ELEKTRONIK GmbH catalogs and technical brochures
 Rotary encoder TBN58/C3 manual
50 Pages
 Rotary encoder TBN58/C3
22 Pages
 Rotary encoder TBD Manual
26 Pages
 Rotary encoder TBD
12 Pages
 Rotary encoder TBE58
16 Pages
 Rotary encoder KRP - Manual
19 Pages
 Rotary encoder KRP
7 Pages
 Rotary encoder TBN58/S4 SIL2
22 Pages
 Rotary encoder TBN50/C3 manual
20 Pages
 Rotary encoder TBN50/C3
22 Pages
 Rotary encoder HBN/S3 SIL2
16 Pages
 Product range 2022
64 Pages
 Image brochure TWK
28 Pages
 Inclinometer NBA51
6 Pages
 Incremental encoder FOI
7 Pages
 Rotary encoder TBA42
16 Pages
 Rotary encoder TRA42
16 Pages
 Rotary encoder TRN58/S4 SIL2
22 Pages
 Rotary encoder TRN58/C3 manual
50 Pages
 Rotary encoder TRN58/C3
22 Pages
 Rotary encoder TRN42/S4 SIL2
22 Pages
 Manual TRN50/C3
86 Pages
 Rotary encoder TRN50/C3
22 Pages
 Rotary encoder TRN42/C3 manual
86 Pages
 Rotary encoder TRN42/C3
22 Pages
 Rotary encoder TBN42/S4 SIL2
22 Pages
 Rotary encoder TBN42/C3
22 Pages
 Rotary encoder TRE58
16 Pages
 Rotary encoder TRT manual
40 Pages
 Rotary encoder TRT
14 Pages
 Switching cam encoder NOCE
14 Pages
 Switching cam encoder NOCA
17 Pages
 Vibration sensor NVT/S3 PLd
12 Pages
 Vibration sensor NVA
12 Pages
 Inclinometer NBN
17 Pages
 Incremental encoder TBI42
6 Pages
 Vibration sensor NVA/S3 PLd
15 Pages
 Rotary transducer PMR411
1 Page
 Rotary encoder TRT/S3 SIL2
13 Pages
 Rotary transducer VP12
1 Page
 Switching cam encoder NOCN
22 Pages
 Inclination sensor NBT manual
21 Pages
 Inclination sensor NBT
10 Pages
 Inclinometer NBA
17 Pages
 Inclinometer NBT/S3 SIL2/PLd
12 Pages
 Inclinometer NBN/S3 SIL2
13 Pages
 Rotary encoder TBE50
16 Pages
 Rotary encoder HBE
14 Pages
 Rotary encoder TRK manual
18 Pages
 Rotary encoder TRK
11 Pages
 Rotary encoder TMN50 manual
22 Pages
 Rotary encoder TMN50
6 Pages
 Rotary encoder TRK/S3 SIL2
14 Pages
 Rotary encoder TRE42
6 Pages
 Rotary encoder TRE50
6 Pages
 Rotary encoder TRA50
6 Pages
 Rotary encoder TBE42
6 Pages
 Rotary encoder TME42
6 Pages
 Rotary encoder TRD manual
26 Pages
 Rotary encoder TRD
12 Pages
 Rotary encoder TME50
6 Pages
 Rotary encoder TBN36
6 Pages
 Rotary encoder TMA50
6 Pages
 Rotary encoder TMN42 manual
22 Pages
 Rotary encoder TMN42
6 Pages
 Rotary encoder TMA42
6 Pages
 Rotary encoder TBA50
16 Pages
 Rotary encoder TBE36 manual
22 Pages
 Rotary encoder TBE36
6 Pages
 Rotary encoder TBN42
6 Pages
 Rotary encoder TBN37
8 Pages
 Rotary encoder TBA37
7 Pages
 Rotary encoder TBB50
16 Pages
 Rotary encoder PBA12
2 Pages
 Rotary encoder TBA36
6 Pages
 Rotary encoder TKA60
2 Pages
 Rotary encoder TKN46 manual
22 Pages
 Rotary encoder TKN46
7 Pages




- Incremental encoder
- Incremental rotary encoder
- Tilt sensor
- Industrial rotary encoder
- Magnetic rotary encoder
- Displacement transducer
- Linear displacement sensor
- Aluminum rotary encoder
- Digital inclination sensor
- Stainless steel rotary encoder
- Single-turn rotary encoder
- Flange rotary encoder
- MEMS inclination sensor
- Ultra-rugged rotary encoder
- SSI angular encoder
- Multi-turn rotary encoder
- Multi-axis tilt sensor
- Analog displacement transducer