
- Catalogs
- Suzhou Honpine Precision Industry Co., Ltd.
- Robot RV Cycloid Gear Reducer

- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
Robot RV Cycloid Gear Reducer
Robot RV Cycloid Gear Reducer
- Allowable Torques: Defines various allowable torques such as acceleration/deceleration torque and momentary maximum allowable torque. It stresses the importance of not exceeding these values to prevent damage.
- Speed Specifications: Details allowable input and output speeds, noting potential temperature rise even within these limits. Advises maintaining surface temperatures at or below 60℃.
- Torsional Characteristics: Explains torsional rigidity, lost motion, and backlash with hysteresis curves, crucial for understanding mechanical behavior under load.
- Startup Efficiency and No-load Running Torque: Provides definitions and considerations for startup efficiency and no-load operation torque.
- Environmental and Operational Conditions: Specifies ambient temperature, humidity, altitude, and ventilation requirements, including a flowchart for product selection based on these conditions.
- Product Selection Process: Offers a step-by-step guide for selecting the appropriate reduction gear model, including verifying operating environments and calculating load torques.
- Model Code Selection Examples: Provides examples for selecting reduction gear models based on specific operational parameters and conditions.
- Tentative Selection of Reduction Gear Model: Begins with selecting a model based on desired specifications and application requirements.
- Verification of Maximum Torque: Ensures allowable acceleration/deceleration torque is sufficient compared to starting and stopping torques.
- Verification of Output Speed: Confirms allowable output speed exceeds average speed per cycle.
- Verification of Shock Torque During Emergency Stops: Evaluates emergency stop conditions to ensure shock torque is within limits.
- Verification of Thrust and Moment Load: Ensures thrust and moment loads fall within allowable limits.
- Verification of Service Life: Confirms required service life is less than or equal to calculated service life.
- Limitation on Motor Torque: Ensures momentary maximum allowable torque is greater than maximum torque generated at the output shaft.
- No-load Running Torque: Provides graphs and formulas for calculating no-load running torque.
- Efficiency and Moment Rigidity: Includes efficiency tables and moment rigidity data for performance evaluation.
- Installation Precision: Emphasizes proper assembly precision to prevent issues like vibration and noise.
Catalog excerpts

CT-CRV SERIES RV Cycloid Gear Reducer Suzhou Honpine Precision Industry Co., Ltd.
Open the catalog to page 1
Ⅰ . Technical Advantages 1. With its unique tooth design and modification technology, Chietom is able to produce the parts with optimized load distribution,strong anti-abrasion ability and self-adaptability to manufacturing error.The products also show the superior quality in stable transmission and low noise. 2. Chietom's factories are equipped with customized world-class CNC manufacturing equipments,which ensure high precision efficiency and stability of mass products. 3. With company's self-designed manufacturing technology and clamping device,the final products are manufactured with high...
Open the catalog to page 3
Ⅱ . Applications The Main Purpose ROBOT 4,6-axis joint robot (series robot) parallel robot SCARA robot circular dividing table truss robot moveable slider semiconductor robot (stacker, LCD robot) MACHINE TOOL OTHERS medical equipment (CT machine) pipe bending machine, bending machine semiconductor equipment human exoskeleton Angle deflection of wind and solar equipment tool library printing machine
Open the catalog to page 4
(l)Structure Case Planetary carrier Spur gear Input shaft Cycloidal gear Crankshaft Main bearing ☆ High shock load capability ☆ Excellent acceleration/ deceleration performance ☆ Large speed ratio ☆ Long service life 1.2 Structure and Features of CT-CRV-C series(1)Structure Case Planetary carrier Cycloidal gear Crankshaft Spur gear Center gear Main bearing ☆ High shock load capability ☆ Excellent acceleration/ deceleration performance ☆ Large speed ratio ☆ Long service life ☆ The hollow part can wear cable to save space 1.3 Principle of CT-CRV Speed Reduction Cycloidal gear Planet carrier Crankshaft...
Open the catalog to page 5
1. CT-CRV-E Explanation of Codes Output shaft tightening code B: Output shaft bolt tightening Input gear structure code A: Standard thin shaft type B: Standard thick shaft type Z: Nothing Speed ratio code Series code Specification code Type code Exploded view of CT-CRV-E reducer
Open the catalog to page 6
Remarks: (1)The rated torque is the output torque of the output speed of 15r/min, which is the basis for calculating the service life. (2)The maximum speed of the input shaft must not be greater than the allowable maximum output speed multiplied by the speed ratio. If you need a speed ratio other than the above speed ratio, please consult our company.
Open the catalog to page 7
Maximum Allowable Momentary Momentary Allowable Torsional Maximum Angle Allowable Allowable Acceleraton/ Maximum Maximum Moment Bending Rigidity Lost Backlash Transfer Radial Output Deceleration Allowable Allowable of Inertia Moment N.m/ Motion arcmin Error Load Speed Torque Torque Bending Kgm2 N.m arcmin arcmin arcsec N r/min N.m N.m Moment N.m Rated Weight life Kg h Remarks: The inertia moment is the value of the reducer unit, and the inertia moment of the center gear and input gear is not considered. Therefore, refer to the following formula for
Open the catalog to page 8
INTERNAL CIRCLIPS DEEP GROOVE BALL BEARING EXTERNAL CIRCLIPS output shaft shaft type type CRV20E Bolt Bolttightening cIamping output speed ratio 3. CT-CRV-E External Dimensions
Open the catalog to page 9
tighteningoutput outputshaft shafttype type CRV20E Bolt Bolt cIamping speed ratio
Open the catalog to page 10
INTERNAL CIRCLIPS EXTERNAL CIRCLIPS DEEP GROOVE BALL BEARING CRV40E Bolt Bolt tightening cIamping output outputshaft shafttype type Type code: CRV40E
Open the catalog to page 11
Bolt tighteningoutput shaft type
Open the catalog to page 12
INTERNAL CIRCLIPS EXTERNAL CIRCLIPS DEEP GROOVE BALL BEARING CRV80E Bolt Bolt tightening cIamping output outputshaft shafttype type Type code: CRV80E
Open the catalog to page 13
CRV80E Bolt Bolttightening cIamping output output shaft type shaft type Type code: CRV80E
Open the catalog to page 14
CRV110E Bolt Bolt cIamping tighteningoutput outputshaft shafttype type Type code: CRV110E
Open the catalog to page 15
outputshaft shafttype type CRV160E Bolt Bolt tightening cIamping output
Open the catalog to page 16
CRV320E Bolt Bolttightening cIamping output output shaft shaft type type Type code: CRV320E
Open the catalog to page 17
CRV320E3 Bolt Bolttightening cIamping output output shaft shaft type type Type code: CRV320E3
Open the catalog to page 18
CRV450E Bolt BoltcIamping tighteningoutput outputshaft shafttype type Type code: CRV450E
Open the catalog to page 19
Ⅴ . CT-CRV-C series 1. CT-CRV-C Explanation of Codes Output shaft tightening code B: Output shaft bolt tightening T: Output shaft through hole bolt tightening Center gear structure code A: Standard size products Z: Nothing Speed ratio code Series code Specification code Type code Exploded view of CT-CRV-C reducer
Open the catalog to page 20
(1) The rated torque is the output torque of the output speed of 15r/min, which is the basis for calculating the service life. (2) The maximum speed of the input shaft must not be greater than the allowable maximum output speed multiplied by the speed ratio. If you need a speed ratio other than the above speed ratio, please consult our company. (3) The inertia moment is the value of the reducer unit, and the inertia moment of the center gear and input gear is not considered. Therefore, refer to the following formula for the moment of inertia of the motor shaft. +Inertia moment of input gear Moment...
Open the catalog to page 22
CRV10C Bolt Bolttightening cIamping output output shaft shaft type type Type code: CRV10C
Open the catalog to page 23
CRV27C Bolt Bolttightening cIamping output output shaft shaft type type Type code: CRV27C
Open the catalog to page 24
CRV50C Bolt Bolt tightening cIamping output outputshaft shaft type type Type code: CRV50C
Open the catalog to page 25
CRV100C Bolt Bolttightening cIamping output output shaft shaft type type Type code: CRV100C
Open the catalog to page 26
CRV120C Bolt Through-bolt output tighteningcIamping output shaft typeshaft type Type code: CRV120C
Open the catalog to page 27
CRV200C Bolt Bolttightening cIamping output type output shaft shaft type Type code: CRV200C
Open the catalog to page 28
CRV320CA Bolt Bolttightening cIamping output type output shaft shaft type Type code: CRV320CA
Open the catalog to page 30
CRV500C Bolt Bolttightening cIamping output output shaft shaft type type Type code: CRV500C
Open the catalog to page 31
Rating service life The lifetime resulting from the operation with the rated torque and the rated output speed is referred to as the "rated service life". ● Allowable acceleration/deceleration torque When the machine starts or stops, the load torque to be applied to the reduction gear is larger than the constantspeed load torque due to the effect of the inertia torque of the rotating part. In such a situation, the allowable torque during acceleration/deceleration is referred to as "allowable acceleration/deceleration torque". Note: Be careful that the load torque, which is applied at startup...
Open the catalog to page 32All Suzhou Honpine Precision Industry Co., Ltd. catalogs and technical brochures
 mini harmonic drive reducer
27 Pages
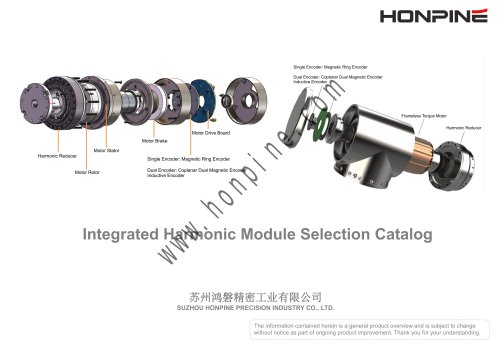 Harmonic Rotary Module
14 Pages
 Dexterous Robot Hand
8 Pages
 HONPINE Precision Motion Control
17 Pages
 Integrated Robot Servo Wheel
7 Pages
 RV Reducer Gearbox
15 Pages
 High Precision Planetary Gearbox
48 Pages
 Planetary Robot Joint Actuator
14 Pages
 Harmonic AC Servo Motor
33 Pages
 HONPINE harmonic drive catelog
109 Pages
- Electromotor
- Synchronous motor
- Actuator
- Industrial robot
- Electric gearmotor
- Linear actuator
- Planetary gearbox
- Electric actuator
- Coaxial gearhead
- Mechanical protection protection gloves
- EC motor
- Electromotor for industrial applications
- Precision gearhead
- Articulated robot
- 24 V motor
- Right angle gearhead
- Compact gearhead
- Servo-motor
- Direct current gear-motor
- Solid-shaft gearhead