
- Catalogs
- Suzhou Honpine Precision Industry Co., Ltd.
- Harmonic Rotary Module

- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
Harmonic Rotary Module
Harmonic Rotary Module
Catalog excerpts

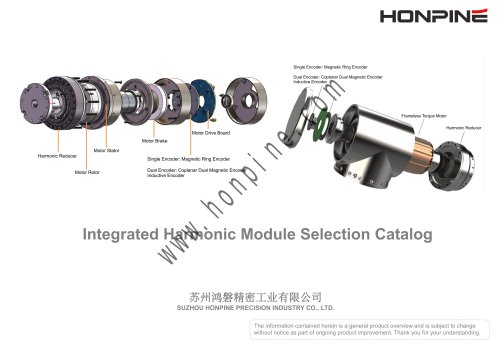
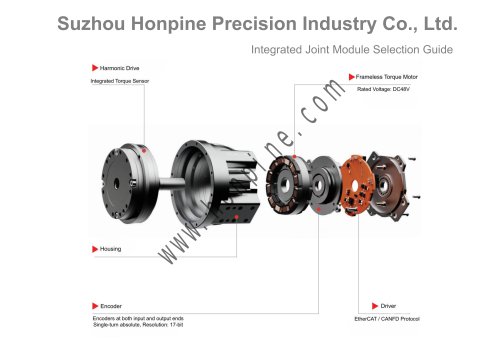
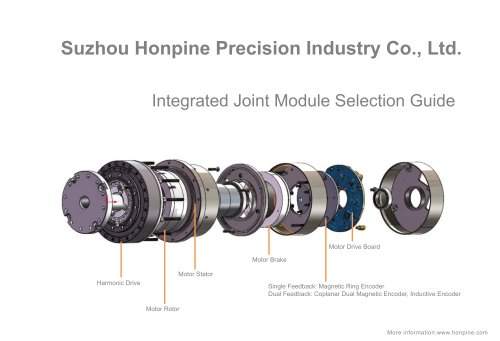
Motor Drive Board Motor Brake Motor Stator Single Encoder: Magnetic Ring Encoder HONRIN Dual Encoder: Coplanar Dual Magnetic Encoder Inductive Encoder Frameless Torque Motor Harmonic Reducer Harmonic Reducer Single Encoder: Magnetic Ring Encoder Motor Rotor Dual Encoder: Coplanar Dual Magnetic Enco Inductive Encoder i The information contained herein is a general product overview and is subject to change i without notice as part of ongoing product improvement. Thank you for your understanding.
Open the catalog to page 1
HIS& HTS Series Harmonic Joint Motor Take HIS/HTS-Outer Diameter-Speed Ratio-B(brake)-C/E (EtherCAT/CANopen) communication protocol as an example. B(brake) and C/E (EtherCAT/CANopen) communication are optional features. C: CANopen protocol, E: EtherCAT protocol B: Brake (power-off locking) Precautions: ①Operation under overvoltage or overload conditions is strictly prohibited. ②Unauthorized disassembly of the motor is forbidden. ③Ensure the motor is installed within the valid thread depth. ④During high-speed operation, blocked rotation or emergency braking is prohibited. ⑤Hot-plugging (connecting/disconnecting...
Open the catalog to page 2
Starting Peak Torque(N·m) Allowable Maximum Average Load Torque (N·m) Instantaneous Allowable Maximum Torque (N·m) Motor Rated Torque(at motor end N·m) Motor Maximum Torque(at motor end N·m) Maximum Speed(RPM) Rated Speed(RPM) Maximum Current(Arms) Rated Current(Arms) Module Parameters Reduction Ratio Ethercat Interface Definition Drive Parameters Brake Parameters Motor Parameters Communication Type Operating Ambient Temperature(°C) Relative Humidity Encoder Battery Supply Voltage (VDC) Encoder Battery Supply Current(Arms) Engagement Time(ms) Release Time(ms) Rated Voltage(VDC) Rated Torque(N·m)...
Open the catalog to page 3
Ethercat Interface Definition
Open the catalog to page 4
Ethercat Interface Definition
Open the catalog to page 5
Reduction Ratio Starting Peak Torque(N·m) Allowable Maximum Average Load Torque (N·m) Instantaneous Allowable Maximum Torque (N·m) Motor Rated Torque(at motor end N·m) Motor Maximum Torque(at motor end N·m) Maximum Speed(RPM) Rated Speed(RPM) Maximum Current(Arms) Rated Current(Arms) Drive Parameters Module Parameters Ethercat Interface Definition Brake Parameters Motor Parameters Communication Type Operating Ambient Temperature(°C) Relative Humidity Encoder Battery Supply Voltage (VDC) Encoder Battery Supply Current(Arms) Engagement Time(ms) Release Time(ms) Rated Voltage(VDC) Rated Torque(N·m)...
Open the catalog to page 6
Reduction Ratio Starting Peak Torque(N·m) Allowable Maximum Average Load Torque (N·m) Instantaneous Allowable Maximum Torque (N·m) Motor Rated Torque(at motor end N·m) Motor Maximum Torque(at motor end N·m) Maximum Speed(RPM) Rated Speed(RPM) Maximum Current(Arms) Rated Current(Arms) Drive Parameters Module Parameters Ethercat Interface Definition Brake Parameters Motor Parameters Communication Type Operating Ambient Temperature(°C) Relative Humidity Encoder Battery Supply Voltage (VDC) Encoder Battery Supply Current(Arms) Engagement Time(ms) Release Time(ms) Rated Voltage(VDC) Rated Torque(N·m)...
Open the catalog to page 7
Reduction Ratio Starting Peak Torque(N·m) Allowable Maximum Average Load Torque (N·m) Instantaneous Allowable Maximum Torque (N·m) Motor Rated Torque(at motor end N·m) Module Parameters Motor Maximum Torque(at motor end N·m) 14.65 Ethercat Interface Definition Drive Parameters Brake Parameters Motor Parameters Maximum Speed(RPM) Rated Speed(RPM) Maximum Current(Arms) Rated Current(Arms) Communication Type Operating Ambient Temperature(°C) Relative Humidity Encoder Battery Supply Voltage (VDC) Encoder Battery Supply Current(Arms) Engagement Time(ms) Release Time(ms) Rated Voltage(VDC) Rated Torque(N·m)...
Open the catalog to page 8
Reduction Ratio Starting Peak Torque(N·m) Allowable Maximum Average Load Torque (N·m) Instantaneous Allowable Maximum Torque (N·m) Motor Rated Torque(at motor end N·m) Motor Maximum Torque(at motor end N·m) Maximum Speed(RPM) Rated Speed(RPM) Maximum Current(Arms) Rated Current(Arms) Drive Parameters Module Parameters Brake Parameters Motor Parameters Communication Type Operating Ambient Temperature(°C) Relative Humidity Encoder Battery Supply Voltage (VDC) Encoder Battery Supply Current(Arms) Engagement Time(ms) Release Time(ms) Rated Voltage(VDC) Rated Torque(N·m) Rated Speed(RPM) Rated Current(Arms)...
Open the catalog to page 11All Suzhou Honpine Precision Industry Co., Ltd. catalogs and technical brochures
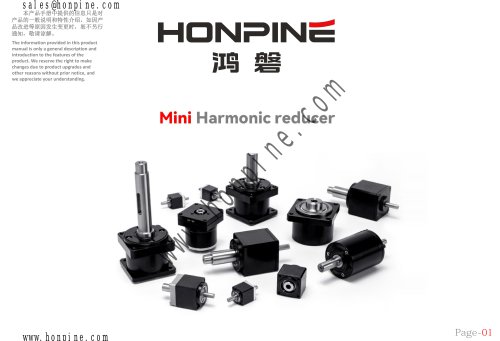 mini harmonic drive reducer
27 Pages
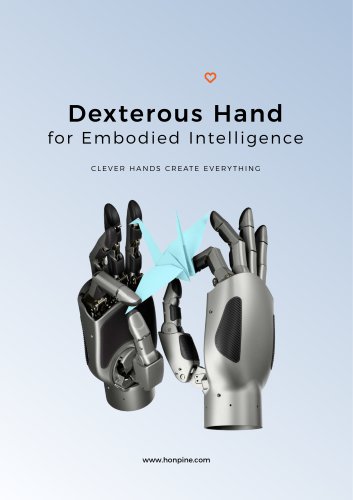 Dexterous Robot Hand
8 Pages
 HONPINE Precision Motion Control
17 Pages
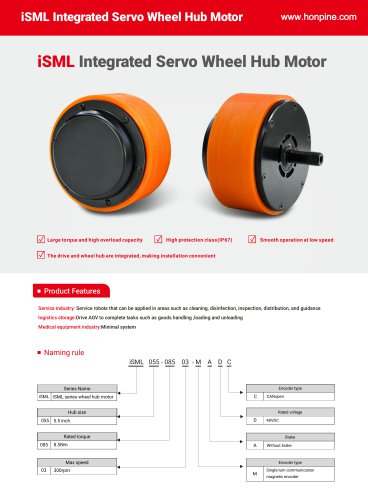
 Integrated Robot Servo Wheel
7 Pages
 RV Reducer Gearbox
15 Pages
 High Precision Planetary Gearbox
48 Pages
 Robot RV Cycloid Gear Reducer
58 Pages
 Planetary Robot Joint Actuator
14 Pages
 Harmonic AC Servo Motor
33 Pages
 HONPINE harmonic drive catelog
109 Pages
- Electromotor
- Synchronous motor
- Actuator
- Industrial robot
- Electric gearmotor
- Linear actuator
- Planetary gearbox
- Electric actuator
- Coaxial gearhead
- Mechanical protection protection gloves
- Electromotor for industrial applications
- EC motor
- Precision gearhead
- 24 V motor
- Articulated robot
- Servo-motor
- Right angle gearhead
- Compact gearhead
- Direct current gear-motor
- 6-axis robot