
- Catalogs
- Shenzhen Ruicom Technology Co., Ltd.
- RUICOM GHA360 Ethernet high-frequency Vibration sensor

- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
RUICOM GHA360 Ethernet high-frequency Vibration sensor
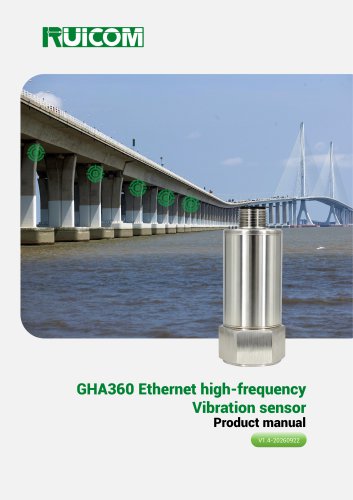
RUICOM GHA360 Ethernet high-frequency Vibration sensor
The GHA360 is a three-axis Ethernet high-frequency vibration sensor designed for industrial applications. It features synchronous acquisition of X/Y/Z transient acceleration with a maximum response frequency of 10 kHz per axis. The sensor includes a 20-bit high-resolution analog-to-digital converter with a sensitivity of 0.095 mg/LSB, ensuring accurate waveform restoration even in noisy environments. It supports direct data transmission to servers via a 10/100Mbps Ethernet interface, making it ideal for monitoring the health of rotating machinery such as motors and gearboxes.
Application Field
The sensor is used for vibration monitoring in industrial equipment, including pumps, motors, fans, air compressors, and generators.
Technical Characteristics
- Measuring range: ±50g
- Power supply: 12V
- Operating temperature: -10℃ to +70℃
- IP67 protection rating
- Bandwidth: DC~10kHz
- Low noise: 35µg/√Hz
Specifications
- Measurement Range: ±50g
- Sensitivity: 0.095 mg/LSB
- Measuring Axis: X / Y / Z Axis
- Response Frequency: DC~10 kHz
- Sampling Frequency: 80kHz
- Communication Interface: Ethernet
- Default Server Address/Port: 192.168.1.169/22009
- Operating Ambient Temp: -40℃ ~ +85℃
- Installation Method: Magnetic or screw mounting
- Protection Rating: IP67
- Dimensions: Ø23.6×H60.6mm
- Weight: ≤105g
Product List
- GHA360 Vibration Sensor
- Network cable power supply combiner
- 8-core M12 aviation plug to crystal head cable
- Power adapter 12V1A
- Magnetic seat and stainless steel M5 screw
- Conversion screw options
Installation Method
The sensor can be installed using a magnetic attachment or a screw mount. Silicone grease is recommended for secure attachment.
Communication Protocol
The sensor uses the TCP protocol for communication, acting as a client to a TCP server. It continuously sends triaxial acceleration data packets to the server, which are then used to generate real-time acceleration signals.
Data Packet Structure
Each data packet contains 116 sets of vibration data for the x, y, and z axes. The packet structure includes fields for packet type, sensor ID, sampling frequency, and acceleration data.
Contact Information
For more information, visit www.ruicomtech.com or contact [email protected].
Catalog excerpts
GHA360 Ethernet high-frequency Vibration sensor Product manual V1.4-20260922
Open the catalog to page 1
Product Introduction- GHA360 three-axis Ethernet high-frequency vibration sensor, integrated with X/Y/Z three-way transient acceleration synchronous acquisition capability, with a maximum single axis response frequency of 10 kHz, fully covering the fault characteristic frequency bands of mainstream industrial rotating machinery such as gear meshing frequency, bearing characteristic frequency, and blade passing frequency. Built in 20 bit high-resolution analog-to-digital conversion architecture, with fine sensitivity up to 0.095 mg/LSB, combining excellent linearity and the ability to pick up...
Open the catalog to page 2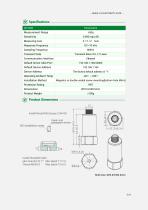
Measurement Range Measuring Axis Response Frequency Sampling Frequency Transient Data Transient data of X, Y, Z axes Communication Interface Default Server Add./Port Default Device Address Device Address The factory default address is "1" Operating Ambient Temp Installation Method -40℃ ~ +85℃ Magnetic or double-ended screw mounting(bottom hole M5*6) Protection Rating Dimensions Product Weight Product Dimensions
Open the catalog to page 3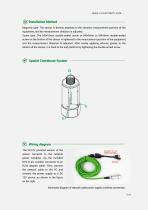
Installation Method Magnetic type: The sensor is directly attached to the vibration measurement position of the equipment, and the measurement direction is adjusted. Screw type: The M5×10mm double-ended screw or M5×6mm to M8*8mm double-ended screw on the bottom of the sensor is tightened to the measurement position of the equipment, and the measurement direction is adjusted. After evenly applying silicone grease to the bottom of the sensor, it is fixed to the test platform by tightening the double-ended screw. Spatial Coordinate System Wiring diagram The DC12V powered version of the sensor connects...
Open the catalog to page 5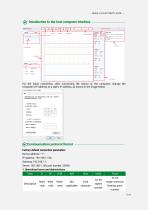
Introduction to the host computer interface For the initial connection, after connecting the sensor to the computer, change the computer's IP address to a static IP address, as shown in the image below. Communication protocol format Factory default connection parameters Device address: "1"; IP address: 192.168.1.164; Gateway: 192.168.1.1; Server: 192.168.1.169, port number: 22009. 1. Specialized terms and abbreviations Term Float 32-bit single-precision floating-point number 6/8
Open the catalog to page 6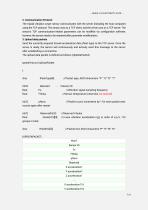
The triaxial vibration smart sensor communicates with the server (including the host computer) using the TCP protocol. The sensor acts as a TCP client, and the server acts as a TCP server. The sensor's TCP communication-related parameters can be modified via configuration software; however, the sensor needs to be restarted after parameter modifications. Send the currently acquired triaxial acceleration data (float type) to the TCP server. Once the server is ready, the sensor will continuously and actively send this message to the server after establishing a connection. The upload data packet...
Open the catalog to page 7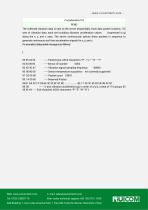
- w w w. r u i c o m t e c h . c o m Z acceleration116 PEND The collected vibration data is sent to the server sequentially. Each data packet contains 116 sets of vibration data, each set including vibration acceleration values along the x, y, and z axes. The server continuously splices these packets in sequence to generate continuous real-time acceleration signals for x, y, and z. Forexample(a datapacketmessageisas follows): { 50 55 44 54 ----Packet type, ASCII characters “P” “ U ” “ D ” “T” ----Vibration signal sampling frequency ----Sensor temperature acquisition not currently supported E-mail:...
Open the catalog to page 8All Shenzhen Ruicom Technology Co., Ltd. catalogs and technical brochures
- Tilt sensor
- Digital inclination sensor
- 2-axis tilt sensor
- MEMS inclination sensor
- Multi-axis tilt sensor
- High-precision tiltmeter
- Analog inclination sensor
- IP67 inclination sensor
- 1-axis tilt sensor
- Rugged inclination sensor
- Waterproof tiltmeter
- Angle measurement inclination sensor
- High-resolution inclinometer
- Tilt switch
- Inclination sensor with aluminum housing
- RS-485 inclinometer
- RS-232 inclinometer
- Anti-vibration inclinometer
- CAN inclination sensor