
- Catalogs
- Shenzhen Ruicom Technology Co., Ltd.
- RUICOM BDS450 Bluetooth Dynamic Attitude Sensor

- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
RUICOM BDS450 Bluetooth Dynamic Attitude Sensor
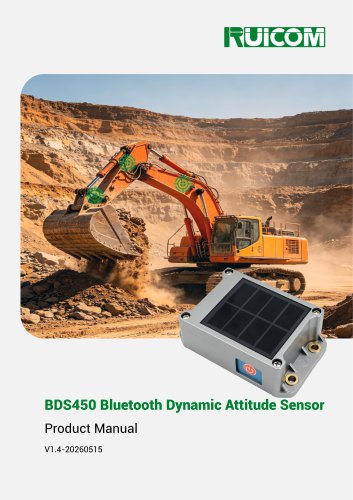
RUICOM BDS450 Bluetooth Dynamic Attitude Sensor
The BDS450 Bluetooth Dynamic Attitude Sensor integrates a nine-axis sensor and temperature sensor, utilizing Bluetooth 5.1 for wireless transmission. It offers real-time 3D dynamic measurement with an update rate of up to 100Hz, employing a Kalman filtering algorithm. The device is solar-powered, enhancing its usability in various environments.
The BDS450 is designed for high dynamic balance applications such as model aircraft, robots, and construction vehicles. It combines a three-axis accelerometer, gyroscope, and temperature compensation algorithm to provide accurate real-time attitude data. The sensor supports Bluetooth 5.1 with a transmission range of up to 40 meters and allows for BLE DFU Bluetooth wireless firmware upgrades.
This sensor is suitable for cranes, construction machinery, agricultural machinery, mobile elevators, fire trucks, AGVs, automated assembly machinery, and drilling applications.
The sensor measures roll, pitch, and azimuth with static and dynamic accuracy at 25°C. It features a gyroscope range of ±300°/s and an acceleration range of ±8g. The device is compliant with EN61000 and GBT17626 standards, with a waterproof rating of IP67.
The BDS450 is housed in a PPS plastic casing with optional stainless steel protective covers. It supports various installation orientations and application types, including marine and construction applications.
The solar panel measures 50x55x2.4mm, operating within -20 to +70°C. The battery has a nominal capacity of 1400mAh and a voltage of 3.65V, with a usage time of approximately 20 days under specified conditions.
The device features a power indicator light and operates in low-power Bluetooth broadcast mode, awaiting host connection. It transmits tilt indicator data upon successful connection.
Proper installation is crucial to avoid measurement errors. The sensor must be mounted on a stable, flat surface, with its axis parallel to the measured object's axis.
Regular cleaning is essential, especially in dusty environments. Avoid using abrasive materials or corrosive solvents. Inspect installation structures for damage and ensure proper electrical performance maintenance.
The device supports data streaming and local cache display through a WeChat mini program, allowing real-time monitoring and data acquisition.
The document outlines the Bluetooth Low Energy (BLE) protocol used for communication between a host and a slave device, specifically the BDS450H. It details the protocol's application in data acquisition, transmission, and remote control, emphasizing its dual modes of local and remote data access.
The protocol is based on the General Attribute Protocol (GATT) model, where the slave device acts as the GATT server and the master device (mobile app or PC) acts as the GATT client. Key components include services, characteristics, and descriptors, which define device functions, specific data points, and additional information configuration, respectively.
The document describes the roles of the host (central) and slave (peripheral) in initiating connections and data exchanges. It supports bidirectional communication, with scenarios for periodic data broadcasting and host-initiated communication requests.
The slave device provides specific GATT services and characteristics, with UUIDs defining each service and characteristic. The document details the data frame format, including identifiers, data length, address codes, command words, and checksums.
Various command words are explained, such as querying default data items, sensor responses, setting installation measurement directions, and software reset commands. Each command includes examples and explanations of data fields and expected responses.
The document lists data output items such as attitude angles, triaxial acceleration, angular velocity, temperature, battery capacity, tilt state, and IMU local time. Each item is described with its storage format and conversion to meaningful values.
The document provides detailed examples of data analysis in query or automatic data output modes, explaining the meaning of each byte in the data frame and how to interpret the output data.
- Frame Header: Indicates the start of a data frame with a command byte of 0x68.
- Data Length: Specifies the length of the data field, which is 23 bytes in this example.
- Data Type: The byte 0x83 indicates the type of data output, which includes Euler angles, accelerometer, and gyro angular velocities.
- Data Parsing: The document provides a detailed breakdown of byte offsets and their corresponding data types, such as Roll, Pitch, Yaw, Acceleration (X, Y, Z), and Gyro (X, Y, Z).
- Euler Angles: Parsed using the
BDS_Angle_UnPackfunction, which converts raw data to angles in degrees. - Acceleration: Parsed using the
BDS_Accel_UnPackfunction, converting raw data to acceleration in g. - Gyro Velocities: Parsed using the
BDS_Gyro_UnPackfunction, converting raw data to angular velocity in degrees per second.
- The
USART_68_Command_Checkfunction verifies command integrity and processes data based on the command type. - Specific command (0x84) processing includes incrementing a counter and validating data length.
For further inquiries, contact Ruicom Technology via email at [email protected] or phone at +86 183 0761 1639.
Catalog excerpts
BDS450 Bluetooth Dynamic Attitude Sensor Product Manual V1.4-20260515
Open the catalog to page 1
❖ Integrated nine-axis sensor and temperature sensor; ❖ Bluetooth 5.1 wireless transmission; ❖ Real-time 3D dynamic measurement; ❖ Kalman filtering algorithm; Security Time-saving Product Introduction - The BDS450 is a Bluetooth-enabled dynamic attitude sensor offering excellent performance at a competitive price. It is widely applicable to equipment requiring high dynamic balance, such as model aircraft, robots, agricultural machinery, construction vehicles, and forklifts. By integrating a three-axis accelerometer, a three-axis gyroscope, and a temperature compensation algorithm, combined with...
Open the catalog to page 3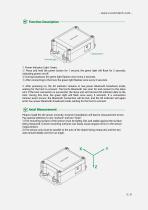
Function Description 1. Power Indicator Light: Green; ① Press and hold the power button for 1 second, the green light will flash for 2 seconds, indicating power on/off. ② During broadcast, the green light flashes once every 2 seconds. ③ After connecting to the host, the green light flashes once every 5 seconds. 2. After powering on, the tilt indicator remains in low-power Bluetooth broadcast mode, waiting for the host to connect. The host's Bluetooth can scan for and connect to the slave unit. If the host connection is successful, the slave unit will transmit tilt indicator data to the host....
Open the catalog to page 6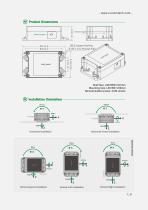
Product Dimensions Shell Size: L96×W59×H31mm Mounting Size: L83×W31×H6mm Recommended screws: 4 M5 screws Installation Orientation
Open the catalog to page 7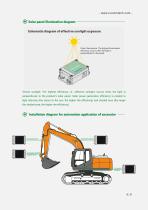
Solar panel illumination diagram *Direct sunlight: The highest efficiency, i.e., effective sunlight, occurs when the light is perpendicular to the product's solar panel. Solar power generation efficiency is related to light intensity (the closer to the sun, the higher the efficiency) and shaded area (the larger the shaded area, the higher the efficiency). Installation diagram for automation application of excavator
Open the catalog to page 8
1. Regular cleaning cycle • Outdoor open-air environments / mining areas / construction sites / dusty environments: Clean once every 7-15 days. • After rain, snow, sandstorms, or dense fog, complete cleaning within 24 hours. 2. Standard cleaning procedures • Pre-dust removal: First, use a dry, soft-bristled brush and a lint-free non-woven cloth to gently sweep away surface dust and sand. Do not dry-wipe with particulate matter to avoid scratching the ETFE/PET translucent layer. • Rinse and dry: Rinse off any foam with clean water. Use a lint-free, dry cloth to absorb excess water along the grain,...
Open the catalog to page 9
• Output Testing Cycle: Test the output voltage and current quarterly in a sunny, unobstructed environment at midday. Standard values are 4V and 120mA. If a significant drop occurs, first clean the board surface, then check the internal wiring and waterproof terminals. • Waterproof and Moisture-proof Maintenance: If whitening or water seepage appears at the sealing edges of the board surface, promptly reseal with neutral silicone weather-resistant sealant. Prolonged infiltration of rainwater or dew will corrode the IBC cell grid lines, causing power degradation. • Temperature Control: Avoid prolonged...
Open the catalog to page 10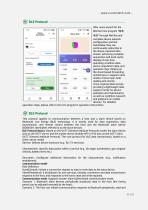
BLE Protocol After users search for the WeChat mini program "瑞惯 传感" through WeChat and complete device network configuration and link handshake, they can continuously subscribe to the device-reported data stream, achieving complete acquisition and local cache display of real-time operating condition data, sensor acquisition data, and operation logs. Relying on the cloud-based forwarding architecture, it supports dual modes of local near-field reading and remote cross-regional data access, providing a lightweight data support carrier for device operation and maintenance, as well as condition research...
Open the catalog to page 11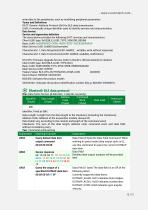
- www.ruicomtech.com -write data to the peripherals, such as modifying peripheral parameters. GATT Generic Attribute Protocol (GA) for BLE data transmission. UUID: A universally unique identifier used to identify services and characteristics. Data format Service and eigenvalue definition The slave device provides the following GATT services and characteristics: Client UUID type: 0x02(BLE_UUID_TYPE_VENDOR_BEGIN) Basic UUID: 0x00000000-C85B-40BD-9D2F-A0C826B04A69 Main Service UUID: 0x6801(Inclinometer) Characteristic 1: Data Reception(UUID: 0x6802, writable, write without response) Characteristic...
Open the catalog to page 12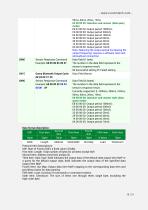
00 00 00 00: Question-and-answer (data query mode) Note: Reducing the output period (increasing the output frequency) requires a software reset and rebroadcast connection. 0X8C Sensor Response Command Data Field (1 byte) Example: 68 05 00 8C 00 91 The number in the data field represents the sensor's response result. 00 Successful setting FF Failed setting 0X1C Query Bluetooth Output Cycle Data Field (None) 0X9C Sensor Response Command Data Field (4 bytes) Example: 68 08 00 9C E8 03 The number in the data field represents the 00 00 8F sensor's response result. 00 00 00 00: Question-and-answer...
Open the catalog to page 15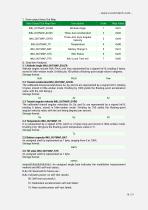
1. Data output items Out Map 2. Data Item Analysis 2.1 Attitude Angle IMU_OUTMAP_EULER Attitude angles include Roll, Pitch, and Yaw, represented by a signed int16, totaling 6 bytes, stored in little-endian mode. Dividing by 100 yields a floating-point angle value in degrees. Storage format: The calibrated triaxial accelerations Ax, Ay, and Az are represented by a signed int16, totaling 6 bytes, stored in little-endian mode. Dividing by 1000 yields the floating-point acceleration value, with the unit being g. Storage format: 2.3 Triaxial angular velocity IMU_OUTMAP_GYRO The calibrated triaxial...
Open the catalog to page 16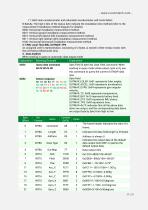
11: Both main accelerometer and redundant accelerometer self-tests failed; B7B6B5B4: The high 4 bits of the status byte indicate the installation test method (refer to the measurement installation method diagram for details): 0000: Horizontal installation measurement method. 0001: Vertical upward installation measurement method. 0010: Vertical left (lateral left) installation measurement method. 0011: Vertical right (lateral right) installation measurement method. 0100: Horizontal downward installation measurement method. An unsigned uint16 representation, consisting of 2 bytes, is stored in...
Open the catalog to page 17All Shenzhen Ruicom Technology Co., Ltd. catalogs and technical brochures
- Digital inclination sensor
- 2-axis tilt sensor
- MEMS inclination sensor
- Multi-axis tilt sensor
- IP67 inclination sensor
- High-precision tiltmeter
- Analog inclination sensor
- 1-axis tilt sensor
- Vibration sensor
- Rugged inclination sensor
- Angle measurement inclination sensor
- High-resolution inclinometer
- Tilt switch
- Waterproof tiltmeter
- Inclination sensor with aluminum housing
- RS-485 inclinometer
- Anti-vibration inclinometer
- RS-232 inclinometer
- CAN inclination sensor