
- Catalogs
- Shenzhen Ruicom Technology Co., Ltd.
- GHA360 Ethernet high-frequency Vibration sensor
GHA360 Ethernet high-frequency Vibration sensor
GHA360 Ethernet high-frequency Vibration sensor
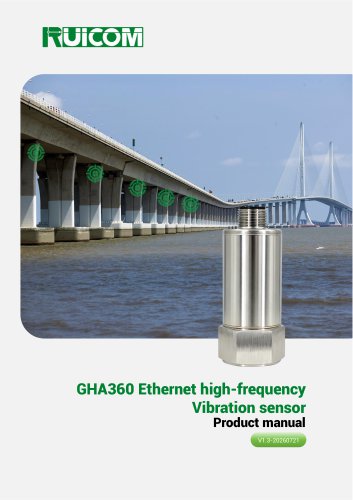
The GHA360 is a three-axis Ethernet high-frequency vibration sensor designed for industrial applications. It features synchronous acquisition of transient acceleration on X, Y, and Z axes with a maximum response frequency of 10 kHz. This sensor is equipped with a 20-bit high-resolution analog-to-digital converter, offering fine sensitivity of 0.095 mg/LSB. It supports direct data transmission to servers via a 10/100Mbps Ethernet interface, making it ideal for online monitoring and predictive maintenance of rotating machinery.
Application Field
The sensor is suitable for vibration monitoring of industrial equipment, including pumps, motors, fans, air compressors, gas engines, generators, reducers, and gearboxes.
Technical Characteristics
- Measuring range: ±50g
- Power supply: 12V
- Operating temperature: -10℃ to +70℃
- IP67 protection rating
- Bandwidth: DC~10kHz
- Low noise: 35µg/√Hz
Specifications
- Measurement Range: ±50g
- Sensitivity: 0.095 mg/LSB
- Measuring Axis: X / Y / Z Axis
- Response Frequency: DC~10 kHz
- Sampling Frequency: 80kHz
- Communication Interface: Ethernet
- Default Server Address/Port: 192.168.1.169/22009
- Default Device Address: 192.168.1.164
- Operating Ambient Temp: -40℃ ~ +85℃
- Installation Method: Magnetic or screw mounting
- Protection Rating: IP67
- Dimensions: Ø23.6×H60.6mm
- Product Weight: ≤105g
Installation Method
The sensor can be installed using a magnetic attachment or a screw mount. For screw installation, silicone grease is applied before securing the sensor with a double-ended screw.
Wiring Diagram
The sensor connects to a network power combiner via an M12-8-pin aviation connector to an RJ45 adapter cable. It requires a DC 12V power source.
Communication Protocol
The sensor uses the TCP protocol to communicate with servers. It acts as a TCP client, sending triaxial acceleration data packets to the server. The data packets contain 116 sets of vibration data for x, y, and z axes, which are used to generate continuous real-time acceleration signals.
Catalog excerpts
GHA360 Ethernet high-frequency Vibration sensor Product manual V1.3-20260721
Open the catalog to page 1
Technical Characteristics Product Introduction- GHA360 three-axis Ethernet high-frequency vibration sensor, integrated with X/Y/Z three-way transient acceleration synchronous acquisition capability, with a maximum single axis response frequency of 10 kHz, fully covering the fault characteristic frequency bands of mainstream industrial rotating machinery such as gear meshing frequency, bearing characteristic frequency, and blade passing frequency. Built in 20 bit high-resolution analog-to-digital conversion architecture, with fine sensitivity up to 0.095 mg/LSB, combining excellent linearity and...
Open the catalog to page 2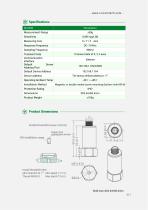
JvT Product Dimensions Install thread M5 (torque 2.5N-M) connected sensor installation screw Install threaded holes
Open the catalog to page 3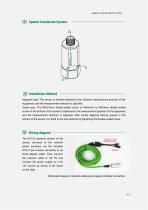
Spatial Coordinate System Installation Method Magnetic type: The sensor is directly attached to the vibration measurement position of the equipment, and the measurement direction is adjusted. Screw type: The M5×10mm double-ended screw or M5×6mm to M8*8mm double-ended screw on the bottom of the sensor is tightened to the measurement position of the equipment, and the measurement direction is adjusted. After evenly applying silicone grease to the bottom of the sensor, it is fixed to the test platform by tightening the double-ended screw. Wiring diagram The DC12V powered version of the sensor connects...
Open the catalog to page 4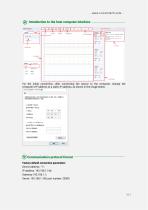
Introduction to the host computer interface For the initial connection, after connecting the sensor to the computer, change the computer's IP address to a static IP address, as shown in the image below. Communication protocol format Factory default connection parameters Device address: "1"; IP address: 192.168.1.164; Gateway: 192.168.1.1; Server: 192.168.1.169, port number: 22009.
Open the catalog to page 5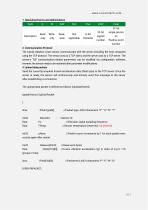
1. Specialized terms and abbreviations Term floating-point number The triaxial vibration smart sensor communicates with the server (including the host computer) using the TCP protocol. The sensor acts as a TCP client, and the server acts as a TCP server. The sensor's TCP communication-related parameters can be modified via configuration software; however, the sensor needs to be restarted after parameter modifications. Send the currently acquired triaxial acceleration data (float type) to the TCP server. Once the server is ready, the sensor will continuously and actively send this message to the...
Open the catalog to page 6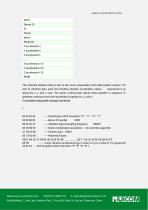
fTemp pNum Reserved X acceleration] The collected vibration data is sent to the server sequentially. Each data packet contains 116 sets of vibration data, each set including vibration acceleration values (expressed in g) along the x, y, and z axes. The server continuously splices these packets in sequence to generate continuous real-time acceleration signals for x, y, and z. For example (a data packet message is as follows): 50 55 44 54 ----Packet type, ASCII characters “P" “ U " “ D" "T" 00 00 00 00 ----Sensor temperature acquisition not currently supported 98 3B -----3-axis vibration acceleration...
Open the catalog to page 7All Shenzhen Ruicom Technology Co., Ltd. catalogs and technical brochures
 STSL Low-Power Tilt Sensor
21 Pages
 STS STANDARD OUTPUT TILT SENSOR
13 Pages
 HTS3D High-Precision Tilt Sensor
15 Pages
 GDS8 Series Digital inclinometer
13 Pages
- Display module
- Industrial display panel
- Color display panel
- Tilt sensor
- Digital inclination sensor
- Built-in display
- 2-axis tilt sensor
- MEMS inclination sensor
- Multi-axis tilt sensor
- Analog inclination sensor
- RS-485 display panel
- High-precision tiltmeter
- IP67 inclination sensor
- 1-axis tilt sensor
- Rugged inclination sensor
- High-resolution inclinometer
- 2" display
- Angle measurement inclination sensor
- RS-485 inclinometer