
- Catalogs
- SHENZHEN RION TECHNOLOGY CO.,LTD
- RION HDA436T TILT SENSOR


RION HDA436T TILT SENSOR
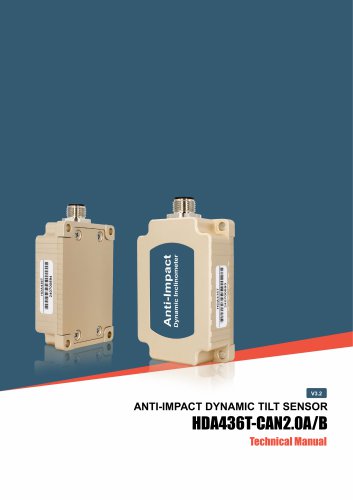
RION HDA436T TILT SENSOR
The HDA436T is a digital MEMS dynamic tilt sensor designed for measuring roll, pitch, and azimuth of moving carriers. It features acceleration and gyroscope sensors and utilizes the Kalman filter algorithm for real-time motion data measurement. The sensor supports dual CAN modes (CAN2.0A/CAN2.0B) and is suitable for high vibration and impact environments.
- Measurement range: Roll ±180°, Pitch ±90°, Azimuth ±180°
- Dynamic accuracy: ±0.1°
- Wide voltage input: DC 9~36V
- Operating temperature: -40℃ to +85℃
- High anti-vibration performance: > 2000g
- Protection level: IP67/IP68 optional
- High vibration impact equipment
- Satellite antenna star search
- Underground drilling rig navigation
- Railway locomotive monitoring
- Geological equipment tilt monitoring
- Oil drilling equipment
- Ship navigation attitude measurement
- Measurement axes: X, Y, Z
- Static accuracy: ±0.05°
- Gyro range: ±250°/s
- Acceleration range: ±8g
- Power-on startup time: ≤3.5S
- Response time: 0.01S
- MTBF: ≥ 98000 hours
- Impact resistance: 100g @ 11ms
- Supply voltage: 9-36V
- Working current: 40mA at 12V
- Operating/storage temperature: -40 to +85℃
Product configurations include options for connector type, protection level, and application type. For example, HDA436T-C2-OB indicates horizontal installation with CAN 2.0A output for on-board/ship applications.
- Connector: M12 aviation plug
- Shell material: Aluminum alloy
- Installation: Four M4 screws
The sensor uses a capacitive miniature pendulum and the earth's gravity to measure tilt. Changes in capacitance due to tilt are amplified and filtered to determine inclination.
The sensor follows the NED coordinate system with specific rotation sequences for measuring heading, pitch, and roll angles.
Pin definitions for power supply and CAN communication are provided, with specific pin assignments for power and data lines.
The sensor supports CAN2.0 protocol with options for node number modification, baud rate setting, and output cycle time configuration. Data frames include angle, acceleration, and gyro frames, with specific formats for request and response messages.
Data frames are analyzed based on type (angle, acceleration, gyro) and installation method, with examples provided for converting raw data to meaningful measurements.
The document provides technical specifications and procedures for interpreting data from the HDA436T-CAN2.0A/B dynamic tilt sensor. It explains how to convert binary data into meaningful acceleration and gyro values.
- Acceleration data is represented by a 16-bit signed binary number, split into upper (XH) and lower (XL) 8 bits. This binary number is converted to a decimal and divided by 1000 to obtain the acceleration in g.
- Gyro data follows a similar process, with the binary number divided by 100 to yield the gyro value in degrees per second (°/S).
- The CAN-ID is followed by eight bytes of data. The first two bytes represent the X-axis gyro size, the next two bytes the Y-axis, and the following two bytes the Z-axis. The seventh byte is reserved.
- Data is output in three modes: single-frame angle output, double-frame angle plus indication output, and three-frame angle gyro plus indication output.
- Single-frame angle output: Outputs one angle frame periodically.
- Double-frame angle plus indication output: Outputs two frames continuously by cycle.
- Three-frame angle gyro plus indication output: Outputs three frames continuously by cycle.
- For acceleration: XL = 0x26, XH = 0x15 results in 5.414g.
- For gyro: XL = 0x26, XH = 0x15 results in 54.14°/S.
Catalog excerpts
HDA436T-CAN2.0A/B OUTPUT DYNAMIC TILT SENSOR ANTI-IMPACT DYNAMIC TILT SENSOR
Open the catalog to page 1
HDA436T-CAN2.0A/B OUTPUT DYNAMIC TILT SENSOR ○ Revision Date: 2025-6-20 Note: The function, parameters and appearance of the product will be adjusted with the technical upgrade. Please contact our pre-sales business for confirmation when purchasing. Disclaimer This product is developed exclusively for commercial applications and is prohibited from being used for illegal purposes, such as military activities, research related to nuclear, chemical, or biological weapons, or any other actions that violate laws and regulations. It is strictly forbidden to engage in activities related to goods embargoed...
Open the catalog to page 2
The HDA436T product is a new generation of digital MEMS dynamic tilt sensor, which can measure the attitude parameters (roll, pitch, and azimuth) of a moving carrier and is suitable for tilt measurement in motion or vibration states. The HDA436T is equipped with built-in acceleration and gyroscope sensors, and integrates the Kalman filter algorithm to measure real-time motion data of the carrier under motion or vibration conditions. The product has dual CAN (CAN2.0A/CAN2.0B) modes and strong scalability. This product adopts non-contact measurement of raw materials and can output the current posture...
Open the catalog to page 3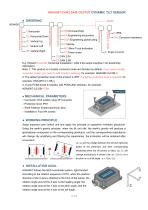
HDA436T-CAN2.0A/B OUTPUT DYNAMIC TILT SENSOR EV:Engineering excavators EGP:Engineering gravel piling V:Vehicle MTI:Mine Truck inclination TC:Tower crane Protection Grade Application types Output Interface Installation direction C2:CAN 2.0A C3:CAN 2.0B E.g: HDA436T-C2-OB: Horizontal Installation / CAN 2.0A output interface / On-board/ship Application. Note: 1. This product is a double connector (male and female) by default. If you need a single connector (male), you need to add S before ordering, for example: HDA436T-C2-OB-S; 2. The default protection level of this product is IP67. If a higher...
Open the catalog to page 5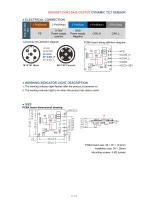
1. The working indicator light flashes after the product is powered on; 2. The working indicator light is on when the product has data to send.
Open the catalog to page 6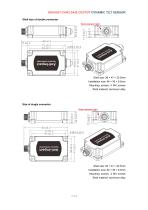
HDA436T-CAN2.0A/B OUTPUT DYNAMIC TILT SENSOR Shell size of double connector Shell size: 96 × 47 × 22.5mm Installation size: 64 × 39 × 6.5mm Mounting screws: 4 M4 screws Shell material: aluminum alloy Size of single connector Shell size: 83 × 47 × 22.5mm Installation size: 64 × 39 × 6.5mm Mounting screws: 4 M4 screws Shell material: aluminum alloy
Open the catalog to page 7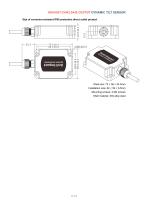
HDA436T-CAN2.0A/B OUTPUT DYNAMIC TILT SENSOR Size of corrosion-resistant IP68 protection direct outlet product Shell size: 72 × 56 × 24.5mm Installation size: 64 × 39 × 6.5mm Mounting screws: 4 M4 screws Shell material: 304 alloy steel
Open the catalog to page 8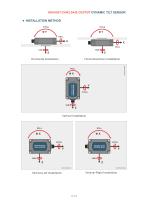
HDA436T-CAN2.0A/B OUTPUT DYNAMIC TILT SENSOR ● INSTALLATION METHOD
Open the catalog to page 9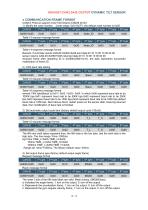
• COMMUNICATION FRAME FORMAT CAN2.0 Protocol support 2.0A(11bit ID)and 2.0B(29 bit ID) 1) Modify the node number. (node range: 0x01-0x7F), the default node number is 0x05 The lower 3 bits of the fifth byte Mask are valid. Mask (binary: 0B00000cba). a: indicates the angle frame, 1: turn on the output, 0: turn off the output. b: Represents the acceleration frame, 1: turn on the output, 0: turn off the output. c: Represents the gyro angular velocity frame, 1: turn on the output, 0: turn off the output.
Open the catalog to page 10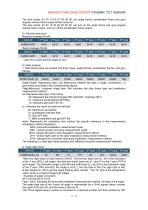
The host sends: 40 30 10 00 07 00 00 00, the angle frame, acceleration frame and gyro angular velocity frame output will be turned on. The host sends: 40 30 10 00 05 00 00 00, will turn on the angle frame and gyro angular velocity frame output, and turn off the acceleration frame output. 5) Azimuth clear zero Request message format There are eight bytes of data behind CAN-ID. The first two bytes are XL, XH is the inclination of the X axis (RoLl roll angle), the third and fourth bytes are YL, and YH is the Y axis (PITCH pitch angle). The inclination angle is the fifth and sixth bytes ZL, and ZH...
Open the catalog to page 11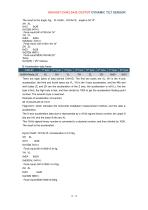
The result is the angle. Eg, XL=0x26, XH=0x15, angle is 54.14° XH XL 0x15 0x26 B: Acceleration data frame There are eight bytes of data behind CAN-ID. The first two bytes are XL, XH is the X-axis acceleration, the third and fourth bytes are YL, YH is the Y-axis acceleration, and the fifth and sixth bytes ZL and ZH are the acceleration of the Z axis; the acceleration is int16_t, the low byte is first, the high byte is last, and then divide by 1000 to get the acceleration floating point number. The seventh byte is reserved. Example of acceleration conversion: Flag=0x01, which indicates the horizontal...
Open the catalog to page 12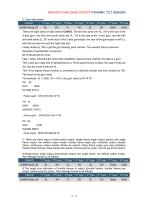
C: Gyro data frame
Open the catalog to page 13All SHENZHEN RION TECHNOLOGY CO.,LTD catalogs and technical brochures
 RION SMI815 SMI825
5 Pages
 RION DMI850 inclinometer
9 Pages
 RION WCA300A
3 Pages
 RION PSI-25M
1 Page
 Rion inclinometer SDA118T
10 Pages
 SDA116T/SDA126T
16 Pages
 RION SDA116T/SDA126T-CAN OPEN
11 Pages
 Rion SDA110T inclinometer
9 Pages
 Rion inclinometer SCA118T
10 Pages
 Rion inclinometer SCA116
16 Pages
 Rion inclinometer SCA110
10 Pages
 Rion inclinometer PCA826T
21 Pages
 Rion inclinometer MCA418T
2 Pages
 Rion inclinometer MCA416T
2 Pages
 Rion inclinometer MCA416LD
10 Pages
 Rion inclinometer MCA416L
10 Pages
 Rion inclinometer MCA416
2 Pages
 Rion inclinometer MCA410T
2 Pages
 Rion inclinometer MCA-85
12 Pages
 Rion inclinometer LCA318T
10 Pages
 Rion HCA518T inclinometer
9 Pages
 Rion inclinometer HCA510T-N
11 Pages
 Rion inclinometer HCA510T
8 Pages
 Rion inclinometer HCA396B
11 Pages
 RION HDA536T INCLINOMETER
25 Pages
 HDA437T/HDA437T-CAN2.0A/B
14 Pages
 HDA437T/HDA437
25 Pages
 HDA436T
25 Pages
 HDA436T-CANOpen
28 Pages
 ACA816T/ACA826T
17 Pages
 ACA618T/ACA628T-N
9 Pages
 Rion inclinometer ACA610T
9 Pages
 Rion electronic compass DDM350B
11 Pages
 Rion electronic compass DCM301B
11 Pages
 Rion electronic compass DCM250B
12 Pages
 Rion AKM398 Vibration Sensor
6 Pages
 Rion AKM392 Vibration Sensor
15 Pages
 Rion AKM390 Vibration Sensor
6 Pages
 Rion Vibration Sensor AKG392
17 Pages



Archived catalogs
 SCA116T/SCA126T
9 Pages
- LCD screen
- Industrial monitor
- Panel-mount screen
- Pressure probe
- High-brightness monitor
- RION inclinometer
- TFT-LCD monitor
- Analog pressure sensor
- RION digital inclinometer
- Stainless steel pressure sensor
- RION 2-axis inclinometer
- Relative pressure sensor
- RION MEMS inclinometer
- RION multi-axis inclinometer
- RION high-precision inclinometer
- Absolute pressure sensor
- RION analog inclinometer
- Gas pressure sensor
- RION IP67 inclinometer
- Sensitive element pressure sensor