
- Catalogs
- SHENZHEN RION TECHNOLOGY CO.,LTD
- RION HDA536T INCLINOMETER


RION HDA536T INCLINOMETER
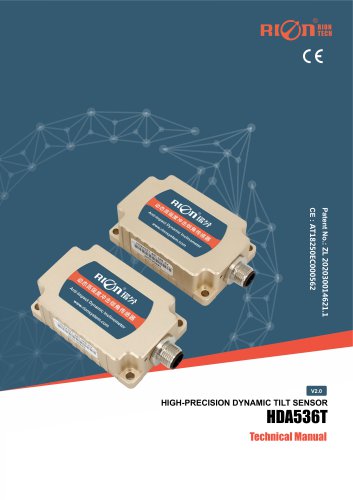
RION HDA536T INCLINOMETER
The HDA536T is a high-precision dynamic tilt sensor by RION Technology, designed for environments with motion or vibration. It measures roll, pitch, and azimuth using a built-in high-precision acceleration and gyro sensor, and the Carman filter algorithm for real-time data. It supports RS485/232/TTL signal outputs and is highly scalable.
- Measurement range: Roll ±180°, Pitch ±90°, Azimuth ±180°
- Dynamic accuracy: ±0.1°
- Voltage input: DC 9-36V
- Operating temperature: -40 to +85°C
- Resolution: 0.01°
- Protection level: IP67
- Anti-vibration: >2000g
- Railway locomotive monitoring
- Oil drilling equipment
- Geological equipment tilt monitoring
- Ship navigation attitude measurement
- Engineering machinery inclination measurement
- Measurement axes: X, Y, Z
- Gyro range: ±300°/s
- Acceleration range: ±6g
- Output signal options: RS485/RS232/TTL
- Electromagnetic compatibility: EN61000, GBT17626
- MTBF: ≥ 98000 hours
- Impact resistance: 100g @ 11ms
- Supply voltage: 9-36V
- Working current: 60mA at 12V
- Operating/storage temperature: -40 to +85°C
- Connector: M12 aviation plug
- Shell material: Frosted aluminum alloy
- Installation: Four M4 screws
The sensor uses a capacitive miniature pendulum principle, leveraging Earth's gravity to measure tilt. Changes in capacitance due to tilt are amplified and filtered to determine inclination.
The sensor follows the NED coordinate system and uses a right-handed rotation sequence. Electrical connections are defined for RS485 and RS232/TTL interfaces.
The sensor supports binary protocol communication with a frame format including sync byte, address, command, and data fields. It operates in query and continuous output modes, with default settings for baud rate and output frequency.
Data output includes attitude angles, triaxial angular velocity, and triaxial acceleration, with storage formats specified for each type.
Commands include setting and getting automatic output data items, and continuous data output, with specific frame formats for each command.
- Setting Output Mode: Use command 0x53 to set the sensor to continuous mode. The default frequency is 10Hz, adjustable up to 200Hz.
- Baud Rate Configuration: Command 0x12 sets the communication baud rate, with options ranging from 9600 to 256000 bps. The default is 115200 bps.
- Address Configuration: Command 0x0F sets the sensor address for communication. The default address is 0x00.
- Installation Mode: Command 0x20 configures the sensor's installation orientation, with options for horizontal and various vertical positions.
- Gravity Magnitude: Command 0xB1 sets the gravity magnitude level, which must be saved with a separate command.
- Saving Settings: Command 0x24 saves all configuration settings to EEPROM for power-down retention.
- Angle data is represented in a 14-byte format, with roll, pitch, and heading angles each occupying 4 bytes. Temperature data occupies the last 2 bytes.
- Angles are calculated from data points, with specific offsets for different measurement ranges.
- Zero Setting: Commands are provided to set the sensor to relative or absolute zero using Modbus Functional code 06H. The register address 0010H determines the zero setting.
- Address Setting: The sensor address can be changed from the factory default using specific commands. The register address 0011H is used for this purpose.
- Baud Rate Setting: The document outlines how to set the sensor's baud rate, with options ranging from 4800 to 115200 bps. The register address 0012H controls this setting.
- Communication Format: Instructions are provided for setting the communication character format, including options for parity and stop bits.
- Output Frequency: The sensor's automatic output frequency can be set, with options from 0 Hz (query mode) to 100 Hz. The register address 0013H is used for this configuration.
Commands must be sent twice consecutively to be effective, with no other commands in between. Examples are provided for each command type, including setting zero points, changing addresses, and adjusting baud rates.
A specific command is available to reset the sensor's heading angle to zero, ensuring accurate measurements.
Catalog excerpts
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR HIGH-PRECISION DYNAMIC TILT SENSOR
Open the catalog to page 1
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR RION QUALIFICATION CERTIFICATION ○ China National Intellectual Property Appearance Patent (Patent No.: ZL 202030439670. X) ○ CE CERTIFICATION: Registration No. AT18250EC001210 ○ Revision Date: 2024-9-9 Note: The function, parameters and appearance of the product will be adjusted with the technical upgrade. Please contact our pre-sales business for confirmation when purchasing. Disclaimer This product is developed exclusively for commercial applications and is prohibited from being used for illegal purposes, such as military activities, research related...
Open the catalog to page 2
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR HDA536T A new generation of digital MEMS dynamic tilt sensor launched by RION Technology. It can measure the attitude parameters (roll, pitch, and azimuth) of a moving carrier, and suitable for tilt angle measurement under motion or vibration. HDA536T has a built-in high-precision acceleration and gyro sensor, and integrates the Carman filter algorithm, which can measure the real-time motion data of the carrier under motion or vibration. The signal output modes such as RS485 / 232 / TTL are optional, and the scalability is strong. This product uses non-contact...
Open the catalog to page 3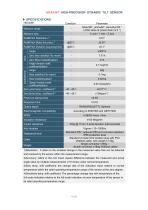
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR ▶ SPECIFICATIONS HDA536T Measure range Measure axis Parameter Roll±180°, pitch±90°, azimuth±180 ° (initial value at power-down is 0 °) X axis / Y axis / Z axis Zero bias stability(10s mean) Zero Bias Instability(allan) Angle random walk coefficient(allan) range Bias instability(allan) Speed random walk coefficient(allan) Zero point temp. coefficient3) Roll&Pitch Resolution 1) Roll&Pitch Static Accuracy Roll&Pitch Dynamic Accuracy(rms) Gyro Acceleration Sensitivity temp. coefficient Power-on startup time Response time Output signal Electromagnetic compatibility...
Open the catalog to page 4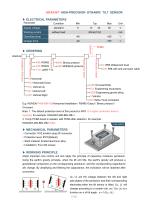
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR ▶ ELECTRICAL PARAMETERS Parameter Supply voltage Working current without load Operating temp storage temp BIN: Binary protocol MB: MODBUS protocol T: Horizontal TD: Horizontal Down Protection Grade Application types Output Interface Installation Direction 8: IP68 Waterproof level DW: P68 with anti-corrosion cable EGP:Engineering gravel piling MTI:Mine Truck inclination E.g: HDA536T-485-BIN-OB:Horizontal installation / RS485 Output / Binary protocol / On-board. Note: 1. The default protection level of this product is IP67. If a higher protection level...
Open the catalog to page 5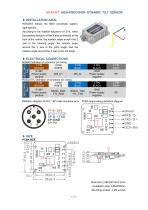
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR ▶ INSTALLATION AXIAL HDA536T follows the NED coordinate system, right-handed. According to the rotation sequence of ZYX, when the positive direction of the X axis is directed to the front of the carrier, the rotation angle around the Z axis is the heading angle, the rotation angle around the Y axis is the pitch angle, and the rotation angle around the X axis is the roll angle. ▶ ELECTRICAL CONNECTIONS PIN FUNCTION RS485 Definition of connector pin wiring 1 PIN 2 PIN 3 PIN BROWN WHITE BLUE 9~36V Power supply 485_D+ 485_Dpositive RS232/TTL Definition of...
Open the catalog to page 6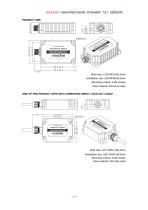
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR PRODUCT SIZE Shell size: L72xW47xH22.5mm Installation size: L64xW39xH6.5mm Mounting screws: 4 M4 screws Case material: Aluminum alloy SIZE OF IP68 PRODUCT WITH ANTI-CORROSION DIRECT LEAD OUT CABLE Shell size: L72×W56×H24.5mm Installation size: L64×W39×H6.5mm Mounting screws: 4 M4 screws Case material: 304 alloy steel AY)
Open the catalog to page 7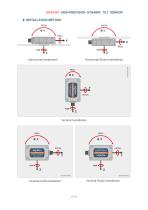
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR ▶ INSTALLATION METHOD
Open the catalog to page 8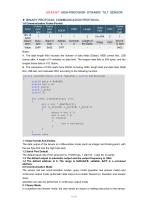
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR ▶ BINARY PROTOCOL COMMUNICATION PROTOCOL 1.0 Communication Frame Format Frame Frame Field sync start ADDR byte byte No. of 1 1 1 bytes Descri Sync. Start of Addres ption byte byte s Value 0xFF 0x02 0-FF Data field Notes: A. The data length field includes the number of data fields (Datas). MSB comes first, LSB comes after. A length of 0 indicates no data field. The longest data field is 504 bytes, and the longest frame byte is 512. Bytes. B. The calculation of CRC starts from ADDR, including CMD, length field and data field, MSB first, LSB last, and calculate...
Open the catalog to page 9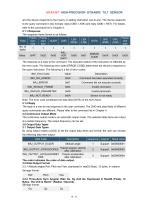
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR and the device responds to the inquiry or setting instruction one-to-one. The device responds to the query command in two formats: reply (CMD = ASK) and reply (CMD = RET). For details, refer to the command list in Chapter 4. 2.1.1 Response The response frame format is as follows: Frame Frame Frame LEN LEN CRC CRC Field sync start ADDR CMD DATA end (MSB) (LSB) (MSB) (LSB) byte byte byte No. of 1 1 1 1 1 1 1 1 1 1 bytes IMU_ ERROR Value 0xFF 0x02 0x00 ACK 0x00 0x01 0xXX 0xXX 0x03 CODE (0x01) The response is a reply to the command. The execution status...
Open the catalog to page 10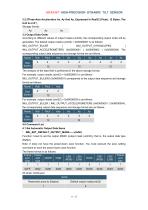
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR 3.2.3Three-Axis Acceleration Ax, Ay And Az, Expressed In Real32 (Float), 12 Bytes, The Unit Is m.S-2。 Storage format: Ax 3.3 Output Data Order According to different values of output masks (uint32), the corresponding output order will be generated. The default output masks (uint32) = 0x00000007 is as follows: IMU_OUTPUT_EULER IMU_OUTPUT_ACCELEROMETERS (0x00000001 | 0x00000002 | 0x00000004) The corresponding output data sequence and storage format are as follows: Name Size (bytes) The analysis of the data field is performed in the above storage format....
Open the catalog to page 11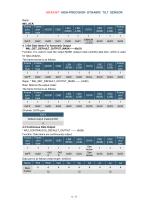
HDA536T HIGH-PRECISION DYNAMIC TILT SENSOR Reply: IMU_ACK Frame Frame sync start byte byte 1 1 0xFF DATA 1 ERROR _CODE 4. 2 Get Data Items For Automatic Output * IMU_GET_DEFAULT_OUTPUT_MASK------(0x51) Function: It is used to read the output MASK (output mask (uint32)) data item, which is used for data analysis. The frame format is as follows: Frame Frame sync start ADDR CMD byte byte 1 1 1 1 0xFF Reply: * IMU_RET_DEFAULT_OUTPUT_MASK ------ (0x52) Role: Returns the output mask; The frame format is as follows: Frame Frame sync start ADDR CMD byte byte 1 1 1 1 0xFF Of which: DATA part DATA Default...
Open the catalog to page 12All SHENZHEN RION TECHNOLOGY CO.,LTD catalogs and technical brochures
 RION HDA436T TILT SENSOR
14 Pages
 RION SMI815 SMI825
5 Pages
 RION DMI850 inclinometer
9 Pages
 RION WCA300A
3 Pages
 RION PSI-25M
1 Page
 Rion inclinometer SDA118T
10 Pages
 SDA116T/SDA126T
16 Pages
 RION SDA116T/SDA126T-CAN OPEN
11 Pages
 Rion SDA110T inclinometer
9 Pages
 Rion inclinometer SCA118T
10 Pages
 Rion inclinometer SCA116
16 Pages
 Rion inclinometer SCA110
10 Pages
 Rion inclinometer PCA826T
21 Pages
 Rion inclinometer MCA418T
2 Pages
 Rion inclinometer MCA416T
2 Pages
 Rion inclinometer MCA416LD
10 Pages
 Rion inclinometer MCA416L
10 Pages
 Rion inclinometer MCA416
2 Pages
 Rion inclinometer MCA410T
2 Pages
 Rion inclinometer MCA-85
12 Pages
 Rion inclinometer LCA318T
10 Pages
 Rion HCA518T inclinometer
9 Pages
 Rion inclinometer HCA510T-N
11 Pages
 Rion inclinometer HCA510T
8 Pages
 Rion inclinometer HCA396B
11 Pages
 HDA437T/HDA437T-CAN2.0A/B
14 Pages
 HDA437T/HDA437
25 Pages
 HDA436T
25 Pages
 HDA436T-CANOpen
28 Pages
 ACA816T/ACA826T
17 Pages
 ACA618T/ACA628T-N
9 Pages
 Rion inclinometer ACA610T
9 Pages
 Rion electronic compass DDM350B
11 Pages
 Rion electronic compass DCM301B
11 Pages
 Rion electronic compass DCM250B
12 Pages
 Rion AKM398 Vibration Sensor
6 Pages
 Rion AKM392 Vibration Sensor
15 Pages
 Rion AKM390 Vibration Sensor
6 Pages
 Rion Vibration Sensor AKG392
17 Pages



Archived catalogs
 SCA116T/SCA126T
9 Pages
- LCD screen
- Industrial monitor
- Panel-mount screen
- Pressure probe
- High-brightness monitor
- RION inclinometer
- TFT-LCD monitor
- Analog pressure sensor
- RION digital inclinometer
- Stainless steel pressure sensor
- Relative pressure sensor
- RION 2-axis inclinometer
- RION MEMS inclinometer
- RION multi-axis inclinometer
- Absolute pressure sensor
- RION analog inclinometer
- Gas pressure sensor
- Sensitive element pressure sensor
- RION high-precision inclinometer
- Liquid pressure sensor