
- Catalogs
- SHENZHEN RION TECHNOLOGY CO.,LTD
- HDA437T/HDA437


HDA437T/HDA437
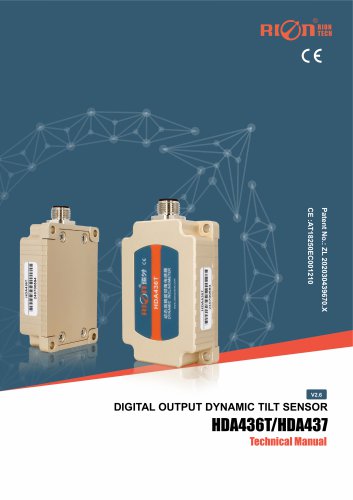
HDA437T/HDA437
The HDA436T/HDA437T is a digital MEMS dynamic tilt sensor by RION Technology, designed for measuring roll, pitch, and azimuth in environments with motion or vibration. It features high-precision acceleration and gyro sensors, utilizing the Kalman filter algorithm for real-time data measurement. The sensor supports RS485, RS232, and TTL output modes, suitable for industrial environments with high shock and vibration.
- Measurement range: Roll ±180°, Pitch ±90°, Azimuth ±180°
- Resolution: 0.01°
- Dynamic accuracy: ±0.1°; Static accuracy: ±0.05°
- Operating temperature: -40°C to +85°C
- Protection level: IP67/IP68
- High vibration impact equipment
- Railway locomotive monitoring
- Satellite communication vehicle attitude detection
- Geological equipment tilt monitoring
- Ship navigation attitude measurement
- Gyro range: ±250°/s
- Zero bias stability: 8.5°/h
- Acceleration range: HDA436T: ±8g, HDA437T: ±20g
- Power-on startup time: ≤3.5S
- Response time: 0.01S
- Supply voltage: 9-36V
- Working current: 60mA at 12V
- Operating temperature: -40°C to +85°C
- Connector: M12 aviation plug
- Shell material: Aluminum alloy
- Installation: Four M4 screws
The sensor uses a capacitive miniature pendulum and the earth's gravity to measure tilt angles. Changes in capacitance due to tilt are amplified, filtered, and converted to obtain the dip angle.
The sensor supports binary and MODBUS protocols with RS485, RS232, and TTL interfaces. It operates in query and continuous output modes, with a default baud rate of 115200 bps and an output frequency of 10Hz.
The sensor follows the NED coordinate system and uses a right-handed rotation sequence. Electrical connections are defined for RS485 and RS232/TTL interfaces, with specific pin functions for power supply and data transmission.
The sensor supports continuous data output with a default output mask of uint32. Data items include Roll, Pitch, Yaw, Gx, Gy, Gz, Ax, Ay, and Az, each occupying 4 bytes.
Two output modes are available: IMU_QUERY_MODE (0x00) and IMU_CONTINUOUS_MODE (0x01). The continuous mode supports various output frequencies based on the Divider value, with a default frequency of 10Hz.
- Set Output Mode: IMU_SET_CONTINUOUS_MODE (0x53)
- Get Output Mode: IMU_GET_CONTINUOUS_MODE (0x54)
- Set Baud Rate: IMU_SET_PROTOCOL_MODE (0x12)
- Get Baud Rate: IMU_GET_PROTOCOL_MODE (0x13)
- Set Sensor Address: IMU_SET_ADDR (0x0F)
- Get Sensor Address: IMU_GET_ADDR (0x0D)
- Set Measurement Installation Method: IMU_SET_FIXED_MODE (0x20)
- Set Gravity Magnitude: IMU_SET_GRAVITY_MAGNITUDE (0xB1)
- Save Settings: IMU_SAVE_SETTINGS (0x24)
- Default Data Query: IMU_GET_DEFAULT_OUTPUT (0x56)
- Get Specified Data Item Output: IMU_GET_SPECIFIC_OUTPUT (0x58)
The document details the MODBUS communication protocol, including data frame format and reading angle data. It specifies a 5ms interval between data frames and outlines the process for setting commands to improve system reliability.
1. Obtain current angle points, noting the low byte first. Example values: Roll angle - 000396C4H, Pitch angle - 00019BF8H, Azimuth angle - 0002546BH.
2. Convert to decimal: Roll - 235204, Pitch - 105464, Azimuth - 152683.
3. Subtract offset (180000 for ±180º range): Roll - 55204, Pitch - 15464, Azimuth - -27317.
4. Final angles: Roll - 55.204º, Pitch - 15.464º, Azimuth - -27.317º.
Temperature is derived from the 13th-14th byte. The upper four bits of the 13th byte indicate sign, and the lower four bits are tens. The 14th byte's high four bits are ones, and the low four bits are tenths. Example: 03H and 06H indicate 30.6℃.
- Set Sensor Zero: Use Modbus Functional code 06H. Relative zero if non-zero, absolute zero if zero.
- Set Sensor Address: Default is 01H. Change using code 06H and register address 0011H.
- Set Baud Rate: Default is 9600 bps. Change using code 06H and register address 0012H. Options include 4800, 9600, 19200, 38400, 115200 bps.
- Read Sensor Address: Use code 42H to retrieve the current sensor address.
- Set Communication Format: Default is even parity. Change using code 06H and register address 0009H. Options include no parity, odd parity, even parity.
- Set Output Frequency: Default is 0 Hz (query mode). Change using code 06H and register address 0013H. Options include 5Hz, 10Hz, 20Hz, 25Hz, 50Hz, 100Hz.
- Clear Heading Angle: Use code 06H and register address 0015H to reset the heading angle to zero.
Commands must be sent twice consecutively without interruption to be effective.
Catalog excerpts
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR DIGITAL OUTPUT DYNAMIC TILT SENSOR
Open the catalog to page 1
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR RION QUALIFICATION CERTIFICATION ○ China National Intellectual Property Appearance Patent (Patent No.: ZL 202030439670.X) ○ CE certification: AT18250EC001210 ○ Revision date: 2024-9-9 Note: Product functions, parameters, appearance, etc. will be adjusted as the technology upgrades. Please contact our pre-sales business to confirm when purchasing. Disclaimer This product is developed exclusively for commercial applications and is prohibited from being used for illegal purposes, such as military activities, research related to nuclear, chemical,...
Open the catalog to page 2
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR HDA436T/HDA437T A new generation of digital MEMS dynamic tilt sensor launched by RION Technology. It can measure the attitude parameters (roll, pitch, and azimuth) of a moving carrier, and suitable for tilt angle measurement under motion or vibration.HDA436T has a built-in high-precision acceleration and gyro sensor, and integrates the Kalman filter algorithm, which can measure the real-time motion data of the carrier under motion or vibration. The signal output modes such as RS485 / RS232 / TTL are optional, and the scalability is strong. This...
Open the catalog to page 3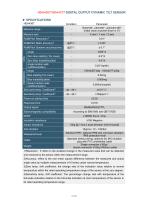
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR ▶ SPECIFICATIONS HDA436T Measure range Measure axis Parameter Roll±180°, pitch±90°, azimuth±180° (initial value at power-down is 0°) X axis / Y axis / Z axis Roll&Pitch Dynamic accuracy(rms) Zero bias stability (10s mean) Zero Bias Instability(allan) Angle random walk coefficient(allan) range Gyro Acceleration Bias instability(allan) Speed random walk coefficient(allan) Zero point temp. Coefficient3) Power-on startup time Response time Output signal Electromagnetic compatibility Insulation resistance Impact resistance ≥100 Megohm 100g @ 11ms,3...
Open the catalog to page 4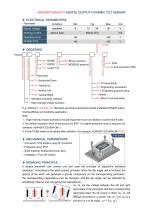
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR ▶ ELECTRICAL PARAMETERS Parameter Supply voltage Working current without load Operating temp storage temp BIN: Binary protocol MB: MODBUS protocol T: Horizontal TD: Horizontal Down VU: Vertical Up Protection Grade Application types Output Interface Installation Direction Application scenario OB: On-board/ship EV: Engineering excavators EGP:Engineering gravel piling 6: Standard industrial scenario MTI:Mine Truck inclination 7: High-intensity impact scenario E.g: HDA436T-485-BIN-OB: Standard industrial scenario/horizontal installation/RS485 output...
Open the catalog to page 5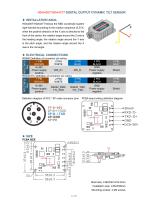
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR ▶ INSTALLATION AXIAL HDA436T/HDA437T follows the NED coordinate system, right-handed.According to the rotation sequence of ZYX, when the positive direction of the X axis is directed to the front of the carrier, the rotation angle around the Z axis is the heading angle, the rotation angle around the Y axis is the pitch angle, and the rotation angle around the X axis is the roll angle. RS485 Definition of connector pin wiring 1 PIN 2 PIN 3 PIN BROWN WHITE BLUE 9~36V Power supply 485_D+ 485_Dpositive RS232/TTL Definition of connector pin wiring...
Open the catalog to page 6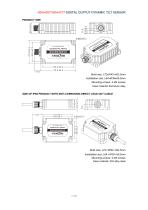
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR PRODUCT SIZE Shell size: L72xW47xH22.5mm Installation size: L64xW39xH6.5mm Mounting screws: 4 M4 screws Case material: Aluminum alloy SIZE OF IP68 PRODUCT WITH ANTI-CORROSION DIRECT LEAD OUT CABLE Shell size: L72×W56×H24.5mm Installation size: L64×W39×H6.5mm Mounting screws: 4 M4 screws Case material: 304 alloy steel AY)
Open the catalog to page 7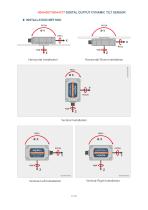
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR ▶ INSTALLATION METHOD
Open the catalog to page 8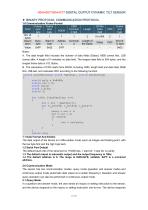
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR ▶ BINARY PROTOCOL COMMUNICATION PROTOCOL 1.0 Communication Frame Format Frame Frame Field sync start ADDR byte byte No. of 1 1 1 bytes Descri Sync. Start of Addres ption byte byte s Value 0xFF 0x02 0-FF DATAs Data field Notes: A. The data length field includes the number of data fields (Datas). MSB comes first, LSB comes after. A length of 0 indicates no data field. The longest data field is 504 bytes, and the longest frame byte is 512. Bytes. B. The calculation of CRC starts from ADDR, including CMD, length field and data field, MSB first, LSB...
Open the catalog to page 9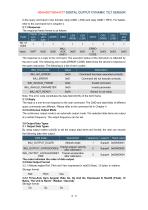
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR to the query command in two formats: reply (CMD = ASK) and reply (CMD = RET). For details, refer to the command list in Chapter 4. 2.1.1 Response The response frame format is as follows: Frame Frame Frame LEN LEN CRC CRC Field sync start ADDR CMD DATA end (MSB) (LSB) (MSB) (LSB) byte byte byte No. of 1 1 1 1 1 1 1 1 1 1 bytes IMU_ ERRO Value 0xFF 0x02 0x00 ACK 0x00 0x01 R 0xXX 0xXX 0x03 (0x01) CODE The response is a reply to the command. The execution status of the instruction is reflected by the error code. The following error code (ERROR CODE)...
Open the catalog to page 10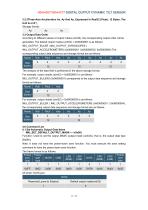
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR 3.2.3Three-Axis Acceleration Ax, Ay And Az, Expressed In Real32 (Float), 12 Bytes, The Unit Is m.S-2。 Storage format: Ax 3.3 Output Data Order According to different values of output masks (uint32), the corresponding output order will be generated. The default output masks (uint32) = 0x00000007 is as follows: IMU_OUTPUT_EULER | IMU_OUTPUT_GYROSCOPES | IMU_OUTPUT_ACCELEROMETERS (0x00000001 | 0x00000002 | 0x00000004) The corresponding output data sequence and storage format are as follows: Name Size (bytes) The analysis of the data field is performed...
Open the catalog to page 11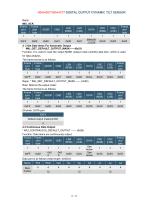
HDA436T/HDA437T DIGITAL OUTPUT DYNAMIC TILT SENSOR Reply: IMU_ACK Frame Frame sync start byte byte 1 1 0xFF DATA 1 ERROR _CODE 4. 2 Get Data Items For Automatic Output * IMU_GET_DEFAULT_OUTPUT_MASK------(0x51) Function: It is used to read the output MASK (output mask (uint32)) data item, which is used for data analysis. The frame format is as follows: Frame Frame sync start ADDR CMD byte byte 1 1 1 1 0xFF Reply: * IMU_RET_DEFAULT_OUTPUT_MASK ------ (0x52) Role: Returns the output mask; The frame format is as follows: Frame Frame sync start ADDR CMD byte byte 1 1 1 1 0xFF Of which: DATA part DATA...
Open the catalog to page 12All SHENZHEN RION TECHNOLOGY CO.,LTD catalogs and technical brochures
 RION HDA436T TILT SENSOR
14 Pages
 RION SMI815 SMI825
5 Pages
 RION DMI850 inclinometer
9 Pages
 RION WCA300A
3 Pages
 RION PSI-25M
1 Page
 Rion inclinometer SDA118T
10 Pages
 SDA116T/SDA126T
16 Pages
 RION SDA116T/SDA126T-CAN OPEN
11 Pages
 Rion SDA110T inclinometer
9 Pages
 Rion inclinometer SCA118T
10 Pages
 Rion inclinometer SCA116
16 Pages
 Rion inclinometer SCA110
10 Pages
 Rion inclinometer PCA826T
21 Pages
 Rion inclinometer MCA418T
2 Pages
 Rion inclinometer MCA416T
2 Pages
 Rion inclinometer MCA416LD
10 Pages
 Rion inclinometer MCA416L
10 Pages
 Rion inclinometer MCA416
2 Pages
 Rion inclinometer MCA410T
2 Pages
 Rion inclinometer MCA-85
12 Pages
 Rion inclinometer LCA318T
10 Pages
 Rion HCA518T inclinometer
9 Pages
 Rion inclinometer HCA510T-N
11 Pages
 Rion inclinometer HCA510T
8 Pages
 Rion inclinometer HCA396B
11 Pages
 RION HDA536T INCLINOMETER
25 Pages
 HDA437T/HDA437T-CAN2.0A/B
14 Pages
 HDA436T
25 Pages
 HDA436T-CANOpen
28 Pages
 ACA816T/ACA826T
17 Pages
 ACA618T/ACA628T-N
9 Pages
 Rion inclinometer ACA610T
9 Pages
 Rion electronic compass DDM350B
11 Pages
 Rion electronic compass DCM301B
11 Pages
 Rion electronic compass DCM250B
12 Pages
 Rion AKM398 Vibration Sensor
6 Pages
 Rion AKM392 Vibration Sensor
15 Pages
 Rion AKM390 Vibration Sensor
6 Pages
 Rion Vibration Sensor AKG392
17 Pages



Archived catalogs
 SCA116T/SCA126T
9 Pages
- LCD screen
- Industrial monitor
- Panel-mount screen
- Pressure probe
- High-brightness monitor
- RION inclinometer
- TFT-LCD monitor
- Analog pressure sensor
- RION digital inclinometer
- Stainless steel pressure sensor
- RION 2-axis inclinometer
- Relative pressure sensor
- RION MEMS inclinometer
- RION multi-axis inclinometer
- RION high-precision inclinometer
- Absolute pressure sensor
- RION analog inclinometer
- Gas pressure sensor
- RION IP67 inclinometer
- Sensitive element pressure sensor