
- Catalogs
- Portescap S.A.
- BRUSH DC motor


- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
BRUSH DC motor

BRUSH DC motor
Portescap's Brush DC motors are engineered for high efficiency and power density, making them suitable for applications in fields such as medical and aerospace. Their coreless design minimizes size, weight, and heat, ideal for portable and compact devices.
These motors feature extended commutator life, reduced electro erosion via the REE system, and improved performance with Neodymium magnets. The coreless rotor design enhances weight reduction and compactness, leading to high acceleration and efficiency.
Portescap offers custom motor solutions, including shaft extensions, custom coil designs, and special lubrications. Standard features include a broad range of torque and speed, long-life patented commutation systems, and optional gearboxes and encoders.
DC motors comprise three main components: the stator, brush holder endcap, and rotor. The stator includes a permanent magnet and steel tube, while the rotor features an ironless, bell-shaped design. The document discusses various armature fabrication methods, emphasizing the benefits of ironless rotor DC motors over traditional iron core motors.
The document details the electromechanical properties of motors with ironless rotors, using equations to describe power supply voltage, induced voltage, and rotor torque. It also covers motor constants, starting current, and torque calculations, considering temperature effects on rotor resistance.
Brush DC motors are available in diameters from 8mm to 35mm, with continuous torque ranging from 0.66 to 158.6 mNm and speeds from 11,000 RPM to 5,500 RPM. Their high efficiency makes them suitable for battery-fed applications across various sectors, including medical and aerospace.
Portescap's Brush DC motors provide innovative solutions for demanding applications, emphasizing rapid prototyping and collaborative engineering to meet unique customer needs.
- Motor Constant Calculation: For the motor 23D21-216E, the motor constant k is calculated as 0.0232 Vs using the no-load speed, current, and resistance.
- Starting Current and Torque: At 40°C, the rotor resistance is 10.2 Ω, with a starting current of 1.18 A and starting torque of 0.027 Nm.
- Speed with Load Torque: With a load torque of 0.008 Nm and a 9V power supply at 40°C, the motor reaches 2200 rpm, drawing 357 mA.
- Torque at Specific Speed: At 3000 rpm and 15V, the current is 0.466 A, and the torque load is 0.0105 Nm.
- Required Voltage for Specific Speed: To achieve 4000 rpm with a load torque of 0.008 Nm at 40°C, the required voltage is 13.4V.
- Motor Types and Characteristics: Various motor types are listed with specifications like maximum continuous torque, motor regulation, and rotor inertia, including models such as 08GS, 16N28, 23V, and 35GLT.
- Coreless Motor Selection: Guidelines for selecting coreless motors based on generation, bearing type, coil type, and commutation size are provided.
- Medical Applications: Used in medical analyzers, infusion pumps, and surgical instruments for their high efficiency and precision.
- Security and Aerospace: Beneficial in security cameras, locks, and aerospace applications for low noise and high efficiency.
- Robotics and Automation: Offer high power and low weight advantages in robotics and factory automation.
- Power Hand Tools: Provide high efficiency and low noise in tools like shears and nail guns.
- Motor Regulation Factor: The motor regulation factor (R/k²) is crucial for performance, with lower values indicating better efficiency and less heat loss.
- Brush DC Motors: Highlighted for their application in high throughput and precision tasks due to low rotor inertia and compact size.
Catalog excerpts

Motor Coil Cross Section Your miniature motion challenges are unique and your ideas for meeting those challenges are equally unique. Brush DC Spotlight on Innovation Brush DC Motor Basics Brush DC Working Principles From medical to aerospace or security and access, Portescap’s brush DC motion solutions are moving life forward worldwide in critical applications. The following Brush DC section features our high efficiency and high power density with low inertia coreless brush DC motor technology. How to select your Brush DC motor 57 Brush DC Specifications Where to apply Brush DC motors Brush DC motors at Work
Open the catalog to page 1
Long life Patented Commutation Sysyem Virtually Eliminates Brush Maintenance Models Available from 8mm to 35mm Diameter Select Either Sleeve or Ball Bearings Ironless Rotor Coil Enables High Acceleration High Efficiency Design Ideal for Battery-Fed Applications Optional Gearboxes and Magnetic or Optical Encoders Are Easily Added Innovation & Performance Portescap’s brush DC coreless motors incorporate salient features like low moment of inertia, no cogging, low friction, very compact commutation which in turn results in high acceleration, high efficiency, very low joule losses and higher continuous...
Open the catalog to page 2
INNOVATION Innovation is a passion at Portescap. It defines your success, and defines our future. We help you get the right products to market faster, through rapid prototyping and collaborative engineering. With experienced R&D and application engineering teams in North America, Europe, and Asia, Portescap is prepared to create high-quality precision motors, in a variety of configurations and frame sizes for use in diverse environments. Demanding application? Portescap is up for the challenge. Take our latest innovation Athlonix in high power density motors. Ultra-compact, and designed for lower...
Open the catalog to page 3
Brush DC Motor Basics Construction of Portescap motors with iron less rotor DC motors All DC motors, including the ironless rotor motors, are composed of three principle sub assemblies: 1. Stator 2. Brush Holder Endcap 3. Rotor Stator Tube Self Supporting High Packing Density Rotor Coil Sleeve or Ball Bearing Collector High Efficiency High Strength Rare Earth Magnet Cable Clamp Metallic Alloy Brush Commutation System 1. The stator The stator consists of the central, cylindrical permanent magnet, the core which supports the bearings, and the steel tube which completes the magnetic circuit. All...
Open the catalog to page 4
B — A method which avoids these coil heads uses an armature wire that is covered with an outer layer of plastic for adhesion, and is wound on a mobile lozenge-shaped support. Later, the support is removed, and a flat armature package is obtained, which is then formed into a cylindrical shape (Figure 1). The difficulty with this method lies in achieving a completely uniform cylinder. This is necessary for minimum ripple of the created torque, and for a minimum imbalance of the rotor. Figure 1 - Continuous winding on mobile support 2a 3 b) armature as flat package c) forming of armature in cylindrical...
Open the catalog to page 5
Features of Ironless Rotor DC Motors The rotor of a conventional iron core DC motor is made of copper wire which is wound around the poles of its iron core. Designing the rotor in this manner has the following results: • A large inertia due to the iron mass which impedes rapid starts and stops • A cogging effect and rotor preferential positions caused by the attraction of the iron poles to the permanent magnet. • A considerable coil inductance producing arcing during commutation. This arcing is responsible on the one hand for an electrical noise, and on the other hand for the severe electro—erosion...
Open the catalog to page 6
Brush DC Working Principles The electromechanical properties of motors with an ironless rotor : Graphic express U = M x R + k x ω (4) characteristic: with ironless rotors can be described by means of the following equations: n By calculating the constant k and k from the n 1. The power supply voltage U is equal to dimensions of the motor, the number of turns U the sum of the voltage drop produced by the per winding, the number of windings, the current I in the ohmic resistance R of the diameter of the rotor and the magnetic field rotor winding, and the voltage U induced in in the air gap, we...
Open the catalog to page 7
Brush DC Working Principles through the effect of the rotor current, particularly in the event of slow or repeated starting. The torque M produced by the starting-current I is obtained as follows: M = I x k - M = (I - I )k (9) d required for obtaining a speed of rotation n for a given load torque M (angular velocity ω = n x 2π/60). By introducing equation (10) into (6) we obtain: U = M + I R + k x ω (13) k L By applying equation (1), we can calculate the angular velocity ω produced under a voltage U with a load torque M . We first determine the current required for obtaining the torque M=M +M:...
Open the catalog to page 8
How to select your Coreless motor PRODUCT RANGE CHART FRAME SIZE Max Continuous Torque Motor Regulation R/K Rotor Inertia Rotor Inertia FRAME SIZE Rotor Inertia Rotor Inertia Motor Designation 22 Motor diameter (in mm) Bearing type: blank = with sleeve bearings 2R = with front and rear ball bearings Coil type: nb of layer wire size type connexion Commutation size & type/ magnet type: Alnico/ Precious Metal = 18, 28, 48, 58 Alnico/ Graphite & Copper = 12 Motor generation/ length: L, C = old generation (C: short, L: long), Alnico Magnet S, N, V = middle generation (S: short, N: normal, V: very...
Open the catalog to page 9
Explanation of Specifications MOTOR PART NUMBER MEASURING VOLTAGE Is the DC voltage on the motor terminals and is the reference at which all the data is measured This is the the speed at which motor turns when the measuring voltage is applied with out any load STALL TORQUE Minimum torque required to stall the motor or stop the motor shaft from rotating at measuring voltage AVERAGE NO LOAD CURRENT The current drawn by the motor at no load while operating at the measured voltage TYPICAL STARTING VOLTAGE The minimum voltage at which the motor shaft would start rotating at no load MAX RECOMMENDED...
Open the catalog to page 10All Portescap S.A. catalogs and technical brochures
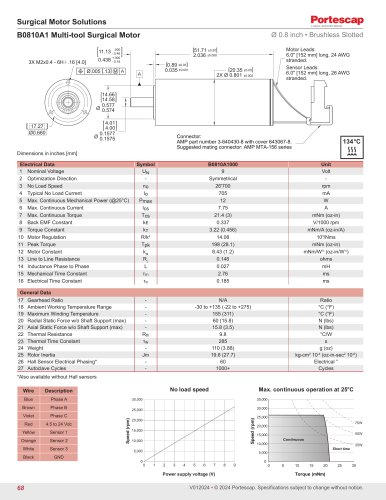 specifications_b0810a1
1 Page
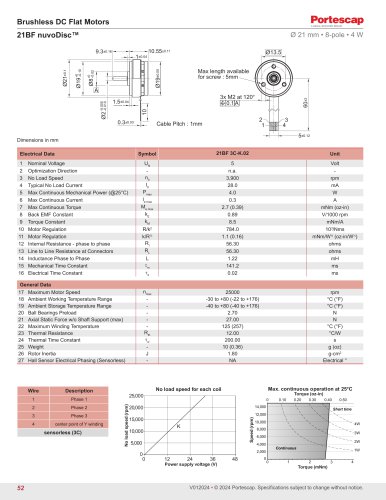 specifications_21bf
1 Page
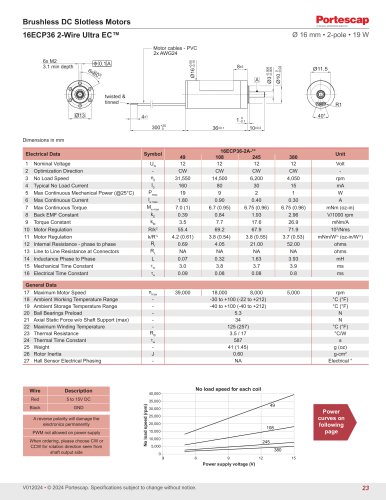
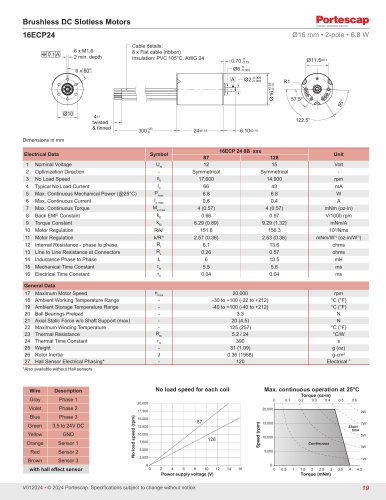 specifications_16ecp24
1 Page
Archived catalogs
 Portescap Medical Brochure
20 Pages
 Industrial Power Tools
8 Pages
 22ECT 35 - 48
2 Pages
 SMS ENCODER
1 Page
 35ecs
4 Pages
 White Paper Tattoo Machines
5 Pages
 Portescap Product Catalog
214 Pages
 BRUSHLESS DC MOTORS
7 Pages
 CANSTACK stepper motors
7 Pages
 TurboDisc™ Stepper Motors
8 Pages
 B16C-0-24
1 Page
 16ECP24
1 Page
 Ultra EC Brushless Motors
8 Pages
 16ECP Ultra EC
2 Pages
 Miniature Motors
16 Pages


- Electromotor
- Synchronous motor
- Actuator
- Multipole motor
- Electric gearmotor
- Angular encoder
- Linear actuator
- Asynchronous motor
- Planetary gearbox
- Electric actuator
- Coaxial gearhead
- Incremental encoder
- EC motor
- Electromotor for industrial applications
- Three-phase motor
- Precision gearhead
- 24 V motor
- Incremental rotary encoder
- Compact gearhead