
- Catalogs
- NEOTON MOTOR
- BLAR-09030-MH_datasheet.pdf

- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
BLAR-09030-MH_datasheet.pdf
BLAR-09030-MH_datasheet.pdf
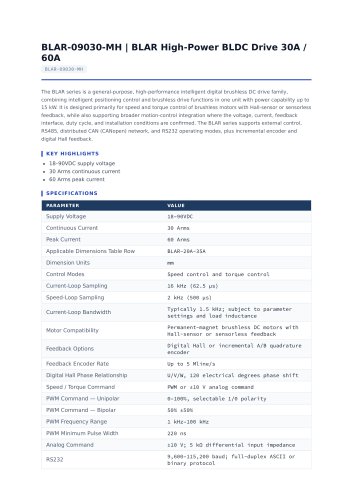
- Supply Voltage: 18–90VDC
- Continuous Current: 30 Arms
- Peak Current: 60 Arms
- Control Modes: Speed and torque control
- Feedback Options: Digital Hall or incremental A/B quadrature encoder
- Communication: RS232, RS485, CAN (optional)
- Protection Functions: Overvoltage, overcurrent, undervoltage, overload, overtemperature, encoder fault, I²t, and output short circuit
- J1: Motor & Main Power
- J2: Motor Feedback
- J3: Control & Analog Command
- J4/J5: Field Communication
- J6: RS232 Debug
- J7: Auxiliary Power
Catalog excerpts
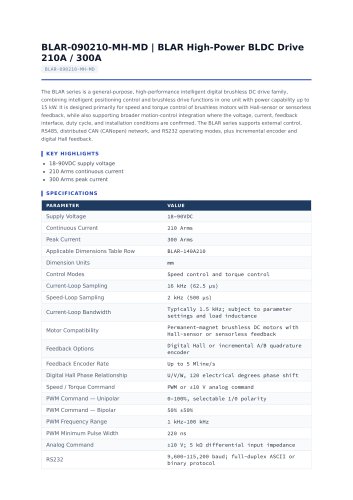
The BLAR series is a general-purpose, high-performance intelligent digital brushless DC drive family, combining intelligent positioning control and brushless drive functions in one unit with power capability up to 15 kW. It is designed primarily for speed and torque control of brushless motors with Hall-sensor or sensorless feedback, while also supporting broader motion-control integration where the voltage, current, feedback interface, duty cycle, and installation conditions are confirmed. The BLAR series supports external control, RS485, distributed CAN (CANopen) network, and RS232 operating modes, plus incremental encoder and digital Hall feedback. • 30 Arms continuous current • 60 Arms peak current | SPECIFICATIONS Supply Voltage Continuous Current Peak Current Applicable Dimensions Table Row Dimension Units Control Modes Current-Loop Sampling Speed-Loop Sampling Speed control and torque control 16 kHz (62.5 ps) Current-Loop Bandwidth Motor Compatibility Feedback Options Feedback Encoder Rate Digital Hall Phase Relationship Speed / Torque Command PWM Command — Unipolar PWM Command — Bipolar PWM Frequency Range PWM Minimum Pulse Width Analog Command Typically 1.5 kHz; subject to parameter settings and load inductance Permanent-magnet brushless DC motors with Hall-sensor or sensorless feedback Digital Hall or incremental A/B quadrature encoder U/V/W, 120 electrical degrees phase shift PWM or ±10 V analog command 0-10055, selectable 1/0 polarity 5055 ±5055 1 kHz-100 kHz 220 ns ±10 V; 5 kfi differential input impedance 9,600-115,200 baud; full-duplex ASCII or binary protocol
Open the catalog to page 1
20 kbit/s–1 Mbit/s; CANopen DS-301 V4.02 and DS-402 device drive / motion control Status indication and CAN network indication Digital Inputs Configurable Input Functions Hardware enable, external reset, forward/reverse limit, PWM synchronization, run/stop, and high-speed pulse input Digital Outputs 2 ports; NPN, active-low; max. 300 mADC / 30 VDC Configurable Output Functions Fault signal, brake control, PWM synchronization signal, and user-defined event Protection Functions Overvoltage, overcurrent, undervoltage, overload, overtemperature, encoder fault, I²t, and output short circuit Shared...
Open the catalog to page 2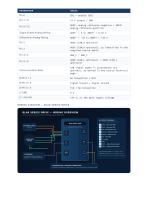
AREF− analog reference negative / AREF+ analog reference positive Single-Ended Analog Wiring Differential Analog Wiring 485A (CAN_H optional), as identified in the supplied source table GND_C / GND_C 485B (CAN_L optional) / 485B (CAN_L optional) Communication Note CAN signal names in parentheses are optional, as marked in the source technical page. Signal Ground / Signal Ground +24 V, or the main supply voltage WIRING DIAGRAM — BLAR SERIES DRIVE BLAR SERIES DRIVE — WIRING OVERVIEW Common technical connection reference for BLAR high-power brushless drives J3 CONTROL TERMINALS Terminal number and...
Open the catalog to page 3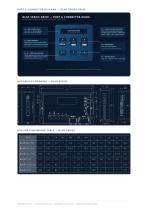
PORT & CONNECTOR DIAGRAM — BLAR SERIES DRIVE Common connector locations and functions for BLAR high-power brushless drives J1 — Motor & Main Power Pin 1-3: U / V / W motor phases Pin 4: 0 V • Pin 5: DC 20-90 V BLAR SERIES DRIVE Front / connector-side reference J3 — Control & Analog Command OUT2 / OUT1: brake and fault outputs IN1-IN4: enable, direction and PWM pulse AREF- / AREF+: ±10 V analog reference Digital Hall or incremental A/B encoder Optional NTC or temperature-switch input Specify feedback / temperature option when ordering. J6 — RS232 Debug RxD / TxD / signal ground J4 / J5 — Field...
Open the catalog to page 4All NEOTON MOTOR catalogs and technical brochures
 BLAR-090140-MH_datasheet.pdf
4 Pages
 BLAR-090100-MH_datasheet.pdf
4 Pages
 BLAR-09070-MH_datasheet.pdf
4 Pages
 BLAR-09050-MH_datasheet.pdf
4 Pages
 ACSDP200E_datasheet.pdf
4 Pages
 ACSDP100E-75_datasheet.pdf
4 Pages
 ACSDP100E-40_datasheet.pdf
4 Pages
 ACSDP200H_datasheet.pdf
5 Pages
 ACSDP100H-75_datasheet.pdf
5 Pages
 ACSDP100S-75_datasheet.pdf
5 Pages
 ACSDP100H-40_datasheet.pdf
5 Pages
 ACSDP100S-40_datasheet.pdf
5 Pages
 BLD2408_datasheet.pdf
2 Pages
 BLD510-LS_datasheet.pdf
2 Pages
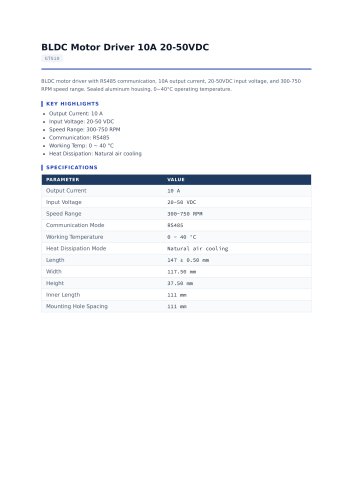 GT510_datasheet.pdf
2 Pages
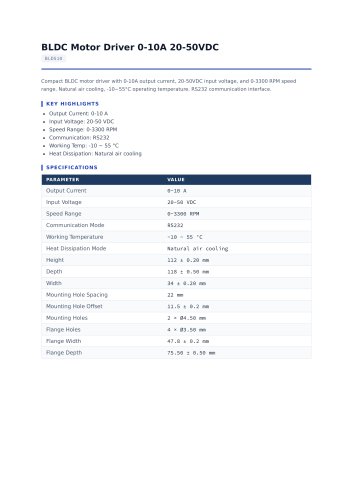 BLD510_datasheet.pdf
2 Pages
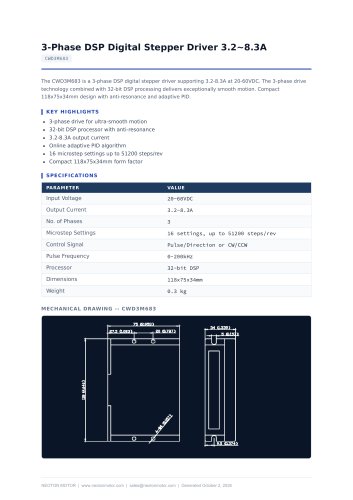 CWD3M683_datasheet.pdf
1 Page
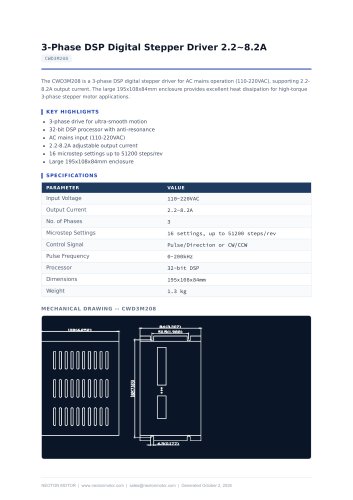 CWD3M208_datasheet.pdf
1 Page
 CWD2208_datasheet.pdf
1 Page
 CWD1182_datasheet.pdf
1 Page
 CWD882_datasheet.pdf
1 Page
 CWD3M860_datasheet.pdf
2 Pages
 CWD860H_datasheet.pdf
2 Pages
 CWD860_datasheet.pdf
2 Pages
 CWD856_datasheet.pdf
2 Pages
 CWD556_datasheet.pdf
1 Page
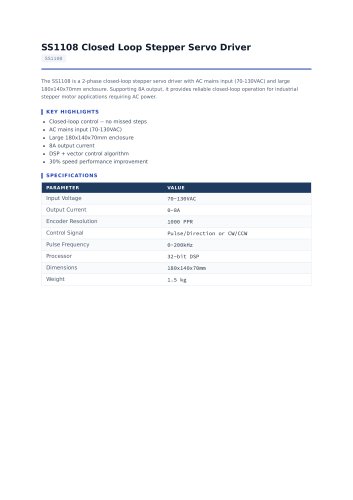 SS1108_datasheet.pdf
2 Pages
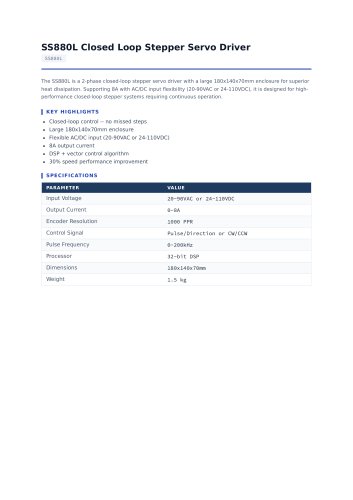 SS880L_datasheet.pdf
2 Pages
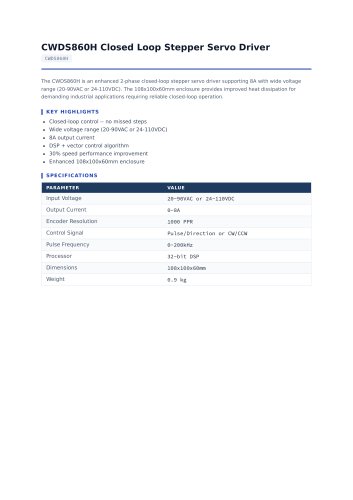 CWDS860H_datasheet.pdf
2 Pages
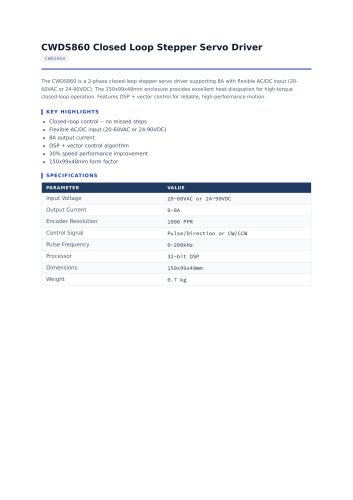 CWDS860_datasheet.pdf
2 Pages
 SS1106_datasheet.pdf
2 Pages
 SS2206_datasheet.pdf
2 Pages
 CWDS660_datasheet.pdf
1 Page
 CWDS556_datasheet.pdf
1 Page
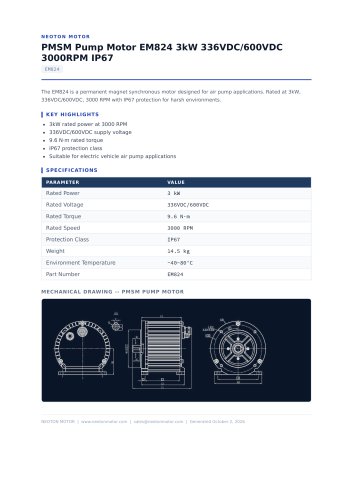 EM824_datasheet.pdf
1 Page
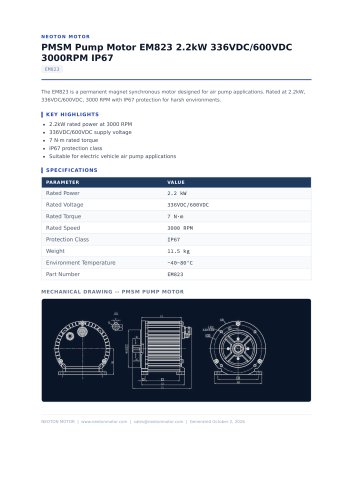 EM823_datasheet.pdf
1 Page
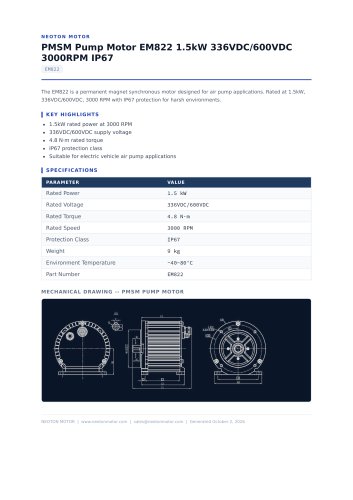 EM822_datasheet.pdf
1 Page
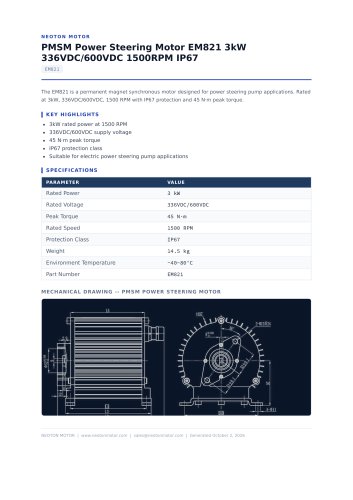 EM821_datasheet.pdf
1 Page
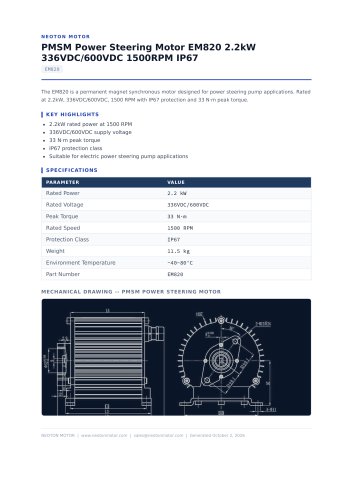 EM820_datasheet.pdf
1 Page
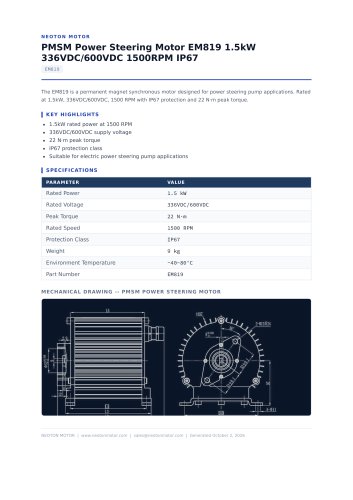 EM819_datasheet.pdf
1 Page
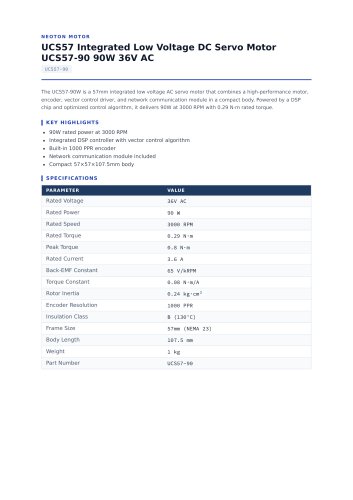 UCS57-90_datasheet.pdf
2 Pages
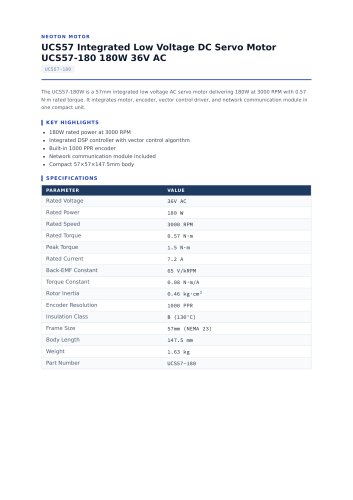 UCS57-180_datasheet.pdf
2 Pages
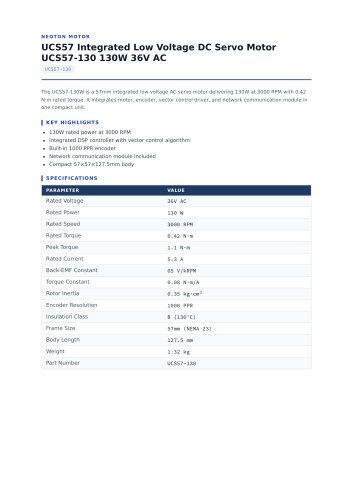 UCS57-130_datasheet.pdf
2 Pages
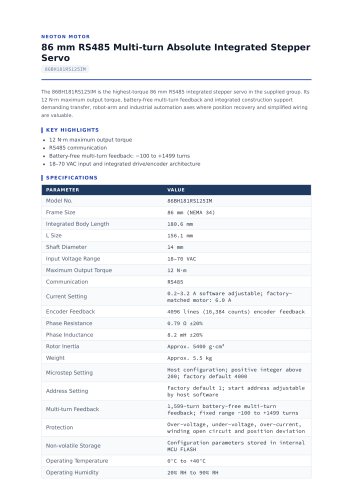 86BH181RS125IM_datasheet.pdf
2 Pages
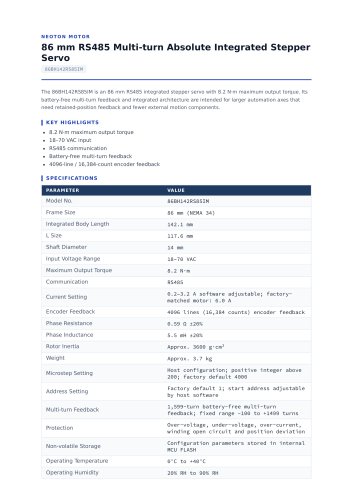 86BH142RS85IM_datasheet.pdf
2 Pages
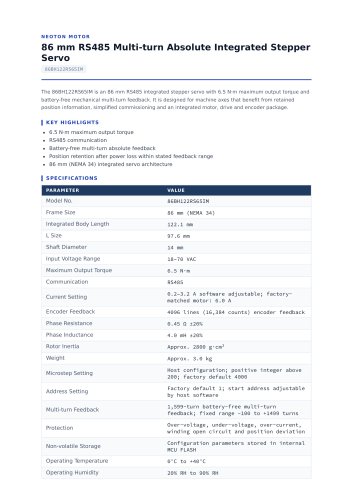 86BH122RS65IM_datasheet.pdf
2 Pages
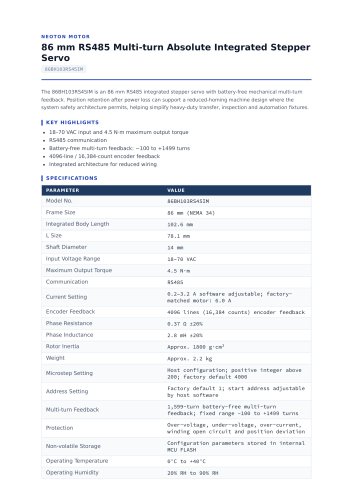 86BH103RS45IM_datasheet.pdf
2 Pages
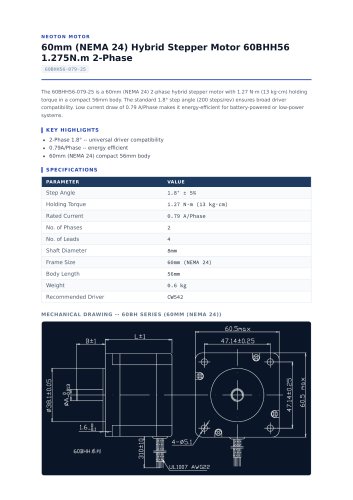 60BHH56-079-25_datasheet.pdf
2 Pages
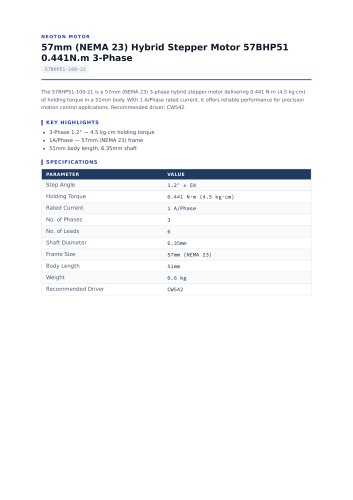 57BHP51-100-21_datasheet.pdf
4 Pages
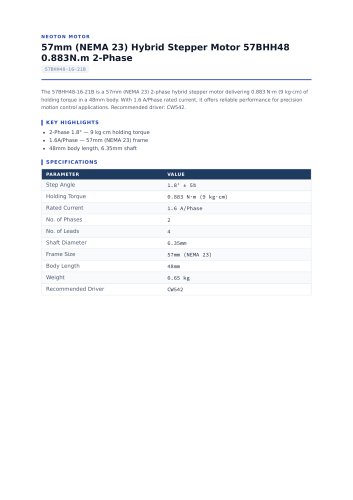 57BHH48-16-21B_datasheet.pdf
4 Pages
 57BH96PS20IC_datasheet.pdf
2 Pages
 57BH83EC12IE_datasheet.pdf
2 Pages
 57BH80CA12IM_datasheet.pdf
2 Pages
 57BH75PS12IC_datasheet.pdf
2 Pages
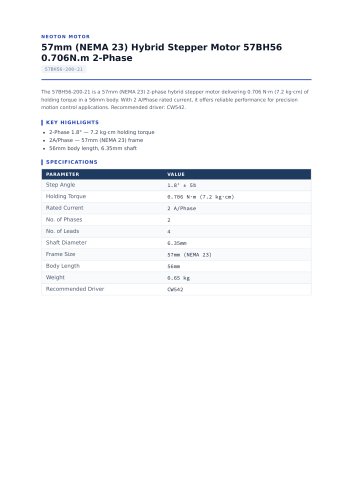 57BH56-200-21_datasheet.pdf
4 Pages
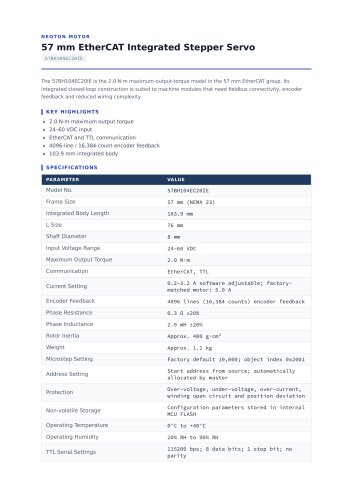 57BH104EC20IE_datasheet.pdf
2 Pages
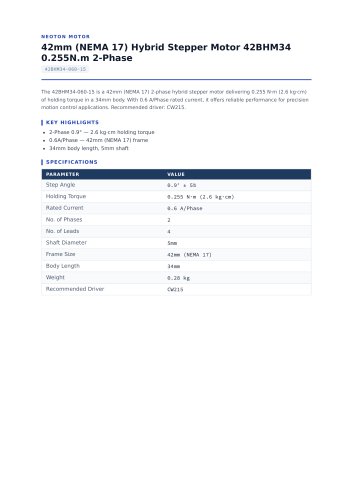 42BHM34-060-15_datasheet.pdf
4 Pages
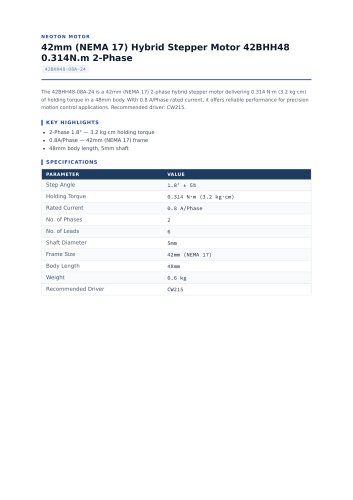 42BHH48-08A-24_datasheet.pdf
4 Pages
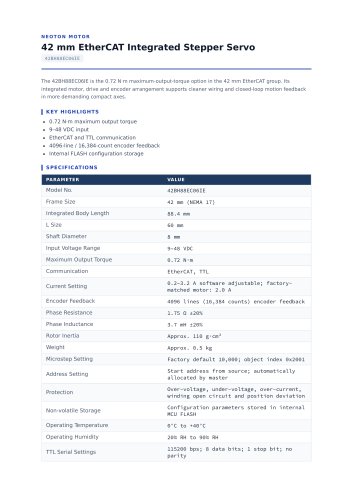 42BH88EC06IE_datasheet.pdf
2 Pages
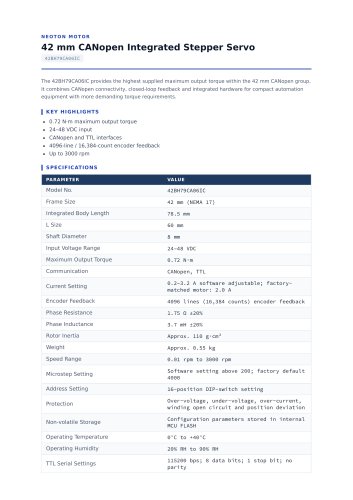 42BH79CA06IC_datasheet.pdf
2 Pages
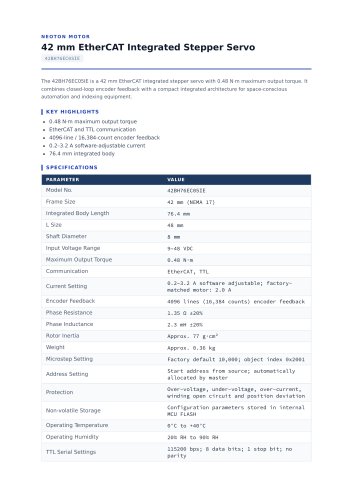 42BH76EC05IE_datasheet.pdf
2 Pages
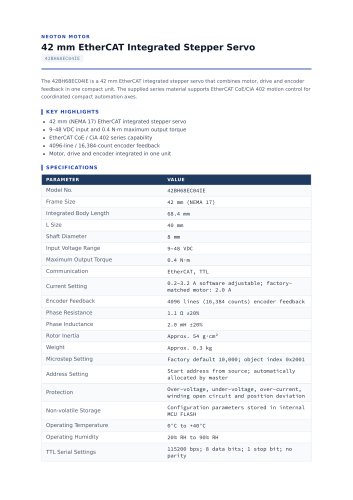 42BH68EC04IE_datasheet.pdf
2 Pages
 42BH67CA05IC_datasheet.pdf
2 Pages
 42BH59CA04IC_datasheet.pdf
2 Pages
 39BHM26-02A-17_datasheet.pdf
3 Pages
 39BH44-031A-24_datasheet.pdf
3 Pages
 39BH34-02-11_datasheet.pdf
3 Pages
 39BH25-048A-24_datasheet.pdf
3 Pages
 35BH20-020-16_datasheet.pdf
3 Pages
 35BH26-025-20B_datasheet.pdf
3 Pages
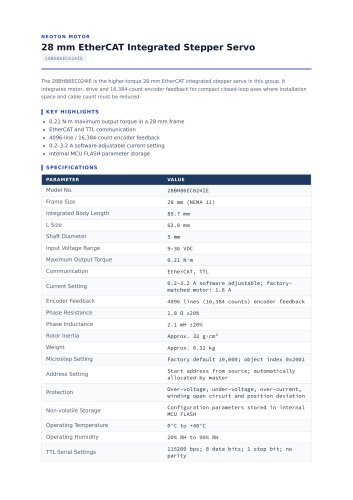 28BH86EC024IE_datasheet.pdf
2 Pages
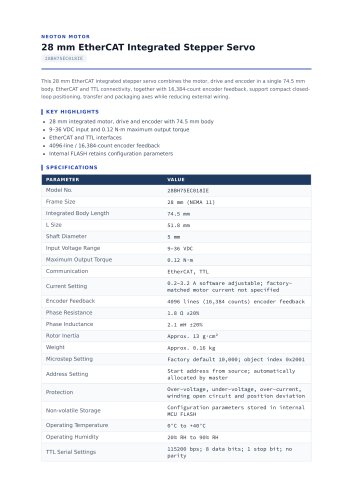 28BH75EC018IE_datasheet.pdf
2 Pages
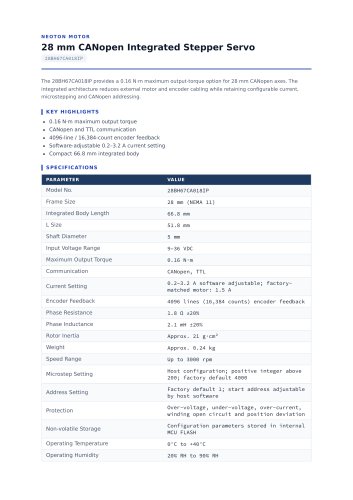 28BH67CA018IP_datasheet.pdf
2 Pages
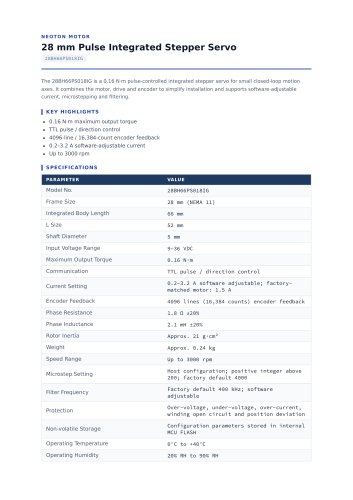 28BH66PS018IG_datasheet.pdf
2 Pages
 28BH55EC008IE_datasheet.pdf
2 Pages
 28BH51-100B-20_datasheet.pdf
2 Pages
 28BH47CA008IP_datasheet.pdf
2 Pages
 28BH46PS008IG_datasheet.pdf
2 Pages
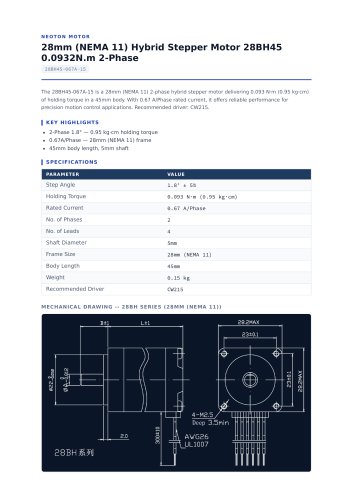 28BH45-067A-15_datasheet.pdf
2 Pages
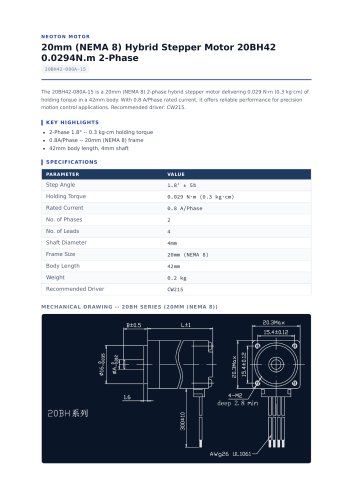 20BH42-080A-15_datasheet.pdf
2 Pages
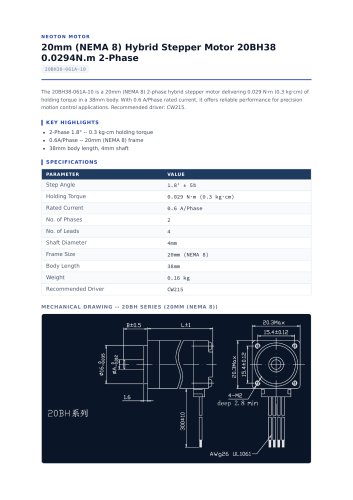 20BH38-061A-10_datasheet.pdf
2 Pages
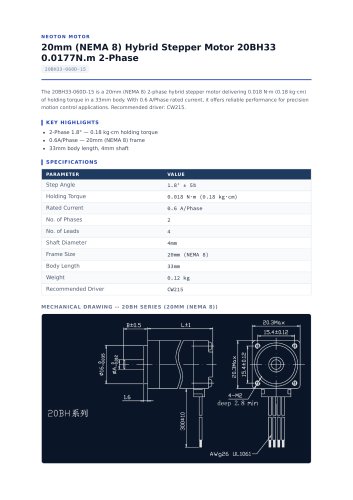 20BH33-060D-15_datasheet.pdf
2 Pages
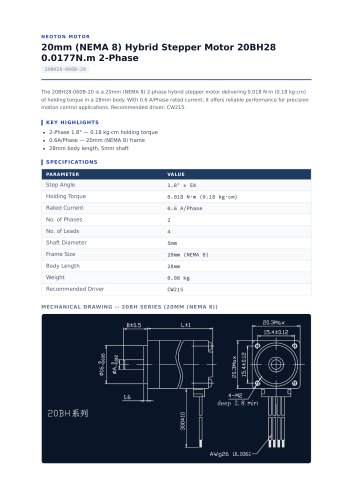 20BH28-060B-20_datasheet.pdf
2 Pages
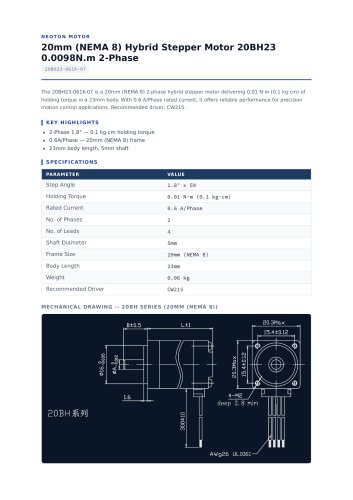 20BH23-061K-07_datasheet.pdf
2 Pages
- Electromotor
- Synchronous motor
- Alternating current motor
- Multipole motor
- Electromotor for industrial applications
- Three-phase motor
- 24 V motor
- Servo-motor
- 4-pole motor
- Compact electromotor
- High-efficiency electromotor
- 12 V motor
- Servo-amplifier
- Pump motor
- Stepper motor
- Permanent magnet motor
- High-performance servo motor
- AC servo-motor