
- Catalogs
- M&D (Motor and Drive)
- Smart Roller Spec for Low Speed Application-V3.83
- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
Smart Roller Spec for Low Speed Application-V3.83
Smart Roller Spec for Low Speed Application-V3.83
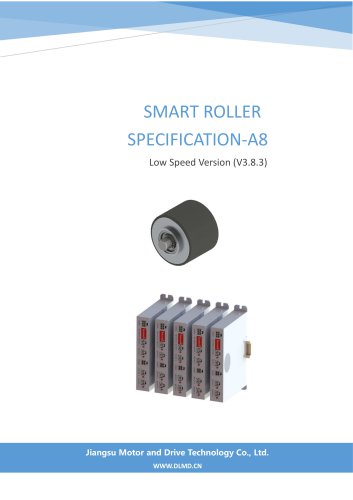
The document provides detailed specifications for the GTB Series Servo, specifically the low-speed version of the Smart Roller (V3.8.3) by Jiangsu Motor and Drive Technology Co., Ltd. It includes information on motor and driver specifications, control modes, communication protocols, quality control, warranty, and packaging.
- Type: Permanent magnetic brushless motor without hall sensors.
- Rotor: Outer rotor with a 70mm diameter and 2mm gum thickness.
- Voltage: Rated at 48V DC with a tolerance of +/- 10%.
- Power: Rated power of 50W with a peak torque of 2 N.m.
- Speed Range: 150-850 RPM in RS485 mode and 150-800 RPM in IO control mode.
- Insulation Class: F.
- Type: Sensor-less BLDC driver with a supply voltage of 48V DC.
- Control Modes: RS485 and IO control modes available.
- Environment: Operates between -25°C to 60°C with humidity below 85%.
- Functionality: Can control up to four roller motors synchronously.
- Control Signals: Defined through RS485 protocol or IO ports with priority given to IO control.
- DIP Switch: Used for setting speed and direction in both IO and RS485 modes.
- Communication Protocol: RS485 with a maximum of 31 slaves, using a 38400 baud rate.
Each motor undergoes a series of tests including insulation performance and motor performance tests using the Back EMF method. Drivers are tested for logic verification and load capacity.
The product comes with a twelve-month warranty. Packaging involves individual cartons for rollers and wooden boxes for transportation, as per contractual agreements.
Catalog excerpts
SMART ROLLER SPECIFICATION-A8 Low Speed Version (V3.8.3) Jiangsu Motor and Drive Technology Co., Ltd. WWW.DLMD.CN
Open the catalog to page 1
General Specifications of GTB Series Servo Revision history Version Jiangsu Motor and Drive Technology Co., Ltd. No. 51 Weihai Road, Taicang, Suzhou City, Jiangsu Province, China Jiangsu Motor and Drive Technology Co., Ltd.
Open the catalog to page 2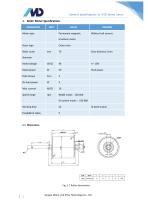
General Specifications of GTB Series Servo 1. Roller Motor Specifications PARAMETER Jiangsu Motor and Drive Technology Co., Ltd.
Open the catalog to page 3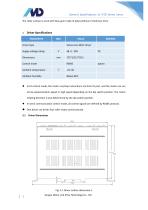
General Specifications of GTB Series Servo The roller surface is stuck with blue gum made of polyurethane in thickness 2mm. 2. Driver Specifications PARAMETER • In IO control mode, the motor run/stop instructions are from IO port, and the motor can run at low speed,medium speed or high speed depending on the dip switch position. The motor rotating direction is also determined by the dip switch position. • In serial communication control mode, all control signals are defined by RS485 protocol. • One driver can driver four roller motor synchronously.
Open the catalog to page 4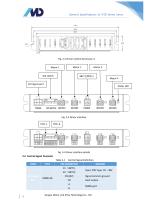
General Specifications of GTB Series Servo Fig. 2-2 Driver outline dimension-2 Motor 2 Ctrl Signal port Fig. 3-4 Driver interface details 2.2. Control Signal Termianls Table 2-1 PORT Control Signal Definition Ctrl Signal Port REMARK Input, PNP type, 18~48V Signal common ground Fault output RS485 port
Open the catalog to page 5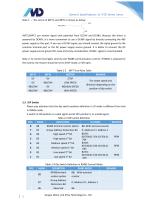
General Specifications of GTB Series Servo Note 1 : The circuit of INPT1 and INPT2 is shown as below: INPT1/INPT2 can receive signal with potential from DC24V and DC48V. Because the driver is powered by DC48V, it is more convenient to use a DC48V signal by directly connecting the 48V power supply to this port. If you use a DC24V signal, you should connect the signal ground to the common terminal port or the DC power supply source ground. It is better to connect the DC power supply source ground for noise immunity consideration. DC48V- signal is recommended. Note 2: IO control has higher priority...
Open the catalog to page 6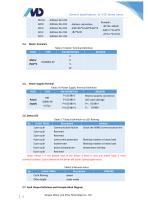
General Specifications of GTB Series Servo Address calculation: Table 2-5 Motor Terminal Definition Jiangsu Motor and Drive Technology Co., Ltd.
Open the catalog to page 7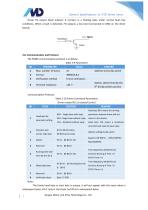
General Specifications of GTB Series Servo Driver FO output (fault output): It remains in a floating state under normal fault-free conditions. When a fault is detected, FO outputs a low level (connected to GND on the driver board). 2.8. Communication and Protocol The RS485 communication protocol is as below: The frame head byte or start byte is unique, it will not appear with the same value in subsequent bytes. B7=1 only in start byte, but B7=0 in subsequent bytes. Jiangsu Motor and Drive Technology Co., Ltd.
Open the catalog to page 8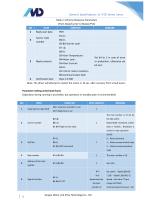
General Specifications of GTB Series Servo Table 2-11Frame Response Parameters (From Slave/Carrier to Master/PLC) Jiangsu Motor and Drive Technology Co., Ltd.
Open the catalog to page 9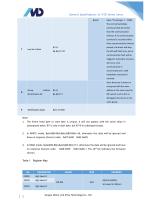
General Specifications of GTB Series Servo Byte4) value *1ms(range: 1 - 5000) The normal handshake command shall be shorter than the communication timeout. If no communication command is received within three communication timeout periods, the driver will stop, the LED will flash once, and a communication fault will be triggered. Automatic recovery will occur once communication is reconnected and a valid handshake command is received. Group address Since there are 5 motors in one group with the same address in the same row, the DIP switch is set to 0/1 to distinguish the drivers in the same group....
Open the catalog to page 10
General Specifications of GTB Series Servo 3(03H) B1=3 Error motor numbers, The communication timeout time is 500rpm (Communication timeout fault: no shutdown, but FO fault output is active. Factory default: shutdown if no 0: Forward rotation (factory default direction) 1: Reverse rotation (for cases where the direction is installed inversely) Set bit to 1 in case of error or protection, otherwise set bit to 0. 3. Quality Control and Surveillance Every set of motor dispatched from factory has a tracking inspection table, which can be traced back to the original size of each part. The insulation...
Open the catalog to page 11
General Specifications of GTB Series Servo motors must pass the test before being dispatched. All drivers must pass the logic verification and the actual load test and aging test as well before delivery. 4.Warranty Period The warranty period is twelve months. Any damage due to inadequate installation or abnormal use will be charged additional maintenance service/repair fee. 5. Packaging and Transportation Every single roller is packed with a dedicated carton, and a number of cartons are packed in a wooden box for transportation. The drivers are packed with carton. The transportation way and the...
Open the catalog to page 12All M&D (Motor and Drive) catalogs and technical brochures
 GTB Series Servo Rollers
15 Pages
 SMART ROLLER CATALOGUE
12 Pages
 48V Servo Drive V1.0_EN
16 Pages
 F Series of ECI Motor
23 Pages
 T Series of ECI Motor
28 Pages
 T Series of EC Motor
17 Pages
Archived catalogs
- Electromotor
- Synchronous motor
- Electromotor for industrial applications
- IP55 motor
- High-efficiency electromotor
- Permanent magnet motor
- Pump motor
- Robotic motor
- Conveyor motor
- IEC motor
- Blower motor
- Fan motor
- Machine tool motor
- Linear motor
- Variable-speed motor
- Motor driver
- High-precision motor
- Compressor motor
- Energy-saving motor