


Torque-Motors t-Rex

Torque-Motors t-Rex
The document introduces the Torque-Motors t-Rex series, emphasizing the company's long-standing history of innovation in customized drive solutions. These motors are manufactured in the Black Forest and are renowned for their high performance and reliability, suitable for applications such as office workstations, shading systems, and building technology.
The t-Rex BLDC motors come in two sizes (3200: Ø44mm and 3206: Ø65mm) with two lengths each. They offer a torque range from 0.2 Nm to 8 Nm and a drive speed up to 6000 rpm, providing three times the torque density of similar-sized products, ideal for direct drive applications.
- High torque density and energy efficiency.
- Low maintenance due to a gearbox-less design.
- Flexible voltage range (24 V to 48 V) for battery operation.
- Customizable motor design for specific needs.
- Compatibility with various gearboxes, encoders, brakes, and controllers.
Detailed specifications for the t-Rex 3200 and 3206 models include:
- Rated voltage, current, torque, and speed.
- Efficiency, idle speed, and stall torque.
- Terminal resistance and inductance.
- Rotor inertia and number of poles.
- Interconnection of coils and direction of rotation.
The t-Rex motors are ideal for high-performance applications in compact spaces, offering:
- High overload capability and dynamics.
- Longer service life and maintenance-free operation.
- Reduced noise and operating costs.
The Torque-Motors t-Rex series offers versatile and efficient solutions for various industrial applications, focusing on innovation, customization, and reliability.
This document provides technical specifications and details for various t-Rex BLDC motor models, focusing on design, performance, and operational parameters. The motors are designed for high efficiency and performance, with customization options to meet specific operating points.
- Motor Models: t-Rex 3200 and t-Rex 3206, available in configurations focusing on speed or torque.
- Rated Voltage: Options for 24 VDC, 36 VDC, and 48 VDC.
- Rated Current and Torque: Varies by model, with currents from 4.0 A to 7.3 A and torques from 0.2 Nm to 1.9 Nm.
- Efficiency: Maximum efficiency ranges from 74% to 84% depending on the model and configuration.
- Motor Parameters: Includes terminal resistance, inductance, rotor inertia, and number of poles.
- Interconnection: Motors are interconnected in a star configuration with two coils per phase.
- Direction of Rotation: Bidirectional.
- Digital Hall Sensors: Used for rotor position detection, with a differential output conforming to RS422 standards.
- Signal Structure: Hall sensors have a 120° phase shift, with signal frequency seven times higher than the speed due to the 14-pole design.
- Motors can be designed and manufactured to specified operating points, with special winding available upon request.
- Options for hollow shaft design to allow cable routing through the motor.
- Various mechanical dimensions and mounting options are provided, including pin strip configurations and feather key specifications.
- Motors are suitable for direct drive or generator applications, particularly in gearless setups.
- High overload resistance and performance density make them three times stronger than comparable motors.
Ketterer motors are used worldwide, with agencies and subsidiaries in multiple countries including Australia, Germany, USA, and more.
Catalog excerpts
Torque-Motors t-Rex
Open the catalog to page 1
WE GET IDEAS MOVING The spirit of innovation and a sense of ideas beyond the familiar has made us into a pioneering company over more than 185 years. For a quarter of a century, we have been offering customized drive solutions for office and workplace workstations, as well as for shading systems and building technology. Ergonomie Professional Industrial Drives Over 185 years’ experience Through our tradition of innovation, we have succeeded in establishing ourselves as a specialist and problem-solver in numerous areas. Building Drives Ergonomie Home & Care More than 60 standard solutions for four...
Open the catalog to page 2
THE RIGHT PRODUCT FOR EACH APPLICATION Bevel gears Page 04 Page 06 Page 08 Page 10 Page 12 Page 14 Page 16
Open the catalog to page 3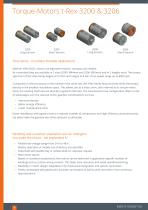
One Family – Countless Possible Applications Ketterer t-Rex BLDC motors are high-performance, compact and reliable. As a standard they are available in 2 sizes (3200: Ø44mm and 3206: Ø65mm) and in 2 lengths each. The torque spectrum of the t-Rex family begins at 0.2 Nm and ranges to 8 Nm. Drive speed range up to 6000 rpm. Compared to other products on the market in the same size, the t-Rex family features three times the torque density in the smallest installation space. This allows use as a direct drive, also referred to as torque motor. Here, the rotating machines are directly coupled to the...
Open the catalog to page 4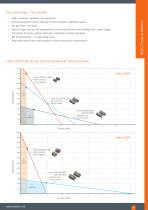
Our technology - Your benefit High overload capability and dynamics Enormous performance density in the smallest installation space No gearbox – no wear Much longer service life compared to conventional drive technology with a gear stage Increased machine uptime through maintenance-free operation No maintenance – no operating costs Reduced noise due to elimination of the transmission mechanism t-Rex 3200/3206 family: Variant Overview & Selection Guide 5500 t-Rex 3200.00-3000 Short Version Focus Speed t-Rex 3200.00-0004 Long Version Focus speed t-Rex 3200.00-0005 3200.00-0006 Long Version Focus...
Open the catalog to page 5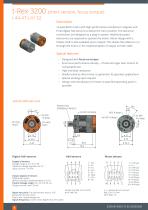
t-Rex 3200 (short version, focus torque) I-44-47-L41 S2 Description 14-pole BLDC motor with high-performance neodymium magnets and three digital Hall sensors to detect the rotor position. The electrical connections are designed as a plug-in system. Additional power electronics are required to operate the motor. Motor design with a hollow shaft is also available upon request. This allows the cables to run through the motor or the implementation of output on both sides. Designed with focus on torque Enormous performance density – 3 times stronger than motors of comparable size High overload resistance...
Open the catalog to page 6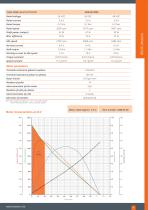
Rated current Rated torque Rated speed Shaft power (output) Torque constant Speed constant Idle speed No-load current Stall torque Starting current at idle speed Rated voltage Motor parameters Terminal resistance (phase to phase) Terminal inductance (phase to phase) Rotor inertia Number of coils per phase Note: Max. ambient temperature = 40 °C, controller-specific At the nominal point (TU = 20°C), controller-specific Motor cable approx. 1.5 m
Open the catalog to page 7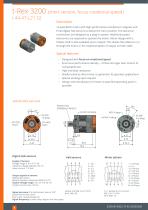
t-Rex 3200 (short version, focus rotational speed) I-44-47-L21 S2 Description 14-pole BLDC motor with high-performance neodymium magnets and three digital Hall sensors to detect the rotor position. The electrical connections are designed as a plug-in system. Additional power electronics are required to operate the motor. Motor design with a hollow shaft is also available upon request. This allows the cables to run through the motor or the implementation of output on both sides. Designed with focus on rotational speed Enormous performance density – 3 times stronger than motors of comparable size...
Open the catalog to page 8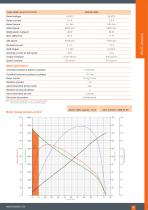
Rated voltage Rated current Rated torque Rated speed Idle speed No-load current Torque constant Speed constant Shaft power (output) Stall torque Starting current at idle speed Motor parameters Terminal resistance (phase to phase) Terminal inductance (phase to phase) Rotor inertia Number of coils per phase Note: Max. ambient temperature = 40 °C, controller-specific At the nominal point (TU = 20°C), controller-specific Motor cable approx. 1,5 m
Open the catalog to page 9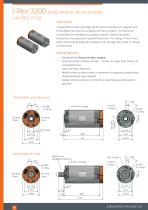
t-Rex 3200 (long version, focus torque) I-44-89-L41 S2 Description 14-pole BLDC motor with high-performance neodymium magnets and three digital Hall sensors to detect the rotor position. The electrical connections are designed as a plug-in system. Additional power electronics are required to operate the motor. The design of the motor with a hollow shaft allows the cables to run through the motor or output on both sides. Designed with focus on max. torque Enormous performance density – 3 times stronger than motors of comparable size High overload resistance Ideally suited as direct drive, or generator...
Open the catalog to page 10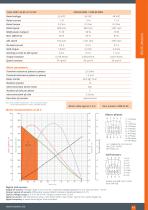
Rated voltage Rated current Rated torque Rated speed Idle speed No-load current Torque constant Speed constant Shaft power (output) Stall torque Starting current at idle speed Motor parameters Terminal resistance (phase to phase) Terminal inductance (phase to phase) Rotor inertia Number of coils per phase Note: Max. ambient temperature = 40 °C, controller-specific At the nominal point (TU = 20°C), controller-specific Motor characteristics at 24 V Motor phases 7 1= U-Phase 2= n.c. 3= U-Phase 4= U-Phase 5= V-Phase 6= V-Phase 7= W-Phase 8= V-Phase 9= W-Phase 10= W-Phase Digital Hall-sensors Supply...
Open the catalog to page 11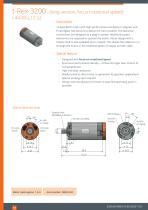
(long version, focus rotational speed) I-44-89-L12 S2 Description 14-pole BLDC motor with high-performance neodymium magnets and three digital Hall sensors to detect the rotor position. The electrical connections are designed as a plug-in system. Additional power electronics are required to operate the motor. Motor design with a hollow shaft is also available upon request. This allows the cables to run through the motor or the implementation of output on both sides. Designed with focus on rotational speed Enormous performance density – 3 times stronger than motors of comparable size High overload...
Open the catalog to page 12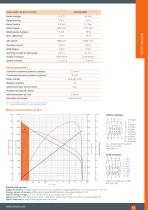
Rated voltage Rated current Rated torque Rated speed No-load current Stall torque Starting current at idle speed Torque constant Speed constant Idle speed Shaft power (output) Motor parameters Terminal resistance (phase to phase) Terminal inductance (phase to phase) Rotor inertia Number of coils per phase Note: Max. ambient temperature = 40 °C, controller-specific At the nominal point (TU = 20°C), controller-specific Motor characteristics at 24 V Motor phases 9 1= U-Phase 2= n.c. 3= U-Phase 4= U-Phase 5= V-Phase 6= V-Phase 7= W-Phase 8= V-Phase 10 8 6 4 2 9= W-Phase 10= W-Phase n.c.= please do...
Open the catalog to page 13All Ketterer catalogs and technical brochures
 Worm Gears
36 Pages
 Bevel Gears
28 Pages
 Lifting-Systems and Accessories
44 Pages
 Lifting Units and Accessories
54 Pages
 BLDC Technology
34 Pages
 Wheel hub motors
22 Pages
 Worm gearbox family Ket-Motion
30 Pages
 Ketterer Building Drives
11 Pages
 Ketterer Home & Care Solutions
11 Pages


