
- Catalogs
- Infranor Group
- BD1k(GB)2.1


BD1k(GB)2.1

BD1k(GB)2.1
This document provides a detailed manual for the SMT-BD1/k series digital servo amplifiers, which are used to drive AC brushless sinusoidal servo motors. It stresses the importance of thoroughly reading the manual before operation to ensure proper storage, commissioning, and maintenance.
Users are cautioned about potential physical damage from electrical parts even after power down, recommending a wait of at least 5 minutes before handling. Electrostatic discharge (ESD) precautions are also emphasized, advising storage in original packaging and handling with appropriate equipment.
The amplifiers comply with European standards, including CE approval, provided they are installed according to the manual's recommendations. They meet Electromagnetic Compatibility standards (EN 55011, CEI 801) and have been labeled with the "CE" mark since 1995.
The SMT-BD1/k operates at 310 VDC with an auxiliary supply voltage ranging from 200 V to 340 VDC. It features a PWM switching frequency of 10 KHz and supports various output currents depending on the fan type used. The amplifiers are equipped with a CANopen interface for motion command receipt and are programmable via RS232 or CANopen bus.
The document details the connectors for resolver, encoder, test, command, RS-232, and CAN, along with specifications for inputs and outputs. Logic inputs and outputs are specified for enabling/disabling, limit switches, and fault reset.
Parameters such as baud rate and addressing are adjustable. The commissioning process includes checking amplifier configuration, powering, and starting adjustments. Automatic functions like autophasing and autotuning facilitate easy setup.
Guidance is provided for addressing system faults, memory-stored faults, and operational problems. Maintenance should be conducted by skilled technicians.
The appendix includes hardware adjustments, resolver connections, and command logic adjustments, along with order codes and additional technical details.
The document outlines the specifications for the SMT-BD1/k amplifier, including compliance with EN 55011 for conducted and radiated disturbances, and EN 60204-1 for electrical standards. The insulator must withstand 1500 Vac for 1 minute, with a leakage current greater than 3 mA due to EMI filters. Temperature ranges are specified for storage (-20°C to +70°C) and operation (+5°C to +40°C), with a requirement to reduce rated currents by 3% per degree Celsius above 40°C. The maximum operational temperature is 50°C, and the altitude limit is 1000 meters.
The amplifier includes several protection mechanisms, such as overload protection (I²t), position following error, CAN input command error, resolver cable interruption, power stage failure, and overtemperature protections for both the amplifier and motor. Faults are stored in memory, except for undervoltage, and can be reset via the CAN bus, a fault RESET input, or by switching off the power supply.
Different fuse ratings are specified for various amplifier types, controlling the average DC current of the power and logic board supplies.
Guidelines for connecting rack power supplies, motors, CAN interfaces, and serial links are provided. The document emphasizes the importance of proper grounding and shielding according to CEI 801 and EN 55011 standards.
Parameter settings can be adjusted via the CANopen interface or serial link using VDSetup software. Baudrate and addressing configurations are detailed, with instructions on setting micro-switches for communication speed and amplifier addressing.
The commissioning process includes checking amplifier configuration, powering the amplifier, and starting and adjusting the amplifier. It highlights the importance of CANopen messages during operation and provides guidelines for adjusting the amplifier to a new motor.
The document outlines the procedures for setting up and operating the SMT-BD1/k amplifier with motors. It includes steps for uncoupling the motor, executing the "auto-phasing" procedure to define parameters like the number of pole pairs, motor phase, and resolver adjustment. The phase lead parameter is defined based on specific motor parameters, particularly useful for motors with low inductance running at high speeds.
The amplifier can be enabled in local mode using VDSetup software or in CAN mode via the CAN bus. It is disabled by default at power-up and remains disabled after a fault until manually enabled. The document details the adjustment of speed or position regulators and the auto-tuning procedure to ensure correct motor operation. It also covers parameter saving in EEPROM and brake control mechanisms.
Chapter 7 addresses system faults, memory-stored faults, and operation problems. It provides detailed steps for diagnosing issues such as "BUSY," "EEPROM," "°C MOTOR," "UNDERVOLT," "°C AMPLI," "POWER STAGE," "RESOLVER," "R.D.C," "I2T," and "CAN SYNCHRO." Each fault type includes specific checks and corrective actions.
Common issues like the motor not moving, lack of torque, erratic oscillations, and loud noises are addressed with troubleshooting steps. The document emphasizes checking connections, parameter settings, and mechanical components.
Guidelines for exchanging amplifiers include ensuring hardware configuration matches and transferring EEPROM parameters. The document also covers hardware adjustments for different motor series and braking system selection.
The appendix provides additional technical details, including hardware location diagrams, resolver connections, and adjustments for various components like motor thermal sensors.
- PTC Thermal Sensor: The resistance value at 120°C is specified as 3 kΩ, with a standard PSTH-A value of 10 kΩ.
- NTC Thermal Sensor: For motors with NTC sensors, the amplifier configuration requires the OP jumper closed and MN jumper open. The resistance value at 120°C is also 3 kΩ, with a standard PSTH-A value of 10 kΩ.
- For amplifiers ranging from 4 A to 100 A, the current loop jumpers are adjusted based on the calculated G value, which is a product of amplifier current and inductance between phases.
- Different jumper positions (B1, B2, B3) are used depending on the G value range.
- Fusing Mode: Activates Idyn signal at 85% of rated current. If current does not drop within 1 second, the amplifier is disabled.
- Limiting Mode: Similar to fusing mode, but the amplifier current is limited at the rated current value.
- Formulas are provided for calculating maximum current duration before Idyn signal release and current limitation.
- Logic inputs can be configured in positive or negative logic, affecting the response time and input impedance.
- "AMP READY" and "POWER READY" outputs depend on auxiliary supply configuration and jumper settings.
- The shield must remain uninterrupted over the cable length, with specific instructions for ensuring continuity using clamps and soldering.
- Details the coding system for ordering, including options for RS232, RS422, amplifier current rating, and additional features like auxiliary encoder input and braking resistor connection.
Catalog excerpts
SERVO DRIVES & MOTION CONTROL Digital drive with CANopen interface Installation Guide
Open the catalog to page 1
! This is a general manual describing a series of servo amplifiers having output capability suitable for driving AC brushless sinusoidal servo motors. This manual may be used in conjunction with appropriate and referenced drawings pertaining to the various specific models. Instructions for storage, use after storage, commissioning as well as all technical details require the MANDATORY reading of the manual before getting the amplifiers operational. Maintenance procedures should be attempted only by highly skilled technicians having good knowledge of electronics and servo systems with variable...
Open the catalog to page 2
OINFRANOR SERVO DRIVES & MOTION CONTROL
Open the catalog to page 3
Chapter 1 – General description 1 - INTRODUCTION Series SMT-BD1 digital servo modules are PWM servo amplifiers that provide speed control for AC sinusoidal motors (brushless) with transmitter resolver. The pluggable SMT-BD1 system is available as a single-axis block version or as a multi-axis version that can receive up to seven axes in a standard 19" rack including the power supply. The SMT-BD1/k amplifier is a version of the standard SMT-BD1 amplifier, with a CANopen interface allowing the receipt of the motion commands by the CAN bus instead of the analog +/- 10 V input. The operation of this...
Open the catalog to page 5
2.2 - REFERENCE TO THE STANDARDS The 220 VAC version of the SMT-BD1 amplifiers operating in the BF rack, which is equipped with the mains filter BF-35 or 70, has been approved for its conformity with the Electromagnetic Compatibility standards: - EN 55011, Group 1, Class A regarding the conducted and radiated radioelectric disturbances, - CEI 801 - 2 - 3 - 4 regarding the immunity. The 400 VAC version of the SMT-BD1 amplifiers operating in the BF-400 rack, which is equipped with the mains filter F400-35 or 70, has been approved for its conformity with the Electromagnetic Compatibility standards:...
Open the catalog to page 6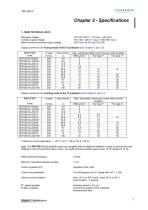
OINFRANOR SERVO DRIVES & MOTION CONTROL 1 - MAIN TECHNICAL DATA Auxiliary supply voltage 310 VDC ( 200 V < Uaux < 340 VDC max.) Motor terminal to terminal output voltage 200 Vrms for DC bus 310 VDC Output currents for the Fusing mode of the I2t protection (see Chapter 8, part 3.3) * Maximum room temperature = + 40° C, fan 1 = 56 l/s, fan 2 = 90 l/s Note: The SMT-BD1-k-X/Xr amplifier types are equipped with an additional heatsink in order to improve the heat dissipation and increase their rated current. The width of these amplifier types is then 18 TE instead of 12 TE. PWM switching frequency...
Open the catalog to page 7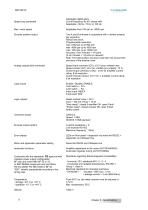
Speed loop bandwidth Adjustable digital gains Cut-off frequency for 45° phase shift: Selectable : 50 Hz, 75 Hz or 100 Hz Encoder position output Two A and B channels in quadrature with n marker pulse(s) per revolution. RS422 line driver. Programmable resolution: max. 8192 ppr up to 900 rpm max. 4096 ppr up to 3600 rpm max. 1024 ppr up to 14000 rpm Accuracy: 8 arc minutes + 1/4 point (2 arc minutes + 1/4 point on request) Note: The total position accuracy must take into account the accuracy of the resolver used. Analog outputs (test connector) Speed input command (CV): ±10 V pour ±vitesse max...
Open the catalog to page 8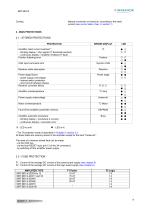
CINFRANOR Cooling Natural convection or forced air, according to the rated current (see current table, chap. 2, section 1)
Open the catalog to page 9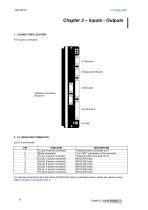
Front panel connectors: For resolver connections other than those of MAVILOR motors in standard version, please see resolver wiring table in Chapter 8 (Appendix), part 2.
Open the catalog to page 10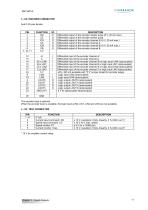
OINFRANOR 3 - X2: ENCODER CONNECTOR Sub D 25 pins female * 10 V for amplifier current rating
Open the catalog to page 11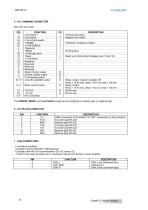
5 - X4: COMMAND CONNECTOR Sub D 25 pins male.
Open the catalog to page 12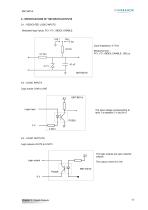
SMT-BD1/k 8 - SPECIFICATIONS OF THE INPUTS-OUTPUTS 8.1 - DEDICATED LOGIC INPUTS Dedicated logic inputs: FC+, FC-, INDEX, ENABLE. Response time: FC+, FC-, INDEX, ENABLE : 500 µs. 8.2 - LOGIC INPUTS Logic inputs: LIN0 to LIN5 Logic input The input voltage corresponding to level 1 is between 5 V and 24 V. PC829 8.3 - LOGIC OUTPUTS Logic outputs LOUT0 to LOUT3 The logic outputs are open collector outputs The output current is 5 mA.
Open the catalog to page 13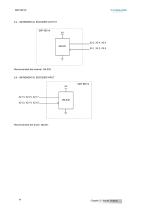
8.4 - INCREMENTAL ENCODER OUTPUT Recommended line receiver: 26LS32. 8.5 - INCREMENTAL ENCODER INPUT Recommended line driver: 26LS31.
Open the catalog to page 14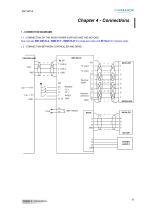
Chapter 4 - Connections 1 - CONNECTION DIAGRAMS 1.1 - CONNECTION OF THE RACK POWER SUPPLIES AND THE MOTORS See manuals SMT-BM 20 A - BMM 05 F - BMM 05 AF for single-axis racks and BF Rack for multiaxis racks. 1.2 - CONNECTION BETWEEN CONTROLLER AND DRIVE Resolver signal POWER SUPPLY
Open the catalog to page 15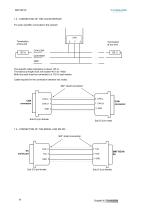
1.3 - CONNECTION OF THE CAN INTERFACE For each amplifier connected to the network: CAN HIGH GND The specific cable impedance is about 120 Ω. The total bus length must not exceed 40 m at 1 Mbit. Both bus ends must be connected to a 120 Ω load resistor. Cable required for the connection between two nodes: 360° shield connection 1.4 - CONNECTION OF THE SERIAL LINK RS 232 360° shield connection
Open the catalog to page 16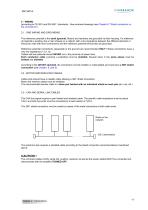
2 – WIRING (according to CEI 801 and EN 55011 standards - See enclosed drawings (see Chapter 8: "Shield connection on the connectors"). 2.1 - GND WIRING AND GROUNDING The reference potential is the earth (ground). Motors and resolvers are grounded via their housing. If a reference of potential is existing, like a main chassis or a cabinet, with a low impedance between the different elements, it should be used with short connections and this reference potential should also be grounded. Reference potential connections (especially to the ground) are recommended ONLY if these connections have a very...
Open the catalog to page 17
The SMT-BD1/k drive is only operated with the CANopen interface. All parameters can be modified by SDO (see CANopen Communication Protocol). The parameters can also be modified via the serial link. The VDSetup software version 1.11 and higher allows to adjust the amplifier parameters from a PC. The use of the VDSetup software is described in the pertaining User manual. The CAN bus communication speed is set by means of the SW2.3 and SW2.4 micro-switches (see Chapter 8, "Hardware adjustments" for the location of these micro-switches): The micro-switch position modification becomes effective at...
Open the catalog to page 18All Infranor Group catalogs and technical brochures
 XtrapulsPac_EN
4 Pages
 SMTBSi-2Tz_en_2.1
43 Pages
 PacSimBox_d_1
1 Page
 Pac-SF01_flyer_en_18.02
4 Pages
 Pac_User_1.2.1.218
253 Pages
 Pac_Templates_en_1.9
27 Pages
 Pac_STO_Installation_en_2.2
13 Pages
 Pac_SF01_operating_en_1.6
63 Pages
 Pac_SF01_EN
4 Pages
 Pac_Installation_en_2.23
82 Pages
 Pac_flyer_en_17.12
4 Pages
 Option_CT_EMF
6 Pages
 MOVINOR_LH055_LH086_LH097_LH142
23 Pages
 ma_series
6 Pages
 GemSafeTorqueOff_en_1.1
12 Pages
 CD1pm_e_1.2(old)
18 Pages
 CD1pInst_e_7.2(old)
35 Pages
 CD1kInst_e_4.1(old)
40 Pages
 CD1k_CANopenProtocol_e_1.3(old)
86 Pages
 CD1a_e_7.1(old)
45 Pages
 Catalogue gamme SMT-BD1
11 Pages
 BM20A(F)v3_0
20 Pages
 BM20A(D)v3_0
20 Pages
 BF400(GB)v2_2
21 Pages
 BF400(D)v2_2
21 Pages
 BF230(GB)v2_0
23 Pages
 BF230(F)v2_0
23 Pages
 BD2m_e_2.2
69 Pages
 BD2m(GB)2.0
70 Pages
 BD2_e_3.2
53 Pages
 BD2(GB)3.1
53 Pages
 BD2(D)3.1
54 Pages
 Movinor_LH_e
4 Pages
 ma_series
6 Pages
 BD1t(GB)3.1
81 Pages
 BD1t(F)3.0
85 Pages
 BD1pInst(GB)3.0
25 Pages
 BD1pInst(F)3.0
23 Pages
 BD1pInst(D)3.0
24 Pages
 BD1pCD1pUse_e_2.4
57 Pages
 BD1m(GB)5.0
58 Pages
 BD1m(F)5.0
57 Pages
 BD1m(D)v3_3
64 Pages
 BD1k(F)2.1
36 Pages
 BD1j(GB)v2_41
19 Pages
 BD1j(F)v2_4
21 Pages
 BD1i(GB)v2_21
23 Pages
 BD1i(F)v2_2
27 Pages
 BD1h(F)3.0
65 Pages
 BD1h(D)3.0
59 Pages
 BD1g(GB)v3_0
28 Pages
 BD1g(F)v3_0
28 Pages
 BD1a400(GB)v2_3
43 Pages
 BD1a400(F)v2_3
44 Pages
 BD1a400(D)v2_3
45 Pages
 BD1(GB)7.1_noPW
45 Pages
 BD1(GB)7.1
45 Pages
 BD1(F)7.1_noPW
47 Pages
 BD1(F)7.1
47 Pages
 BD1(D)7.1
45 Pages
 BD1 Katalog
11 Pages
 Easy_User_5.0.1.60.2
190 Pages
 01ma_smv_e_01953
40 Pages
 PacHP-SF_Flyer_en_23.06
4 Pages
 IRD_User_Manual_en_1.2.XX.54.rev_b
216 Pages
 PacHP_User_en_1.2.8.100.b
280 Pages
 PacHP_SF02_operating_en_1.6
103 Pages
 PacHP_SF01_operating_en_2.0
63 Pages
 PacHP_Installation_en_2.9
91 Pages
 PacHP_Series_Brochure
8 Pages
 PacHP_Flyer_us_20.10
4 Pages
 IRD_Installation_en_1.5
42 Pages
 Easy_STO_en_1.4
14 Pages
 Easy_DB_STO_en_1.2
14 Pages
 Easy_DB_Installation_en_1.4
36 Pages
 CD1pmUser_en_4.2
55 Pages
 CD1pmInst_en_8.15
40 Pages
 CD1k_CANopenProtocol_en_2.10.1.1
108 Pages
 CD1pm_ProfibusProtocol_en_1.5
50 Pages
 CD1kUser_en_2.3
26 Pages
 CD1a_en_8.17
62 Pages
 CD1kInst_en_5.16
46 Pages
 CD1_STO_en_1.8
16 Pages
 CD1_flyer_en_14.09
4 Pages
 Braking_Resistors_en_1.5
10 Pages
 XtracontrolDC2_EN
4 Pages
 Flyer_VisiTouchCNC_EN_V1.1-1
2 Pages
 XtraforsWashdown_EN-2024
2 Pages
 DataSheet_CybIO_CNC_V1.0
6 Pages
 XtraforsPrime_EN-2024
2 Pages
 XtraforsMSS_EN
4 Pages
 XtraforsMSA_EN_2024
2 Pages
 XtraforsEx_EN-2024
2 Pages
 XtraforsBR_EN-2024
2 Pages
 XtraforsBL_EN-2024
2 Pages
 XtraforsBC-ed01-vs3
4 Pages
 Manual_XtraforsPrime
46 Pages
 Drawing_1
1 Page
 Datasheet_MSS
5 Pages
 Datasheet_2
2 Pages
 Datasheet_1
4 Pages
 BLSBLT_series
2 Pages
 BL220221
2 Pages
 BL270
2 Pages
 BL190
2 Pages
 bl100_series
6 Pages
 bl40_series
6 Pages
 BL30
2 Pages
 2019-01_XtraforsFP-DSL_FR
4 Pages
 Movinor_T_EN
4 Pages
 Movinor_N_EN
4 Pages
 Movinor_Low_Voltage_EN
4 Pages
 Manual Movinor T 03-2026
46 Pages
 Manual Movinor N 03-2026
63 Pages
 XtrapulsEasy™ AC servo-drive
4 Pages
 XtrapulsCD1 AC servo-drives
4 Pages
 CybIO
6 Pages
 AC SERVOMOTORS
2 Pages
 Movinor® N AC Servomotors
4 Pages






Archived catalogs
 AN_CD1ak_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1ak_SinCosTracks_e_1.0
7 Pages
 AN_CD1pm_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1pm_SinCosTracks_e_1.0
7 Pages
 AN_DC_bus_interfacing_en_1.3
5 Pages
 CD1_EC_conformity_24.05
1 Page
 CD1_STO_conformity_19.02
2 Pages
 EtherCAT Interface_en_1.3
20 Pages
 Easy_EC_Conformity_24_10
1 Page
 GDPS_EC_conformity_24.07
1 Page
 IRD_EC_Conformity_25.03
1 Page
 PacHP_TÜV_certificate_25.07
2 Pages
 BD1c(F)v2_01
19 Pages
 BD1c(GB)v2_01
19 Pages
 BD1d(F)v2_01
25 Pages
 BD1d(GB)v2_01
25 Pages
 BD1e(F)v2_01
22 Pages
 BD1f(F)v2_01
17 Pages
 BD1f(GB)v2_01
18 Pages
 Pac_EC_conformity_25.04
1 Page




















