
- Catalogs
- Infranor Group
- BD1i(GB)v2_21


BD1i(GB)v2_21

BD1i(GB)v2_21
The SMT-BD1/i amplifier is engineered for tension control in winding/unwinding systems, utilizing the SMT-I3-BD1 daughter board and EEPROM X.X 6. It maintains constant material tension through a ±10 V analogue signal from a tension sensor, adjusting motor speed based on spool diameter and line speed.
- Line Speed Measurement: Differential encoder input with a maximum frequency of 250 kHz.
- Motor Encoder Resolution: Programmable up to 8192 ppr.
- Spool Diameter Measurement: 0 V to 10 V analogue input with 11-bit resolution.
- Speed Regulator: P or PI regulator with a sampling period of 0.5 ms.
- Material Tension Measurement: Analogue input from -10 V to +10 V with 12-bit resolution.
- X4 Command Connector: Includes pins for limit switches, torque control, tension measurement, and more.
- X2 Command Connector: Manages motor encoder outputs and logic inputs for tension reference selection and motor direction.
Diagrams for connecting with the master amplifier and encoder, along with mandatory wiring instructions, are provided.
Includes operation mode, application parameters, and regulator parameters for speed and tension.
Steps for configuration checks, power application, and adjusting master/slave settings with empty and full spools are outlined.
Guidance on addressing loud noises in the motor at standstill and during operation is provided.
Includes a location diagram of hardware options.
The document details specifications for speed and tension control, including speed input commands, DAC output specifications, and linearity details for different logic boards. It emphasizes the use of shielded cables for encoder signals and provides detailed wiring instructions.
Chapter 4 details connection diagrams for interfacing with the master amplifier and encoder, stressing the importance of shielded cables and proper grounding to prevent signal interference.
Chapter 5 discusses adjustable parameters for tension control, including maximum speed variation, tension input filter, and tension set points. It covers diameter sensor scaling for accurate spool diameter measurement, with instructions on setting these parameters using BPCW software.
The document describes PI speed regulator and PID tension regulator structures, providing guidance on setting proportional, integral, and derivative gains for both speed and tension regulators. It highlights the importance of adaptive gain settings based on spool diameter.
Chapter 6 outlines the commissioning process, including configuration checks, power application, and master/slave adjustments. It provides step-by-step instructions for adjustments with empty and full spools, emphasizing the AUTO-TUNING function for optimal regulator gains.
Stability and Auto-Tuning: Ensure stability by removing the full spool, re-engaging the empty one, and performing the AUTO-TUNING procedure with the antiresonance filter activated. Adjust the Diameter sensor value for maximum gain based on spool diameter and motor shaft inertia ratios.
Loud Crackling Noise at Standstill: Verify ground connections and wiring as per Chapter 4.
Loud Noise at Standstill and Running: Check mechanical coupling rigidity. Re-execute AUTO-TUNING with a lower bandwidth or activate the antiresonance filter.
Loud Noise When Running: Adjust encoder resolution and filter parameters to reduce noise.
Hardware Options Location Diagram: Refer to the appendix for detailed diagrams of hardware options.
Catalog excerpts
SMT-BD1/i (GB) Winding/unwinding tension control
Open the catalog to page 1
This manual describes the option "i" of the SMT-BD1 amplifier: Tension control of winding / unwinding systems. The general information about the digital amplifier commissioning are described in the standard SMTBD1 manual. This manual may be used in conjunction with appropriate and referenced drawings pertaining to the various specific models. Maintenance procedures should be attempted only by highly skilled technicians (EN 60 204.1 standard) using proper test equipment. The conformity with the standards and the "CE" approval are only valid if the items are installed according to the recommendations...
Open the catalog to page 2
TENSION CONTROL OF WINDING/UNWINDING SYSTEMS
Open the catalog to page 4
CHAPTER 1 - GENERAL DESCRIPTION The tension control for winding/unwinding systems requires the SMT-I3-BD1 daughter board and the X.X 6 EEPROM. In this configuration, the SMT-BD1/i amplifier controls the speed of the motor driving the spool, in order to maintain a constant material tension independently of its line speed and of the spool diameter. The material tension is controlled by the amplifier via a ± 10 V analogue signal ( TM) provided by a tension sensor. The spool diameter measurement (DIAM) is also received by the amplifier as an analogue voltage between 0 V and 10 V. These signals are...
Open the catalog to page 6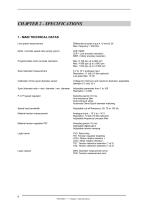
CHAPTER 2 - SPECIFICATIONS 1 - MAIN TECHNICAL DATAS Line speed measurement Differential encoder input A, A/ and B, B/ Max. frequency = 250 kHz Motor / encoder speed ratio (empty spool) LER / MER LER = Line encoder resolution MER = Motor encoder resolution Programmable motor encoder resolution Spool diameter measurement 0 V to 10 V analogue input Resolution: 11 bits (15 bits optional) Low-pass filter: 10 Hz Calibration of the spool diameter sensor Voltage for minimum and maximum diameter: adjustable between 0 V and 10 V Spool diameter ratio = max. diameter / min. diameter Adjustable parameter...
Open the catalog to page 7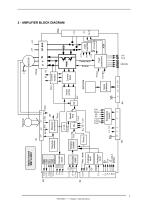
Vref Vmes Perr Selectable ouputs Speed loop Resolver conversion Analogue input Analogue input Serial interface Current loops Current monitor Vector control Fault protections Tension control Resolver oscillator Power fault Encoder input Logic supplies 2 - AMPLIFIER BLOCK DIAGRAM
Open the catalog to page 8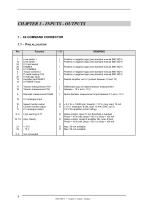
Limit switch -0 V limit switch ENABLE 0 V ENABLE Torque control CI P mode braking CV0 0 Volt logic input Amplifier fault RESET 0 V RESET input 17 Tension measurement TM+ 16 Tension measurement TM- Diameter measurement DIAM Speed monitor output Current monitor output Positive or negative Positive or negative Positive or negative Positive or negative logic (see standard manual SMT-BD1) logic (see standard manual SMT-BD1) logic (see standard manual SMT-BD1) logic (see standard manual SMT-BD1) logic (see standard manual SMT-BD1) Differential input of material tension measurement between - 10 V and...
Open the catalog to page 9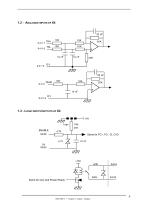
1.3 - LOGIC INPUTS /OUTPUTS OF X4 +5V Log+ Same for Idyn and Power Ready SMT-BD1/i Ÿ Chapter 3: Inputs - Outputs
Open the catalog to page 10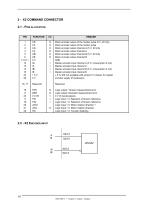
Reserved TER DER 0 V I/O TS1 TS2 JOG+ JOGTDI REMARK Motor encoder output of the marker pulse (5 V, 20 mA) Motor encoder output of the marker pulse Motor encoder output channel A (5 V, 20 mA) Motor encoder output channel A Motor encoder output channel B (5 V, 20 mA) Motor encoder output channel B GND Master encoder input channel A (5 V, consumption 2 mA) Master encoder input channel A Master encoder input channel B (5 V, consumption 2 mA) Master encoder input channel B ± 5 % 300 mA available with jumper 5 V closed, for master encoder supply (if necessary) Reserved Logic output: Tension measurement...
Open the catalog to page 11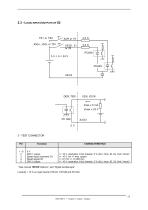
2.3 - LOGIC INPUTS /OUTPUTS OF X2 Function 0V DAC 1 output Speed input command CV Speed signal GT DAC 2 output +/- 10 V, resolution: 8 bit, linearity: 2 % (IDC, Imon, ID, IQ, Vref, Vmon)* +/- 10 V for +/- max. speed +/- 8 V for +/- 14 000 rpm +/- 10 V, resolution: 8 bit, linearity: 2 % (IDC, Imon, ID, IQ, Vref, Vmon)* * See manual "BPCW Options", part "Digital oscilloscope". Linearity = 10 % on logic boards 01612A, 01612B and 01612C. SMT-BD1/i Ÿ Chapter 3: Inputs - Outputs
Open the catalog to page 12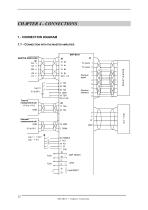
1 - CONNECTION DIAGRAM1.1 - Connection with the master amplifier SMT-BD1/i MASTER AMPLIFIER Tension measurement cell - 10 V to + 10 V Diameter measurement cell GND Fault RESET SMT-BDl/i • Chapter 4: Connections
Open the catalog to page 13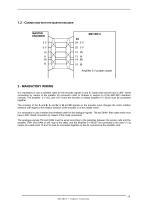
1.2 - CONNECTION WITH THE MASTER ENCODER MASTER ENCODER 15 IB Amplifier 5 V jumper closed 2 - MANDATORY WIRING It is mandatory to use a shielded cable for the encoder signals A and B. Cable ends should have a 360° shield connection by means of the metallic X2 connector (refer to Chapter 8, section 6 of the SMT-BD1 standard manual). The amplifier 0 V (X2, pins 10/11) and the encoder or master amplifier 0 V (Gnd) must be connected together. The crossing of the A and B, A and A/ or B and B/ signals on the encoder input changes the motor rotation direction with regard to the rotation direction of...
Open the catalog to page 14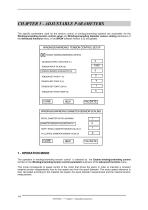
The specific parameters used for the tension control of winding/unwinding systems are accessible via the Winding/unwinding tension control setup and Winding/unwinding diameter sensor scaling submenus of the Advanced functions menu, in the BPCW software version 2.52 and greater. ENABLE WINDING/UNWINDING CONTROL MAXIMUM SPEED VARIATION (%) TENSION INPUT FILTER (Hz) TENSION SENSOR ACQUISITION (V) TENSION SET POINT 1 (V) TENSION SET POINT 2 (V) TENSION SET POINT LOW (V) TENSION SET POINT RAMP (S) The operation in winding/unwinding tension control is selected by the Enable winding/unwinding control...
Open the catalog to page 15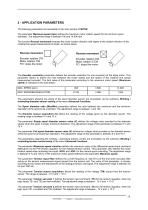
The following parameters are accessible in the main window of BPCW. The parameter Maximum speed (rpm) defines the maximum motor rotation speed (for the minimum spool diameter). The adjustment range is between 100 and 14 000 rpm. The function Reverse movement reverses the motor rotation direction with regard to the rotation direction of the material line speed measurement encoder, as shown below. Reverse movement Encoder rotation CW Motor rotation CW FC+ stops the motor Encoder rotation CW Motor rotation CCW FC- stops the motor The Encoder resolution parameter defines the encoder resolution for...
Open the catalog to page 16All Infranor Group catalogs and technical brochures
 XtrapulsPac_EN
4 Pages
 SMTBSi-2Tz_en_2.1
43 Pages
 PacSimBox_d_1
1 Page
 Pac-SF01_flyer_en_18.02
4 Pages
 Pac_User_1.2.1.218
253 Pages
 Pac_Templates_en_1.9
27 Pages
 Pac_STO_Installation_en_2.2
13 Pages
 Pac_SF01_operating_en_1.6
63 Pages
 Pac_SF01_EN
4 Pages
 Pac_Installation_en_2.23
82 Pages
 Pac_flyer_en_17.12
4 Pages
 Option_CT_EMF
6 Pages
 MOVINOR_LH055_LH086_LH097_LH142
23 Pages
 ma_series
6 Pages
 GemSafeTorqueOff_en_1.1
12 Pages
 CD1pm_e_1.2(old)
18 Pages
 CD1pInst_e_7.2(old)
35 Pages
 CD1kInst_e_4.1(old)
40 Pages
 CD1k_CANopenProtocol_e_1.3(old)
86 Pages
 CD1a_e_7.1(old)
45 Pages
 Catalogue gamme SMT-BD1
11 Pages
 BM20A(F)v3_0
20 Pages
 BM20A(D)v3_0
20 Pages
 BF400(GB)v2_2
21 Pages
 BF400(D)v2_2
21 Pages
 BF230(GB)v2_0
23 Pages
 BF230(F)v2_0
23 Pages
 BD2m_e_2.2
69 Pages
 BD2m(GB)2.0
70 Pages
 BD2_e_3.2
53 Pages
 BD2(GB)3.1
53 Pages
 BD2(D)3.1
54 Pages
 Movinor_LH_e
4 Pages
 ma_series
6 Pages
 BD1t(GB)3.1
81 Pages
 BD1t(F)3.0
85 Pages
 BD1pInst(GB)3.0
25 Pages
 BD1pInst(F)3.0
23 Pages
 BD1pInst(D)3.0
24 Pages
 BD1pCD1pUse_e_2.4
57 Pages
 BD1m(GB)5.0
58 Pages
 BD1m(F)5.0
57 Pages
 BD1m(D)v3_3
64 Pages
 BD1k(GB)2.1
35 Pages
 BD1k(F)2.1
36 Pages
 BD1j(GB)v2_41
19 Pages
 BD1j(F)v2_4
21 Pages
 BD1i(F)v2_2
27 Pages
 BD1h(F)3.0
65 Pages
 BD1h(D)3.0
59 Pages
 BD1g(GB)v3_0
28 Pages
 BD1g(F)v3_0
28 Pages
 BD1a400(GB)v2_3
43 Pages
 BD1a400(F)v2_3
44 Pages
 BD1a400(D)v2_3
45 Pages
 BD1(GB)7.1_noPW
45 Pages
 BD1(GB)7.1
45 Pages
 BD1(F)7.1_noPW
47 Pages
 BD1(F)7.1
47 Pages
 BD1(D)7.1
45 Pages
 BD1 Katalog
11 Pages
 Easy_User_5.0.1.60.2
190 Pages
 01ma_smv_e_01953
40 Pages
 PacHP-SF_Flyer_en_23.06
4 Pages
 IRD_User_Manual_en_1.2.XX.54.rev_b
216 Pages
 PacHP_User_en_1.2.8.100.b
280 Pages
 PacHP_SF02_operating_en_1.6
103 Pages
 PacHP_SF01_operating_en_2.0
63 Pages
 PacHP_Installation_en_2.9
91 Pages
 PacHP_Series_Brochure
8 Pages
 PacHP_Flyer_us_20.10
4 Pages
 IRD_Installation_en_1.5
42 Pages
 Easy_STO_en_1.4
14 Pages
 Easy_DB_STO_en_1.2
14 Pages
 Easy_DB_Installation_en_1.4
36 Pages
 CD1pmUser_en_4.2
55 Pages
 CD1pmInst_en_8.15
40 Pages
 CD1k_CANopenProtocol_en_2.10.1.1
108 Pages
 CD1pm_ProfibusProtocol_en_1.5
50 Pages
 CD1kUser_en_2.3
26 Pages
 CD1a_en_8.17
62 Pages
 CD1kInst_en_5.16
46 Pages
 CD1_STO_en_1.8
16 Pages
 CD1_flyer_en_14.09
4 Pages
 Braking_Resistors_en_1.5
10 Pages
 XtracontrolDC2_EN
4 Pages
 Flyer_VisiTouchCNC_EN_V1.1-1
2 Pages
 XtraforsWashdown_EN-2024
2 Pages
 DataSheet_CybIO_CNC_V1.0
6 Pages
 XtraforsPrime_EN-2024
2 Pages
 XtraforsMSS_EN
4 Pages
 XtraforsMSA_EN_2024
2 Pages
 XtraforsEx_EN-2024
2 Pages
 XtraforsBR_EN-2024
2 Pages
 XtraforsBL_EN-2024
2 Pages
 XtraforsBC-ed01-vs3
4 Pages
 Manual_XtraforsPrime
46 Pages
 Drawing_1
1 Page
 Datasheet_MSS
5 Pages
 Datasheet_2
2 Pages
 Datasheet_1
4 Pages
 BLSBLT_series
2 Pages
 BL220221
2 Pages
 BL270
2 Pages
 BL190
2 Pages
 bl100_series
6 Pages
 bl40_series
6 Pages
 BL30
2 Pages
 2019-01_XtraforsFP-DSL_FR
4 Pages
 Movinor_T_EN
4 Pages
 Movinor_N_EN
4 Pages
 Movinor_Low_Voltage_EN
4 Pages
 Manual Movinor T 03-2026
46 Pages
 Manual Movinor N 03-2026
63 Pages
 XtrapulsEasy™ AC servo-drive
4 Pages
 XtrapulsCD1 AC servo-drives
4 Pages
 CybIO
6 Pages
 AC SERVOMOTORS
2 Pages
 Movinor® N AC Servomotors
4 Pages






Archived catalogs
 AN_CD1ak_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1ak_SinCosTracks_e_1.0
7 Pages
 AN_CD1pm_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1pm_SinCosTracks_e_1.0
7 Pages
 AN_DC_bus_interfacing_en_1.3
5 Pages
 CD1_EC_conformity_24.05
1 Page
 CD1_STO_conformity_19.02
2 Pages
 EtherCAT Interface_en_1.3
20 Pages
 Easy_EC_Conformity_24_10
1 Page
 GDPS_EC_conformity_24.07
1 Page
 IRD_EC_Conformity_25.03
1 Page
 PacHP_TÜV_certificate_25.07
2 Pages
 BD1c(F)v2_01
19 Pages
 BD1c(GB)v2_01
19 Pages
 BD1d(F)v2_01
25 Pages
 BD1d(GB)v2_01
25 Pages
 BD1e(F)v2_01
22 Pages
 BD1f(F)v2_01
17 Pages
 BD1f(GB)v2_01
18 Pages
 Pac_EC_conformity_25.04
1 Page




















