
- Catalogs
- Infranor Group
- BD1f(GB)v2_01


BD1f(GB)v2_01

BD1f(GB)v2_01
Catalog excerpts
SMT-BD1/f (GB) Spindle motor indexing
Open the catalog to page 1
This manual describes the option "f" of the SMT-BD1 amplifier: Spindle motor indexing. The general information about the digital amplifier commissioning are described in the standard SMT-BD1 manual. This manual may be used in conjunction with appropriate and referenced drawings pertaining to the various specific models. Maintenance procedures should be attempted only by highly skilled technicians (EN 60 204.1 standard) using proper test equipment. The conformity with the standards and the "CE" approval are only valid if the items are installed according to the recommendations of the racks and...
Open the catalog to page 2
SPINDLE MOTOR INDEXING WITH THE SMT-BD1/f AMPLIFIER
Open the catalog to page 4
CHAPTER 1 - GENERAL DESCRIPTION Applications with spindle motor indexing require the SMT-I2-BD1 daughter board on the SMT-BD1 amplifier and the firmware memory version X.XF. In this configuration, the SMT-BD1/f amplifier ensures the positioning of the spindle motor shaft during the tool exchange, according four programmable positions. The spindle motor must be equipped with a one pole pair resolver (speed 1) for the absolute definition of the four indexing positions on one shaft revolution. The logic inputs and outputs which are necessary for this kind of operation, are wired on the amplifier...
Open the catalog to page 6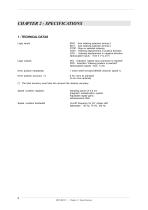
CHAPTER 2 - SPECIFICATIONS 1 - TECHNICAL DATAS Logic inputs IDX0 : Axis indexing selection among 4 IDX1 : Axis indexing selection among 4 STOP : Stop on selected indexing JOG+ : Indexing displacement in positive direction JOG- : Indexing displacement in negative direction Optocoupled inputs : from 5 V to 24 V Logic outputs VEL : Indication "speed input command is reached" POS : Indication "indexing position is reached" Optocoupled outputs Imax 5 mA Drive position repetability 1 motor shaft revolution/65536 (resolver speed 1) Drive position accuracy (*) 8 Arc mins as standard (2 arc mins optional)...
Open the catalog to page 7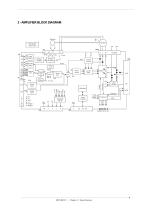
2 - AMPLIFIER BLOCK DIAGRAM Resolver MOTOR Resolver conversion Resolver oscillator Current monitor Indexing input Pref Vmes Position loop Vector control Speed loop Current loops Analog input Analog input EEPROM Power fault P err Vmes Vref IQ ID Imes Idc Serial interface Selectable outputs Logic supplies
Open the catalog to page 8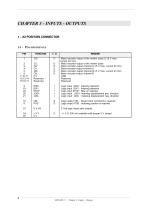
Motor encoder output of the marker pulse Z/ (5 V max. current 20 mA) Motor encoder output of the marker pulse Motor encoder output channel A/ (5 V max. current 20 mA) Motor encoder output channel A Motor encoder output channel B/ (5 V max. current 20 mA) Motor encoder output channel B Logic input IDX0 : Indexing selection Logic input IDX1 : Indexing selection Logic input STOP : Stop on indexing Logic input JOG+: Indexing displacement pos. direction Logic input JOG- : Indexing displacement neg. direction O Logic output VEL : Speed input command is reached O Logic output POS : Indexing position...
Open the catalog to page 9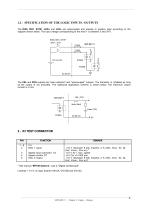
The IDX0, IDX1, STOP, JOG+ and JOG- are optocoupled and operate in positive logic according to the diagram shown below. The input voltage corresponding to the level 1 is between 5 and 24 V. The VEL and POS outputs are "open collector" and "optocoupled" outputs. The transistor is inhibited as long as the output is not activated. The traditional application scheme is shown below. The maximum output current is 5 mA. * See manual "BPCW Options", part 2 "Digital oscilloscope". Linearity = 10 % on logic boards 01612A, 01612B and 01612C. SMT-BD1/f • Chapter 3: Inputs - Outputs
Open the catalog to page 10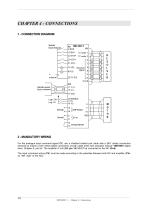
Spindle speed input command Default RESET For the analogue input command signal CV, use a shielded twisted pair cable with a 360° shield connection ensured by means of the metal plated connectors at both cable ends (see standard manual "SMT-BD1 digital drive, Chapter 8, part 6). The amplifier 0 Volt (X4, pin 15) MUST be connected to the NC (Gnd). The input command wiring (CV) must be made according to the polarities between both NC and amplifier (CV+ on "diff. high" of the NC).
Open the catalog to page 11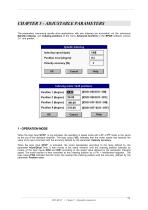
The parameters concerning spindle drive applications with axis indexing are accessible via the submenus Spindle indexing and Indexing positions of the menu Advanced functions in the BPCW software version 2.0. and greater. Indexing motor shaft positions 1 - OPERATION MODE When the logic input STOP is not activated, the operation in speed mode with a PI or PI2 mode is the same as the one of the standard amplifier. The logic output VEL indicates that the motor speed has reached the value of its input command with the accuracy defined by the parameter Velocity accuracy. When the logic input STOP...
Open the catalog to page 12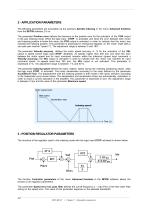
2 - APPLICATION PARAMETERS The following parameters are accessible via the submenu Spindle indexing in the menu Advanced functions from the BPCW software 2.0 on. The parameter Position error defines the tolerance on the position error for the activation of the POS output in the axis indexing mode. When the logic input STOP is activated and when the error between both motor and indexing position is below this value, the POS output is activated in order to indicate that the motor has reached the indexing position. This parameter is expressed in mechanical degrees on the motor shaft (with a one...
Open the catalog to page 13
The parameter Proportional speed gain defines the proportional gain (KP2) of the regulator acting on the speed error. The adjustment range is between 0 and 4 095. The parameter Integral 1 speed gain defines the first integral gain (KI) of the regulator acting on the speed error. The adusjtment range is between 0 and 255. The parameter Proportional position gain defines the proportional gain acting on the position error (KP1). The adjustment range is between 0 and 1. The parameter Feedforward position gain defines the amplitude of the anticipating term (KF) corresponding to the speed input command...
Open the catalog to page 14
CHAPTER 6 - COMMISSIONING 1 - CHECKING THE CONFIGURATION Check the amplifier standard configuration as described in Chapter 6 of the standard SMT-BD1 manual. Check for the presence of the SMT-I2-BD1 daughter board between both logic and power boards (see chapter 8 (Appendix): Location diagram of the hardware options). Check for the X.XF firmware memory version. Check that the jumpers E and S of the amplifier logic board are open (see chapter 8 (Appendix): Location diagram of the hardware options). 2 - POWERING Turn on the amplifier as described in Chapter 6 of the standard SMT-BD1 manual. 3 -...
Open the catalog to page 15All Infranor Group catalogs and technical brochures
 XtrapulsPac_EN
4 Pages
 SMTBSi-2Tz_en_2.1
43 Pages
 PacSimBox_d_1
1 Page
 Pac-SF01_flyer_en_18.02
4 Pages
 Pac_User_1.2.1.218
253 Pages
 Pac_Templates_en_1.9
27 Pages
 Pac_STO_Installation_en_2.2
13 Pages
 Pac_SF01_operating_en_1.6
63 Pages
 Pac_SF01_EN
4 Pages
 Pac_Installation_en_2.23
82 Pages
 Pac_flyer_en_17.12
4 Pages
 Option_CT_EMF
6 Pages
 MOVINOR_LH055_LH086_LH097_LH142
23 Pages
 ma_series
6 Pages
 GemSafeTorqueOff_en_1.1
12 Pages
 CD1pm_e_1.2(old)
18 Pages
 CD1pInst_e_7.2(old)
35 Pages
 CD1kInst_e_4.1(old)
40 Pages
 CD1k_CANopenProtocol_e_1.3(old)
86 Pages
 CD1a_e_7.1(old)
45 Pages
 Catalogue gamme SMT-BD1
11 Pages
 BM20A(F)v3_0
20 Pages
 BM20A(D)v3_0
20 Pages
 BF400(GB)v2_2
21 Pages
 BF400(D)v2_2
21 Pages
 BF230(GB)v2_0
23 Pages
 BF230(F)v2_0
23 Pages
 BD2m_e_2.2
69 Pages
 BD2m(GB)2.0
70 Pages
 BD2_e_3.2
53 Pages
 BD2(GB)3.1
53 Pages
 BD2(D)3.1
54 Pages
 Movinor_LH_e
4 Pages
 ma_series
6 Pages
 BD1t(GB)3.1
81 Pages
 BD1t(F)3.0
85 Pages
 BD1pInst(GB)3.0
25 Pages
 BD1pInst(F)3.0
23 Pages
 BD1pInst(D)3.0
24 Pages
 BD1pCD1pUse_e_2.4
57 Pages
 BD1m(GB)5.0
58 Pages
 BD1m(F)5.0
57 Pages
 BD1m(D)v3_3
64 Pages
 BD1k(GB)2.1
35 Pages
 BD1k(F)2.1
36 Pages
 BD1j(GB)v2_41
19 Pages
 BD1j(F)v2_4
21 Pages
 BD1i(GB)v2_21
23 Pages
 BD1i(F)v2_2
27 Pages
 BD1h(F)3.0
65 Pages
 BD1h(D)3.0
59 Pages
 BD1g(GB)v3_0
28 Pages
 BD1g(F)v3_0
28 Pages
 BD1a400(GB)v2_3
43 Pages
 BD1a400(F)v2_3
44 Pages
 BD1a400(D)v2_3
45 Pages
 BD1(GB)7.1_noPW
45 Pages
 BD1(GB)7.1
45 Pages
 BD1(F)7.1_noPW
47 Pages
 BD1(F)7.1
47 Pages
 BD1(D)7.1
45 Pages
 BD1 Katalog
11 Pages
 Easy_User_5.0.1.60.2
190 Pages
 01ma_smv_e_01953
40 Pages
 PacHP-SF_Flyer_en_23.06
4 Pages
 IRD_User_Manual_en_1.2.XX.54.rev_b
216 Pages
 PacHP_User_en_1.2.8.100.b
280 Pages
 PacHP_SF02_operating_en_1.6
103 Pages
 PacHP_SF01_operating_en_2.0
63 Pages
 PacHP_Installation_en_2.9
91 Pages
 PacHP_Series_Brochure
8 Pages
 PacHP_Flyer_us_20.10
4 Pages
 IRD_Installation_en_1.5
42 Pages
 Easy_STO_en_1.4
14 Pages
 Easy_DB_STO_en_1.2
14 Pages
 Easy_DB_Installation_en_1.4
36 Pages
 CD1pmUser_en_4.2
55 Pages
 CD1pmInst_en_8.15
40 Pages
 CD1k_CANopenProtocol_en_2.10.1.1
108 Pages
 CD1pm_ProfibusProtocol_en_1.5
50 Pages
 CD1kUser_en_2.3
26 Pages
 CD1a_en_8.17
62 Pages
 CD1kInst_en_5.16
46 Pages
 CD1_STO_en_1.8
16 Pages
 CD1_flyer_en_14.09
4 Pages
 Braking_Resistors_en_1.5
10 Pages
 XtracontrolDC2_EN
4 Pages
 Flyer_VisiTouchCNC_EN_V1.1-1
2 Pages
 XtraforsWashdown_EN-2024
2 Pages
 DataSheet_CybIO_CNC_V1.0
6 Pages
 XtraforsPrime_EN-2024
2 Pages
 XtraforsMSS_EN
4 Pages
 XtraforsMSA_EN_2024
2 Pages
 XtraforsEx_EN-2024
2 Pages
 XtraforsBR_EN-2024
2 Pages
 XtraforsBL_EN-2024
2 Pages
 XtraforsBC-ed01-vs3
4 Pages
 Manual_XtraforsPrime
46 Pages
 Drawing_1
1 Page
 Datasheet_MSS
5 Pages
 Datasheet_2
2 Pages
 Datasheet_1
4 Pages
 BLSBLT_series
2 Pages
 BL220221
2 Pages
 BL270
2 Pages
 BL190
2 Pages
 bl100_series
6 Pages
 bl40_series
6 Pages
 BL30
2 Pages
 2019-01_XtraforsFP-DSL_FR
4 Pages
 Movinor_T_EN
4 Pages
 Movinor_N_EN
4 Pages
 Movinor_Low_Voltage_EN
4 Pages
 Manual Movinor T 03-2026
46 Pages
 Manual Movinor N 03-2026
63 Pages
 XtrapulsEasy™ AC servo-drive
4 Pages
 XtrapulsCD1 AC servo-drives
4 Pages
 CybIO
6 Pages
 AC SERVOMOTORS
2 Pages
 Movinor® N AC Servomotors
4 Pages






Archived catalogs
 AN_CD1ak_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1ak_SinCosTracks_e_1.0
7 Pages
 AN_CD1pm_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1pm_SinCosTracks_e_1.0
7 Pages
 AN_DC_bus_interfacing_en_1.3
5 Pages
 CD1_EC_conformity_24.05
1 Page
 CD1_STO_conformity_19.02
2 Pages
 EtherCAT Interface_en_1.3
20 Pages
 Easy_EC_Conformity_24_10
1 Page
 GDPS_EC_conformity_24.07
1 Page
 IRD_EC_Conformity_25.03
1 Page
 PacHP_TÜV_certificate_25.07
2 Pages
 BD1c(F)v2_01
19 Pages
 BD1c(GB)v2_01
19 Pages
 BD1d(F)v2_01
25 Pages
 BD1d(GB)v2_01
25 Pages
 BD1e(F)v2_01
22 Pages
 BD1f(F)v2_01
17 Pages
 Pac_EC_conformity_25.04
1 Page




















