
- Catalogs
- Infranor Group
- BD1(GB)7.1


BD1(GB)7.1

BD1(GB)7.1
Catalog excerpts
SERVO DRIVES & MOTION CONTROL SMT-BD1 digital drive for AC sinusoidal synchronous motors
Open the catalog to page 1
! This is a general manual describing a series of servo amplifiers having output capability suitable for driving AC brushless sinusoidal servo motors. This manual may be used in conjunction with appropriate and referenced drawings pertaining to the various specific models. Instructions for storage, use after storage, commissioning as well as all technical details require the MANDATORY reading of the manual before getting the amplifiers operational. Maintenance procedures should be attempted only by highly skilled technicians having good knowledge of electronics and servo systems with variable...
Open the catalog to page 3
SERVO DRIVES & MOTION COmtOl
Open the catalog to page 5
Chapter 1 - General description 1- INTRODUCTION Series SMT-BD1 digital servo modules are PWM servo amplifiers that provide speed control for AC sinusoidal motors (brushless) with transmitter resolver. The pluggable SMT-BD1 system is available as a single-axis block version or as a multi-axis version that can receive up to seven axes in a standard 19" rack including the power supply. * The basic amplifier module SMT-BD1 / a or b provides the speed control for AC synchronous motors with +/- 10 V analog speed input command. The SMT-BD1 / c version with its specific option board allows the direct...
Open the catalog to page 7
OINFRANOR 2.2 - REFERENCE TO THE STANDARDS The 220 VAC version of the SMT-BD1 amplifiers operating in the BF rack, which is equipped with the mains filter BF-35 or 70, has been approved for its conformity with the Electromagnetic Compatibility standards: • EN 55011, Group 1, Class A regarding the conducted and radiated radioelectric disturbances, The 400 VAC version of the SMT-BD1 amplifiers operating in the BF-400 rack, which is equipped with the mains filter F400-35 or 70, has been approved for its conformity with the Electromagnetic Compatibility standards: • EN 55011, Group 1, Class A regarding...
Open the catalog to page 8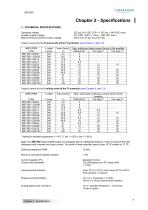
SMT-BD1 SERVO DRIVES & MOTION CONTROL Chapter 2 - Specifications | 1 - TECHNICAL SPECIFICATIONS Operating voltage Auxiliary supply voltage Motor terminal to terminal output voltage Output currents for the Fusing mode of the I2t protection (see Chapter 8, part 3.3) Output currents for the Limiting mode of the I2t protection (see Chapter 8, part 3.3) * Maximum ambient temperature = + 40° C, fan 1 = 56 l/s, fan 2 = 90 l/s Note: The SMT-BD1-X/Xr amplifier types are equipped with an additional heatsink in order to improve the heat dissipation and increase their rated current. The width of these amplifier...
Open the catalog to page 9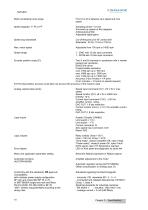
SMT-BD1 Motor accel/decel ramp range From 0 to 30 s between zero speed and max. speed Sampling period = 0,5 ms Anti-wind-up system of the integrator Antiresonance filter Adjustable digital gains Speed loop bandwidth Cut-off frequency for 45° phase shift Selectable : 50 Hz, 75 Hz or 100 Hz Speed range 1 : 2048 with 12 bits input command 1 : 32768 with 16 bits input command Encoder position output (*) Two A and B channels in quadrature with n marker pulse(s) per revolution. RS422 line driver Programmable resolution: max. 8192 ppr up to 900 rpm max. 4096 ppr up to 3600 rpm max. 1024 ppr up to 14000...
Open the catalog to page 10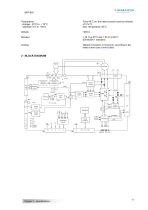
Temperature - storage - 20°C to + 70°C - operation 5°C to +40°C From 40°C on, the rated currents must be reduced of 3 %/°C. Max. temperature: 50°C Natural convection or forced air, according to the rated current (see current table) 2 - BLOCK DIAGRAM Resolver MOTOR -UP X1 5/9 X2 Resolver conversion Resolver oscillator Current monitor Analog input Power fault Analog input P err Vmes Vref IQ ID Imes Idc Current loops Vector control Speed loop Serial interface Selectable outputs Logic supplies
Open the catalog to page 11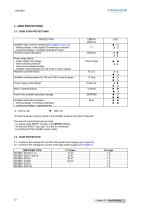
CINFRANOR 3 - MAIN PROTECTIONS 3.1 - DISPLAYED PROTECTIONS
Open the catalog to page 12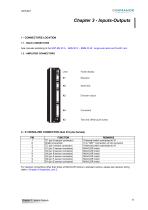
CINFRANOR SERVO DRIVES & MOTION CONTROL 1.1 - RACK CONNECTORS See manuals pertaining to the SMT-BM 20 A - BMM 05 F - BMM 05 AF single-axis racks and the BF rack. 1.2 - AMPLIFIER CONNECTORS Faults display Resolver Serial link Encoder output Test and Offset push button 2 - X1 RESOLVER CONNECTOR (Sub D 9 pins female) For resolver connections other than those of MAVILOR motors in standard version, please see resolver wiring table in Chapter 8 (Appendix), part 2.
Open the catalog to page 13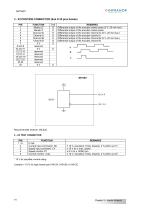
* 10 V for amplifier current rating Linearity = 10 % for logic board type 01612A, 01612B or 01612C.
Open the catalog to page 14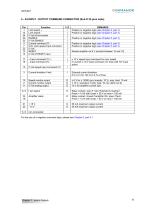
CINFRANOR 5 - X4 INPUT - OUTPUT COMMAND CONNECTOR (Sub D 25 pins male) Pin For the use of a negative command logic, please see Chapter 8, part 4.1.
Open the catalog to page 15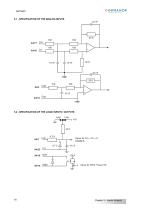
SMT-BD1 5.1 - SPECIFICATION OF THE ANALOG INPUTS 22 nF 5.2 - SPECIFICATION OF THE LOGIC INPUTS / OUTPUTS Log+ Same for IDYN, Power OK
Open the catalog to page 16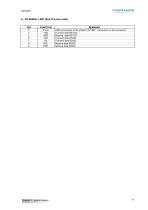
SERVO DRIVES & MOTION CONTROL 6 - X5 SERIAL LINK (Sub D 9 pins male)
Open the catalog to page 17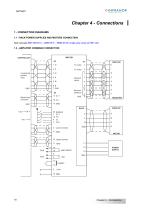
Chapter 4 - Connections 1 - CONNECTION DIAGRAMS 1.1 - RACK POWER SUPPLIES AND MOTORS CONNECTION See manuals SMT-BM 20 A – BMM 05 F – BMM 05 AF single-axis racks and BF rack. 1.2 - AMPLIFIER COMMAND CONNECTION Incremental position input Resolver signal Resolver reference Speed input command 11 GND MOTOR 10 Speed monitor L1 POWER SUPPLY
Open the catalog to page 18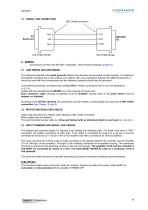
SMT-BD1 1.3 - SERIAL LINK CONNECTION 2 - WIRING according to CEI 801 and EN 55011 standards - See enclosed drawings (chapter 8) 2.1 - GND WIRING AND GROUNDING The reference potential is the earth (ground). Motors and resolvers are grounded via their housing. If a reference of potential is existing, like a main chassis or a cabinet, with a low impedance between the different elements, it should be used with short connections and this reference potential should also be grounded. Long reference potential connections are suitable ONLY if these connections have a very low impedance (< 0,1 Ω). Cables...
Open the catalog to page 19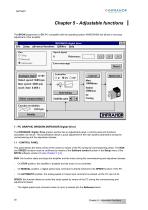
CINFRANOR Chapter 5 - Adjustable functions | The BPCW programme is IBM PC compatible with the operating system WINDOWS® and allows a very easy adjustment of the amplifier. INFRANOR digital drive File Setup Advanced functions Utilities Help Analogue input +/-10V Rated speed: 3600 rpm Max speed: 3600 rpm Accel, time: 0.000 s Offset compensation “Error message Encoder resolution [ INFRANOR 1 - PC GRAPHIC WINDOW (INFRANOR Digital Drive) The INFRANOR Digital Drive graphic window has an adjustment panel, a control panel and functions accessible via menus. This presentation allows a quick adjustment...
Open the catalog to page 20All Infranor Group catalogs and technical brochures
 XtrapulsPac_EN
4 Pages
 SMTBSi-2Tz_en_2.1
43 Pages
 PacSimBox_d_1
1 Page
 Pac-SF01_flyer_en_18.02
4 Pages
 Pac_User_1.2.1.218
253 Pages
 Pac_Templates_en_1.9
27 Pages
 Pac_STO_Installation_en_2.2
13 Pages
 Pac_SF01_operating_en_1.6
63 Pages
 Pac_SF01_EN
4 Pages
 Pac_Installation_en_2.23
82 Pages
 Pac_flyer_en_17.12
4 Pages
 Option_CT_EMF
6 Pages
 MOVINOR_LH055_LH086_LH097_LH142
23 Pages
 ma_series
6 Pages
 GemSafeTorqueOff_en_1.1
12 Pages
 CD1pm_e_1.2(old)
18 Pages
 CD1pInst_e_7.2(old)
35 Pages
 CD1kInst_e_4.1(old)
40 Pages
 CD1k_CANopenProtocol_e_1.3(old)
86 Pages
 CD1a_e_7.1(old)
45 Pages
 Catalogue gamme SMT-BD1
11 Pages
 BM20A(F)v3_0
20 Pages
 BM20A(D)v3_0
20 Pages
 BF400(GB)v2_2
21 Pages
 BF400(D)v2_2
21 Pages
 BF230(GB)v2_0
23 Pages
 BF230(F)v2_0
23 Pages
 BD2m_e_2.2
69 Pages
 BD2m(GB)2.0
70 Pages
 BD2_e_3.2
53 Pages
 BD2(GB)3.1
53 Pages
 BD2(D)3.1
54 Pages
 Movinor_LH_e
4 Pages
 ma_series
6 Pages
 BD1t(GB)3.1
81 Pages
 BD1t(F)3.0
85 Pages
 BD1pInst(GB)3.0
25 Pages
 BD1pInst(F)3.0
23 Pages
 BD1pInst(D)3.0
24 Pages
 BD1pCD1pUse_e_2.4
57 Pages
 BD1m(GB)5.0
58 Pages
 BD1m(F)5.0
57 Pages
 BD1m(D)v3_3
64 Pages
 BD1k(GB)2.1
35 Pages
 BD1k(F)2.1
36 Pages
 BD1j(GB)v2_41
19 Pages
 BD1j(F)v2_4
21 Pages
 BD1i(GB)v2_21
23 Pages
 BD1i(F)v2_2
27 Pages
 BD1h(F)3.0
65 Pages
 BD1h(D)3.0
59 Pages
 BD1g(GB)v3_0
28 Pages
 BD1g(F)v3_0
28 Pages
 BD1a400(GB)v2_3
43 Pages
 BD1a400(F)v2_3
44 Pages
 BD1a400(D)v2_3
45 Pages
 BD1(GB)7.1_noPW
45 Pages
 BD1(F)7.1_noPW
47 Pages
 BD1(F)7.1
47 Pages
 BD1(D)7.1
45 Pages
 BD1 Katalog
11 Pages
 Easy_User_5.0.1.60.2
190 Pages
 01ma_smv_e_01953
40 Pages
 PacHP-SF_Flyer_en_23.06
4 Pages
 IRD_User_Manual_en_1.2.XX.54.rev_b
216 Pages
 PacHP_User_en_1.2.8.100.b
280 Pages
 PacHP_SF02_operating_en_1.6
103 Pages
 PacHP_SF01_operating_en_2.0
63 Pages
 PacHP_Installation_en_2.9
91 Pages
 PacHP_Series_Brochure
8 Pages
 PacHP_Flyer_us_20.10
4 Pages
 IRD_Installation_en_1.5
42 Pages
 Easy_STO_en_1.4
14 Pages
 Easy_DB_STO_en_1.2
14 Pages
 Easy_DB_Installation_en_1.4
36 Pages
 CD1pmUser_en_4.2
55 Pages
 CD1pmInst_en_8.15
40 Pages
 CD1k_CANopenProtocol_en_2.10.1.1
108 Pages
 CD1pm_ProfibusProtocol_en_1.5
50 Pages
 CD1kUser_en_2.3
26 Pages
 CD1a_en_8.17
62 Pages
 CD1kInst_en_5.16
46 Pages
 CD1_STO_en_1.8
16 Pages
 CD1_flyer_en_14.09
4 Pages
 Braking_Resistors_en_1.5
10 Pages
 XtracontrolDC2_EN
4 Pages
 Flyer_VisiTouchCNC_EN_V1.1-1
2 Pages
 XtraforsWashdown_EN-2024
2 Pages
 DataSheet_CybIO_CNC_V1.0
6 Pages
 XtraforsPrime_EN-2024
2 Pages
 XtraforsMSS_EN
4 Pages
 XtraforsMSA_EN_2024
2 Pages
 XtraforsEx_EN-2024
2 Pages
 XtraforsBR_EN-2024
2 Pages
 XtraforsBL_EN-2024
2 Pages
 XtraforsBC-ed01-vs3
4 Pages
 Manual_XtraforsPrime
46 Pages
 Drawing_1
1 Page
 Datasheet_MSS
5 Pages
 Datasheet_2
2 Pages
 Datasheet_1
4 Pages
 BLSBLT_series
2 Pages
 BL220221
2 Pages
 BL270
2 Pages
 BL190
2 Pages
 bl100_series
6 Pages
 bl40_series
6 Pages
 BL30
2 Pages
 2019-01_XtraforsFP-DSL_FR
4 Pages
 Movinor_T_EN
4 Pages
 Movinor_N_EN
4 Pages
 Movinor_Low_Voltage_EN
4 Pages
 Manual Movinor T 03-2026
46 Pages
 Manual Movinor N 03-2026
63 Pages
 XtrapulsEasy™ AC servo-drive
4 Pages
 XtrapulsCD1 AC servo-drives
4 Pages
 CybIO
6 Pages
 AC SERVOMOTORS
2 Pages
 Movinor® N AC Servomotors
4 Pages






Archived catalogs
 AN_CD1ak_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1ak_SinCosTracks_e_1.0
7 Pages
 AN_CD1pm_AbsoluteEncoder_en_2.0
10 Pages
 AN_CD1pm_SinCosTracks_e_1.0
7 Pages
 AN_DC_bus_interfacing_en_1.3
5 Pages
 CD1_EC_conformity_24.05
1 Page
 CD1_STO_conformity_19.02
2 Pages
 EtherCAT Interface_en_1.3
20 Pages
 Easy_EC_Conformity_24_10
1 Page
 GDPS_EC_conformity_24.07
1 Page
 IRD_EC_Conformity_25.03
1 Page
 PacHP_TÜV_certificate_25.07
2 Pages
 BD1c(F)v2_01
19 Pages
 BD1c(GB)v2_01
19 Pages
 BD1d(F)v2_01
25 Pages
 BD1d(GB)v2_01
25 Pages
 BD1e(F)v2_01
22 Pages
 BD1f(F)v2_01
17 Pages
 BD1f(GB)v2_01
18 Pages
 Pac_EC_conformity_25.04
1 Page




















