
- Catalogs
- Imao Corporation
- Robot Integration Solutions

- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
Robot Integration Solutions
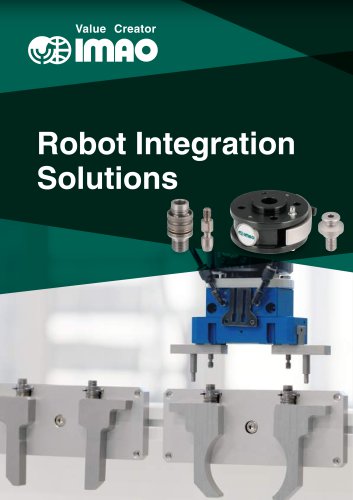
Robot Integration Solutions
This document provides comprehensive technical specifications and installation instructions for components used in robot integration solutions, focusing on MotionAct Finger Changers and related parts such as clamping pins, retaining pins, support pins, and mounting plates for COBOTTA.
- Materials: Components are primarily made from stainless steel types SUS303, SUS630, SUS440C, and SUS304WPB, each offering unique properties like precipitation hardening and quenching. Some components also use aluminum alloy A5052, with treatments for durability.
- Part Numbers: Specific part numbers are provided for identification, such as QMCF0411-15-SUS for MotionAct Finger Changers, with detailed dimensions including diameter, thread size, length, and weight.
- Finger Change Process: A step-by-step guide for changing gripper fingers using the MotionAct Finger Changer is provided, highlighting the simplicity of the operation through robot arm movements.
- Installation Instructions: Instructions for both standard and recessed mounting options are included, with specific dimensions for mounting holes and support pin placements.
- Heat Resistance and Load Capacity: Specifications include heat-resistant temperatures and allowable tensile and load capacities for different part numbers.
- Positioning Repeatability: Standard positioning offers a repeatability of ±0.2 mm, while precision positioning offers ±0.03 mm. Tool changers offer a repeatability of ±0.05 mm.
- Operating Temperature: The maximum operating temperature is 70°C, with a minimum of 0°C.
- Guiding Features: Guide pins or other guiding features are recommended for smoother operation to maintain alignment during finger attachment or detachment.
- Magnet Use: For vertical orientation, it is recommended to use a magnet to hold the finger in place for stability.
Examples include gripper finger changes for machine tending and laboratory applications, such as handling sample containers and electric pipettes.
- Compatibility: Compatibility with COBOTTA and ISO robot flanges is specified, with a note on the need for customer-supplied mounting plates for certain models.
- Safety Features: Safety locks are included to prevent accidental release, emphasizing the importance of using the correct mounting interface and clamping force.
- Space-Saving Design: Manual tool changers are designed for compactness and ease of use, featuring one-touch operation and secure pin clamping.
- Color differences due to hardening treatment do not affect the product's function or quality.
- COBOTTA is a registered trademark of DENSO WAVE INCORPORATED.
Catalog excerpts
Value Creator Robot Integration Solutions
Open the catalog to page 1
MotionAct Finger Changers MOTIONACT FINGER CHANGERS CLAMPING PINS SUPPORT PINS RETAINING PINS MOUNTING PLATES FOR COBOTTA ONE-TOUCH TOOL CHANGERS CLAMPING PINS One-Touch Tool Changers
Open the catalog to page 2
Value Creator
Open the catalog to page 3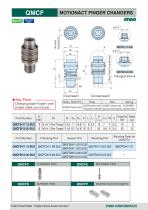
MOTIONACT FINGER CHANGERS ★ Key Point ->.QMCFS SUPPORT PINS QMCFP MOUNTING PLATES FOR COBOTTA Change gripper fingers with simple robot arm motion. v_L____/ CLAMPING PINS RETAINING PINS
Open the catalog to page 4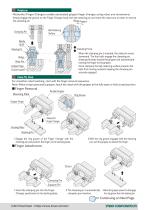
Feature ・MotionAct Finger Changers enable automated gripper finger changes using robot arm movements. ・Simply engage the groove on the Finger Changer body with the retaining pin and move the robot arm to insert or remove Wedge Angleθ the clamping pin. Ball-Retaining Surface Body Ball Clamping Force When the clamping pin is inserted, the slide pin moves downward. The four balls engage the clamping pin, drawing the body toward the gripper and automatically locking the finger to the gripper. Once clamped, the ball-retaining surface prevents the balls from moving outward, keeping the clamping pin...
Open the catalog to page 5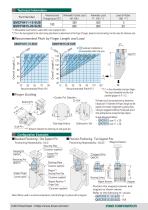
Part Number *) Allowable load when used with one support pin. **) This is the load applied to the robot during attachment or detachment of the Finger Changer, based on internal testing. Use this value for reference only. I Recommended Pitch by Finger Length and Load I Finger Guiding The finger may tilt during attachment or detachment. A larger pitch (Pi)between the Finger Changer and the support pin increases misalignment caused by tilting, making pin engagement difficult. Provide guide pins or other guiding features to keep the finger aligned. Guide Required When: Configuration Examples ■ Standard...
Open the catalog to page 6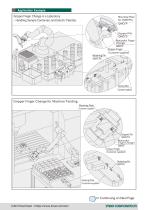
Application Example Gripper Finger Change in a Laboratory – Handling Sample Containers and Electric Pipettes Mounting Plate for COBOTTA QMCFP MotionAct Finger Changer QMCF Gripper Finger (Customer-supplied) Docking Plate (Customer-supplied) Gripper Finger Change for Machine Tending Mounting Plate (Customer-supplied) Support Pin QMCFS MotionAct Finger Changer QMCF Gripper Finger (Customer-supplied) Docking Plate (Customer-supplied) Continuing on Next Page CAD Download : https:
Open the catalog to page 7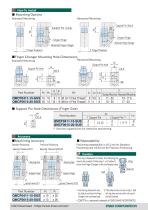
How To Install■ Mounting Options Standard Mounting Recessed Mounting ■ Finger Changer Mounting Hole Dimensions Standard Mounting Recessed Mounting ■ Support Pin Hole Dimensions (Finger Side) d2 Part Number *) Use two support pins for precision positioning. Positioning repeatability is ±0.2 mm for Standard Positioning and ±0.03 mm for Precision Positioning. ■ Machining Accuracy Standard Positioning Precision Positioning ■^Mounting Plate '\Gripper Finger ^Mounting Plate If the ring is displaced as shown, the clamping pin cannot be inserted. Follow step 1 or 2 below to return the Finger Changer...
Open the catalog to page 8
Value Creator
Open the catalog to page 9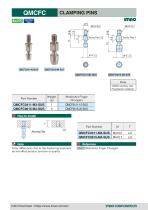
CLAMPING PINS Stainless Steel QMCFC0615-M4-SUS Body SUS630 stainless steel Precipitation hardened Part Number MotionAct Finger Changers Mounting Plate Note Color differences due to the hardening treatment do not affect product function or quality. Part Number Reference QMCF Motio
Open the catalog to page 10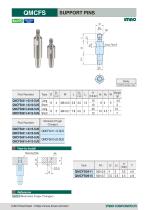
SUPPORT PINS imno Body Part Number Part Number
Open the catalog to page 11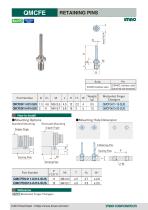
Part Number IQMCF I MotionAct Finger Changers
Open the catalog to page 12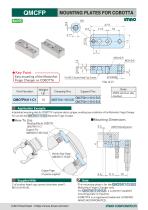
MOUNTING PLATES FOR COBOTTA RrmjJC w 11J ★ Key Point ->.Easy mounting of the MotionAct Finger Changer on COBOTTA ^ Part Number A5052 aluminum alloy Anodized A dedicated mounting plate for COBOTTA’s optional electric gripper, enabling easy installation of the MotionAct Finger Changer. For use with the I QMCF0411-15-SUS1 MotionAct Finger Changer. Mounting Plate for COBOTTA 2 of socket-head cap screws(stainless steel), -This mounting plate is for the I QMCF0411-15-SUSI M2.5X0.45-8L MotionAct Finger Changer only. For I QMCF0615-20-SUS1. a customer-supplied mounting plate is required. -COBOTTA is...
Open the catalog to page 13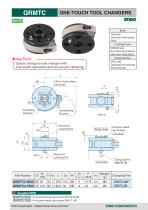
ONE-TOUCH TOOL CHANGERS ★ Key Point -. Space-saving manual changer with one-touch operation and secure pin clamping. ^ Electroless nickel plated Black_ Locking Lever SCM440 steel Quenched and tempered Electroless nickel plated Release Button S45C steel Quenched and tempered Nitrocarburized Part Number Supplied With ■|QRMTC2-6030|: 4 of socket-head cap screws, M5X0.8-30L ■|QRMTC2-7030|: 4 of socket-head cap screws, M6X1-30L
Open the catalog to page 14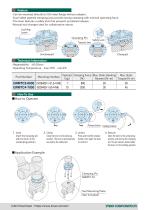
■Can be mounted directly to ISO robot flange without adapter. ■ Dual-sided tapered clamping jaws provide strong clamping with minimal operating force. ■The lever features a safety lock that prevents accidental release. ■Manual tool changer ideal for collaborative robots. Technical Information ■Repeatability ±0.05mm Insert the clamping pin with the lever in the unclamping position. Open the lever to the unclamping position and remove the clamping pin. The pin remains locked while the lever is in the holding position. Close the lever to the clamping Press and hold the release position. The lever...
Open the catalog to page 15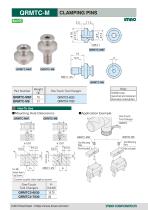
CLAMPING PINS RrmjJC w 11J imno Part Number ■ Mounting Hole Dimensions Tool Changers SCM440 steel Quenched and tempered Electroless nickel plated
Open the catalog to page 16All Imao Corporation catalogs and technical brochures
 Robot Integration Solutions
17 Pages
 Pneumatic Flex Locators
24 Pages
 One Touch Fasteners
160 Pages
 Vertical Clamps
20 Pages
 WORK SUPPORTS
31 Pages
 Bearing Guide Rollers
35 Pages
 Side Clamps
27 Pages
 NUTRUNNER CLAMPS
24 Pages
 Spring Clamps
25 Pages
 Modular Pull Clamping System
41 Pages
 PNEUMATIC CLAMPS
46 Pages
 Machinable Collet Clamps
48 Pages
 PNEUMATIC CLAMPING FASTENERS
16 Pages
 Function Knobs & Handles
22 Pages
 5-Axis Clamping Systems
15 Pages
 MECHANICAL LINEAR ACTUATORS
36 Pages
 Flex Locators
46 Pages
 Sliding Locks & Shaft Clamps
59 Pages
 ONE TOUCH CLAMPS
68 Pages
 TENSIONERS
45 Pages
 HANDWHEELS & HANDLES
31 Pages
 CLAMPING KNOBS
22 Pages
 LOCATING PARTS
15 Pages
 GRIPPERS
28 Pages
Archived catalogs
 SCREWS & NUTS
13 Pages