
- Catalogs
- Imao Corporation
- Robot Integration Solutions

- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
Robot Integration Solutions

Robot Integration Solutions
This document provides comprehensive technical specifications and installation guidelines for components used in robot integration solutions, focusing on MotionAct Finger Changers and related parts such as clamping pins, retaining pins, support pins, and mounting plates for COBOTTA robots.
- Materials: Components are primarily made from stainless steel (SUS303, SUS630, SUS440C, SUS304WPB) and aluminum alloy (A5052), with treatments like quenching, tempering, and anodizing for enhanced durability.
- Part Numbers: Specific part numbers are provided for various components, including QMCF for Finger Changers and QMCFE for Retaining Pins, with detailed dimensions such as diameter, thread size, length, and weight.
- Mounting Plates: Designed specifically for COBOTTA robots to facilitate easy installation.
- Finger Change Process: Detailed steps for changing gripper fingers using MotionAct Finger Changers, involving the use of retaining and clamping pins.
- Installation Instructions: Step-by-step guidance for finger removal and attachment, emphasizing starting with removal for smoother robot teaching.
- Mounting Options: Instructions for standard and recessed mounting, including necessary dimensions and hardware.
- Tool Changer Operation: A four-step process for using the One-Touch Tool Changer, highlighting the safety lock feature.
- Heat Resistance and Load Capacity: Specifications for heat-resistant temperatures and allowable tensile and load capacities for different parts.
- Positioning Repeatability: Standard positioning offers a repeatability of ±0.2 mm, precision positioning offers ±0.03 mm, and tool changer repeatability is ±0.05 mm.
- Operating Temperature: Maximum 70°C, minimum 0°C.
- Clamping Force and Payload: Specifications for different models, such as QRMTC2-6030 and QRMTC4-7030.
- Guiding Features: Use guide pins or other features to maintain alignment during finger attachment or detachment.
- Magnet Use: Recommended for vertical orientations to hold the finger in place.
Examples include gripper finger changes for machine tending and laboratory applications like handling sample containers and electric pipettes.
- Direct mounting to ISO robot flange without an adapter.
- Dual-sided tapered clamping jaws for strong clamping with minimal force.
- Manual tool changer suitable for collaborative robots.
- Color differences due to hardening treatment do not affect product function or quality.
- COBOTTA is a registered trademark of DENSO WAVE INCORPORATED.
- CAD downloads are available for further technical details.
Catalog excerpts

Value Creator Robot Integration Solutions
Open the catalog to page 1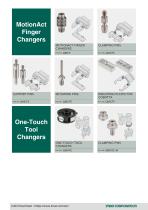
MotionAct Finger Changers MOTIONACT FINGER CHANGERS CLAMPING PINS SUPPORT PINS RETAINING PINS MOUNTING PLATES FOR COBOTTA ONE-TOUCH TOOL CHANGERS CLAMPING PINS One-Touch Tool Changers
Open the catalog to page 2
Value Creator
Open the catalog to page 3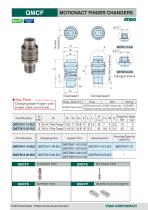
BSE MOTIONACT FINGER CHANGERS imno Change gripper fingers with simple robot arm motion. Part Number
Open the catalog to page 4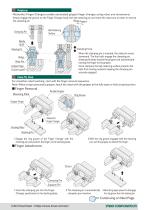
■ MotionAct Finger Changers enable automated gripper finger changes using robot arm movements. ■Simply engage the groove on the Finger Changer body with the retaining pin and move the robot arm to insert or remove the clamping pin. Body Ball Ring Slide Pin/^ Gripper Finger / (Customer-supplied)^^ Clamping Force When the clamping pin is inserted, the slide pin moves downward. The four balls engage the clamping pin, drawing the body toward the gripper and automatically locking the finger to the gripper. Once clamped, the ball-retaining surface prevents the balls from moving outward, keeping the...
Open the catalog to page 5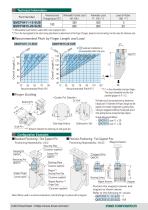
Part Number *) Allowable load when used with one support pin. **) This is the load applied to the robot during attachment or detachment of the Finger Changer, based on internal testing. Use this value for reference only. I Recommended Pitch by Finger Length and Load I Finger Guiding The finger may tilt during attachment or detachment. A larger pitch (Pi)between the Finger Changer and the support pin increases misalignment caused by tilting, making pin engagement difficult. Provide guide pins or other guiding features to keep the finger aligned. Guide Required When: Configuration Examples ■ Standard...
Open the catalog to page 6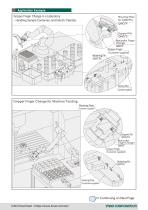
Application Example Gripper Finger Change in a Laboratory – Handling Sample Containers and Electric Pipettes Mounting Plate for COBOTTA QMCFP MotionAct Finger Changer QMCF Gripper Finger (Customer-supplied) Docking Plate (Customer-supplied) Gripper Finger Change for Machine Tending Mounting Plate (Customer-supplied) Support Pin QMCFS MotionAct Finger Changer QMCF Gripper Finger (Customer-supplied) Docking Plate (Customer-supplied) Continuing on Next Page CAD Download : https:
Open the catalog to page 7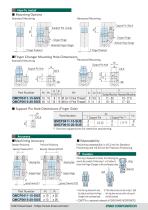
How To Install■ Mounting Options Standard Mounting Recessed Mounting ■ Finger Changer Mounting Hole Dimensions Standard Mounting Recessed Mounting ■ Support Pin Hole Dimensions (Finger Side) d2 Part Number *) Use two support pins for precision positioning. Positioning repeatability is ±0.2 mm for Standard Positioning and ±0.03 mm for Precision Positioning. ■ Machining Accuracy Standard Positioning Precision Positioning ■^Mounting Plate '\Gripper Finger ^Mounting Plate If the ring is displaced as shown, the clamping pin cannot be inserted. Follow step 1 or 2 below to return the Finger Changer...
Open the catalog to page 8
Value Creator
Open the catalog to page 9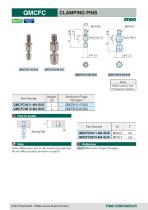
CLAMPING PINS SUS630 stainless steel Precipitation hardened Part Number Part Number QMCF | MotionAct Finger Changers
Open the catalog to page 10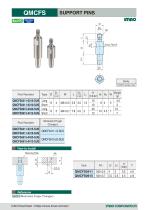
SUPPORT PINS imno Body Part Number Part Number
Open the catalog to page 11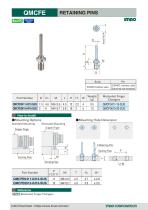
pocking Plate Part Number IQMCFI MotionAct Finger Changers
Open the catalog to page 12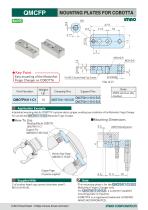
MOUNTING PLATES FOR COBOTTA ★ Key Point -vEasy mounting of the MotionAct Finger Changer on COBOTTA ^ Part Number A5052 aluminum alloy Anodized Application Example A dedicated mounting plate for COBOTTA’s optional electric gripper, enabling easy installation of the MotionAct Finger Changer. For use with the I QMCF0411-15-SUSI MotionAct Finger Changer. Mounting Plate for COBOTTA 2 of socket-head cap screws(stainless steel), -This mounting plate is for the I QMCF0411-15-SUSI M2.5X0.45-8L MotionAct Finger Changer only. For I QMCF0615-20-SUS, a customer-supplied mounting plate is required. - COBOTTA...
Open the catalog to page 13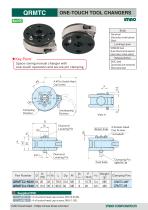
ONE-TOUCH TOOL CHANGERS ★Key Point -. Space-saving manual changer with one-touch operation and secure pin clamping. Electroless nickel plated Black_ Locking Lever SCM440 steel Quenched and tempered Electroless nickel plated Release Button S45C steel Quenched and tempered Nitrocarburized Part Number Supplied With ■ | QRMTC2-60301: 4 of socket-head cap screws, M5X0.8-30L ■|QRMTC2-7030|: 4 of socket-head cap screws, M6X1-30L
Open the catalog to page 14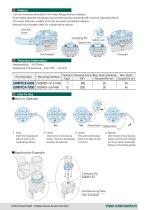
Feature ・Can be mounted directly to ISO robot flange without adapter. ・Dual-sided tapered clamping jaws provide strong clamping with minimal operating force. ・The lever features a safety lock that prevents accidental release. ・Manual tool changer ideal for collaborative robots. Locking Lever Clamping Pin Tapered Jaws Safety Lock Technical Information ・Repeatability ±0.05mm ・Operating Temperature max.70℃ Part Number Mounting Interface Payload Clamping Force Max. Static Bending Max. Static Moment(N・m) Torque(N・m) (kg) (N) Release Button Holding Position 1. Insert Insert the clamping pin with the...
Open the catalog to page 15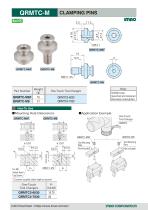
CLAMPING PINS imno Part Number Mounting Hole Dimensions Body SCM440 steel Quenched and tempered Electroless nickel plated lApplication Example For M6 Socket-Head Cap Screws *) Customer supplied, select length as required
Open the catalog to page 16All Imao Corporation catalogs and technical brochures
 Robot Integration Solutions
17 Pages
 Pneumatic Flex Locators
24 Pages
 One Touch Fasteners
160 Pages
 Vertical Clamps
20 Pages
 WORK SUPPORTS
31 Pages
 Bearing Guide Rollers
35 Pages
 Side Clamps
27 Pages
 NUTRUNNER CLAMPS
24 Pages
 Spring Clamps
25 Pages
 Modular Pull Clamping System
41 Pages
 PNEUMATIC CLAMPS
46 Pages
 Machinable Collet Clamps
48 Pages
 PNEUMATIC CLAMPING FASTENERS
16 Pages
 Function Knobs & Handles
22 Pages
 5-Axis Clamping Systems
15 Pages
 MECHANICAL LINEAR ACTUATORS
36 Pages
 Flex Locators
46 Pages
 Sliding Locks & Shaft Clamps
59 Pages
 ONE TOUCH CLAMPS
68 Pages
 TENSIONERS
45 Pages
 HANDWHEELS & HANDLES
31 Pages
 CLAMPING KNOBS
22 Pages
 LOCATING PARTS
15 Pages
 GRIPPERS
28 Pages
Archived catalogs
 SCREWS & NUTS
13 Pages