
- Catalogs
- Copley Controls
- XenusPLUS Compact EtherCAT XEC
- Products
- Catalogs
- News & Trends
- Exhibitions
XenusPLUS Compact EtherCAT XEC

XenusPLUS Compact EtherCAT XEC
- Models: XEC-230-09, XEC-230-12, XEC-230-15, each with different peak and continuous current ratings.
- Input Power: Operates on 100~240 Vac, single or three-phase, 47~63 Hz.
- Efficiency: Over 97% at 230 Vac.
- Dimensions: 7.54 x 4.55 x 2.13 inches (191.4 x 115.6 x 54.1 mm).
- Includes Cyclic Synchronous Position-Velocity-Torque, Profile Position-Velocity-Torque, Interpolated Position, Homing, Indexer, Point-to-Point, PVT, Camming, and Gearing.
- Supports CANopen over EtherCAT, ASCII and discrete I/O, Stepper commands, and ±10V position/velocity/torque commands.
- Compatible with incremental and absolute encoders, including SSI, EnDat, BiSS, and resolver options.
- Digital: 6 high-speed inputs, 4 opto-isolated inputs, 1 motor over-temp input.
- Analog: 1 reference input with 12-bit resolution.
- Safe Torque Off (STO) compliant with SIL 3, Category 3, PL d standards.
- EtherCAT and RS-232 interfaces.
- Includes protections against AC mains loss, HV over/undervoltage, drive over-temperature, short circuits, and feedback loss.
- Complies with IEC 61508, ISO 13849, IEC 61800, and RoHS directives.
- Regeneration capability with solid-state switch and internal regen resistor.
- Status indicators for drive and network status.
- Red/Solid: Transient fault condition; resumes operation once resolved.
- Green/Double-Blinking: STO circuit active; drive outputs in Safe-Torque-Off mode.
- Green/Slow-Blinking: Drive is okay but not enabled; will run when enabled.
- Green/Fast-Blinking: Limit switch active; drive moves in non-inhibited direction.
- Green/Solid: Drive is okay and enabled, ready to run.
- Includes short circuit, drive over-temperature, motor over-temperature, feedback error, following error, STO active, and over current.
- Device ID set using two 16-position rotary switches, range 0x00 to 0xFF.
- Configured via a three-wire, full-duplex DTE RS-232 port; baud rate 9600 to 115,200.
- STO function as per IEC 61800-5-2, using opto-couplers.
- Supports differential and single-ended inputs for position commands.
- Details on input voltages, pull-up/down resistances, and filter details.
- Includes opto-isolated inputs and outputs, MOSFET-based outputs with flyback diodes.
- Accepts ±10 Vdc differential signals with 12-bit resolution.
- Supports various encoder types and resolver connections for -R models.
- Outputs a three-phase PWM signal for motor phase connections.
- CE compliance and use of SELV or PELV power supplies for STO feature.
- Installation procedures, including mounting clearances and regeneration calculations.
- Emphasizes proper grounding and shielding for safety and compliance.
- Internal regeneration resistor for excess energy; table for energy absorption capacities.
- Table and chart for AC input currents and power factors.
- Dimensions in inches and millimeters; recommended mounting for multiple drives.
- Part numbers and descriptions for connectors and cables.
- Details revisions from initial release to updates on dimensions and approvals.
- Example order for a drive with resolver feedback and serial cable kit.
- EtherCAT is a registered trademark licensed by Beckhoff Automation GmbH.
- Specifications subject to change without notice.
Catalog excerpts
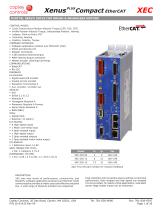
Xenus PLUSCompact EtherCAT DIGITAL SERVO DRIVE FOR BRUSH & BRUSHLESS MOTORS CONTROL MODES • Cyclic Synchronous Position-Velocity-Torque (CSP, CSV, CST) • Profile Position-Velocity-Torque, Interpolated Position, Homing • Indexer, Point-to-Point, PVT • Camming, Gearing • Position, Velocity, Torque COMMAND INTERFACE • CANopen application protocol over EtherCAT (CoE) • ASCII and discrete I/O • Stepper commands • ±10V position/velocity/torque • PWM velocity/torque command • Master encoder (Gearing/Camming) COMMUNICATIONS • EtherCAT • RS-232 FEEDBACK Incremental • Digital quad A/B encoder • Analog sin/cos encoder • Panasonic Incremental A • Aux. encoder / encoder out Absolute • SSI • EnDat 2.1 & 2.2 • Absolute A • Tamagawa Absolute A • Panasonic Absolute A Format • Sanyo Denki Absolute A • BiSS (B&C) Other • Digital Halls • Resolver (-R option) I/O DIGITAL • 6 High-speed inputs • 1 Motor over-temp input • 4 Opto-isolated inputs • 1 High-speed output • 3 Opto-isolated outputs • 1 Opto-isolated motor brake output I/O ANALOG • 1 Reference input, 12-bit SAFE TORQUE OFF (STO) • SIL 3, Category 3, PL d Model DIMENSIONS: IN [MM] XEC-230-09 • 7.54 x 4.55 x 2.13 [191.4 x 115.6 x 54.1] XEC-230-12 XEC-230-15 Add -R to the part number for resolver feedback DESCRIPTION XEC sets new levels of performance, connectivity, and flexibility. CANopen application protocol over EtherCAT (CoE) communication provides a widely used cost-effective industrial bus. A wide range of absolute encoders are supported. High resolution A/D converters ensure optimal current loop performance. Both isolated and high-speed non-isolated I/O are provided. For safety critical applications, redundant power stage enable inputs can be employed. Copley Controls, 20 Dan Road, Canton, MA 02021, USA Te
Open the catalog to page 1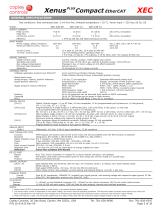
Xenus PLUSCompact EtherCAT GENERAL SPECIFICATIONS Test conditions: Wye connected load: 2 mH line-line. Ambient temperature = 25 °C. Power input = 230 Vac, 60 Hz, 1Ø MODEL OUTPUT CURRENT Peak Current Peak time Continuous current Efficiency INPUT POWER Mains voltage, phase, frequency Maximum Mains Current, (Note 2) Inrush Current +24 Vdc Control power Adc (Arms, sinusoidal) s Adc (Arms, sinusoidal) 100~240 100~240 100~240 Vac, ±10%, 1Ø or 3Ø, 47~63 Hz 4.7 9.4 11.8 Arms 1Ø 2.6 5.2 6.5 Arms 3Ø 1 5 A peak @ 120 VAC, 35 A peak @ 240 VAC +20~32 Vdc equired for operation (Note 3) R 7 .5 W (Typ, no...
Open the catalog to page 2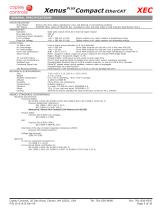
Xenus PLUSCompact EtherCAT GENERAL SPECIFICATIONS STATUS INDICATORS Drive Status Bicolor LED, drive status indicated by color, and blinking or non-blinking condition NET Status RUN/ERR LEDs, status of EtherCAT bus indicated by color and blink codes to CAN Indicator Specification 303-3 REGENERATION Operation Solid state switch drives 60 W internal regen resistor Bus Capacitance 940 µF Continuous Power Capability 20 W Cut-In Voltage +HV > 390 Vdc ±2 Vdc Regen output is on, regen resistor is dissipating energy Drop-Out Voltage +HV < 380 Vdc ±2 Vdc Regen output is off, regen resistor not dissipating...
Open the catalog to page 3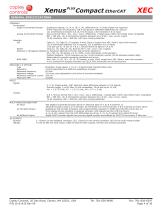
Xenus PLUSCompact EtherCAT GENERAL SPECIFICATIONS FEEDBACK Incremental: Digital Incremental Encoder Quadrature signals, (A, /A, B, /B, X, /X), differential (X, /X Index signals not required) 5 MHz maximum line frequency (20 M counts/sec), MAX3097 differential line receiver 121 Ω terminators between A & /A, B & /B inputs, 130 Ω between X & /X input Analog Incremental Encoder Sin/cos format (Sin+, Sin-, Cos+, Cos-), differential, 1 Vpeak-peak ±20%, ServoTube motor compatible BW > 300 kHz, 121 Ω terminating resistors between Sin+ & Sin-, Cos+ & Cos- inputs 12-bit resolution, BW > 300 kHz, with...
Open the catalog to page 4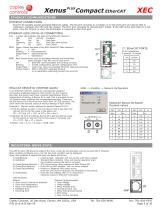
Xenus PLUSCompact EtherCAT ETHERCAT COMMUNICATIONS ETHERCAT CONNECTIONS Dual RJ-45 sockets accept standard Ethernet cables. The IN port connects to a master, or to the OUT port of a device that is ‘upstream’, between the XEC and the master. The OUT port connects to ‘downstream’ nodes. If the XEC is the last node on a network, only the IN port is used. No terminator is required on the OUT port. ETHERCAT LEDS (ON RJ-45 CONNECTORS) L/A A green LED indicates the state of the EtherCAT network: LED Link Activity Condition ON Yes No Port Open Flickering Yes Yes Port Open with activity Off No (N/A)...
Open the catalog to page 5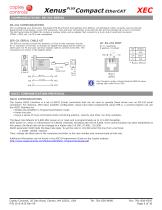
Xenus PLUSCompact EtherCAT COMMUNICATIONS: RS-232 SERIAL RS-232 COMMUNICATIONS XEC is configured via a three-wire, full-duplex DTE RS-232 port that operates from 9600 to 115,200 Baud, 8 bits, no parity, and one stop bit. Signal format is full-duplex, 3-wire, DTE using RxD, TxD, and Gnd. Connections to the XEC RS-232 port are through J8, an RJ-11 connector. The XEC Serial Cable Kit (SER-CK) contains a modular cable, and an adapter that connects to a 9-pin, Sub-D serial port connector (COM1, COM2, etc.) on PC’s and compatibles. SER-CK SERIAL CABLE KIT The SER-CK provides connectivity between...
Open the catalog to page 6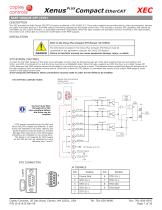
Xenus PLUSCompact EtherCAT SAFE TORQUE OFF (STO) DESCRIPTION The XEC provides the Safe Torque Off (STO) function as defined in IEC 61800-5-2. Three opto-couplers are provided which, when de-energized, prevent the upper and lower devices in the PWM outputs from being operated by the digital control core. This provides a positive OFF capability that cannot be overridden by the control firmware, or associated hardware components. When the opto-couplers are activated (current is flowing in the input diodes), the control core will be able to control the on/off state of the PWM outputs. INSTALLATION...
Open the catalog to page 7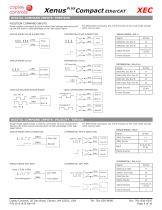
Xenus PLUSCompact EtherCAT DIGITAL COMMAND INPUTS: POSITION POSITION COMMAND INPUTS Digital position commands must be sourced from devices with active pullup and pull-down to take advantage of the high-speed inputs. SINGLE-ENDED PULSE & DIRECTION For differential commands, the A & B channels of the multi-mode encoder ports may be used. DIFFERENTIAL PULSE & DIRECTION [IN3] SINGLE-ENDED CU/CD Signal Ground Frame Ground DIFFERENTIAL CU/CD QUAD A/B ENCODER SINGLE-ENDED Frame Ground Signal Ground QUAD A/B ENCODER DIFFERENTIAL DIGITAL COMMAND INPUTS: VELOCITY, TORQUE Single-ended digital torque or...
Open the catalog to page 8All Copley Controls catalogs and technical brochures
 XenusPLUS Compact CANopen XPC
30 Pages
 Control Networks
8 Pages
 R-Series Guide
8 Pages
 Selection Guide
24 Pages
 Xenus R10
30 Pages
 Accelnet R23
24 Pages
 Accelnet R22
22 Pages
 Accelnet R21
24 Pages
 Accelnet R20
24 Pages
 Accelus Card Development Kit
6 Pages
 Accelus Card
8 Pages
 ASP-X2 Accelus Panel Dual
10 Pages
 Junus
10 Pages
 CAN-PCI-02
2 Pages
 CAN-IPM-01
8 Pages
 Bantam
18 Pages
 Bantam R30
18 Pages
 503
6 Pages
 Power Supply Subsystem
8 Pages
 Shunt Regulator
2 Pages
 Xenus PLUS 2-Axis CANopen
34 Pages
 Xenus RoHS PLUS CANopen
28 Pages
 Xenus PLUS 2-Axis EtherCAT
34 Pages
 Xenus PLUS EtherCAT
28 Pages
 Xenus Edge Filter
16 Pages
 Regen Resistors
24 Pages
 Xenus Micro
24 Pages
 Accelus Card Development Kit
6 Pages
 Accelus Card
8 Pages
 Accelus Panel
10 Pages
 Xenus XTL
30 Pages
 Accelnet Plus EtherCAT Panel
18 Pages
 Accelnet Micro Module and Kit
24 Pages
 Accelnet Micro Panel
24 Pages
 Accelnet Module Development Kit
8 Pages
 Accelnet Module
14 Pages
 Accelnet Panel ADP
24 Pages





- Digital I/O
- Analog I/O
- Servo-amplifier
- Motor controller
- DC servo-amplifier
- Fieldbus servo-drive
- DC motor controller
- Brushless servo drive
- AC servo-amplifier
- Stepper motor controller
- Communication interface card
- EtherCAT servo-amplifier
- Compact servo-amplifier
- CANopen servo-amplifier
- Digital servo-amplifier
- Industrial interface expansion card
- CANopen I/O
- Brushless motor control
- Stepper servo drive
- Digital input motor controller