
- Catalogs
- ComNav Technology Ltd.
- LS300 Laser Scanner (End of Life)


- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
LS300 Laser Scanner (End of Life)
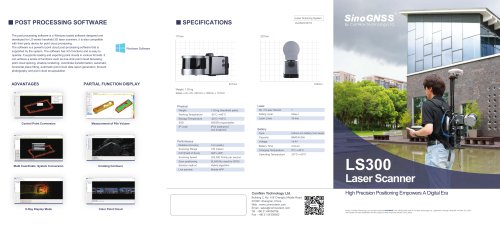
LS300 Laser Scanner (End of Life)
The LS300 Laser Scanning System by ComNav Technology Ltd. is a handheld 3D laser scanner utilizing SLAM technology for real-time positioning and mapping. It is designed for both indoor and outdoor use without relying on GNSS positioning, making it versatile for various environments.
- Weight: 1.35 kg
- Scanning Range: 120 meters
- Field of View: 360° x 285°
- Scanning Speed: 320,000 points per second
- Relative Accuracy: 1 cm
- IP Code: IP54 waterproof and dustproof
- Battery: Lithium-ion, 98Wh/6.8Ah, 4 hours runtime
The post-processing software is Windows-based, compatible with LS-series scanners and third-party devices. Key functions include:
- Point cloud denoising and splicing
- Shadow rendering and coordinate transformation
- Automatic horizontal plane fitting and data report generation
- Forward photography and point cloud encapsulation
- Control point conversion and multi-coordinate system conversion
- X-Ray display mode
- Measurement of pile volume and creating contours
- Color point cloud capabilities
The LS300 offers excellent performance with a rotating laser sensor probe, supporting a large field of scan and high point accuracy. It is suitable for applications in smart city digitization, agriculture, forestry, geology, and surveying. The system supports diverse platforms and external ports for collaborative work.
- Real-time preview via mobile app
- Hot-swappable batteries for uninterrupted operation
- Anchor point process for high-precision data adjustment
- Enhanced visual experience with improved point cloud color functions
ComNav Technology Ltd., Building 2, No. 618 Chengliu Middle Road, 201801 Shanghai, China.
Web: www.comnavtech.com
Email: [email protected]
Tel: +86 21 64056796
Catalog excerpts
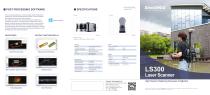
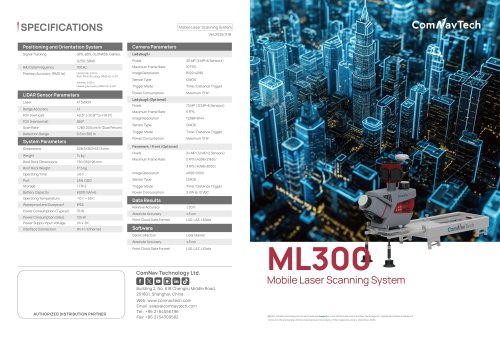
■ SPECIFICATIONS Laser Scanning System The post processing software is a Windows based software designed and developed for LS-series handheld 3D laser scanners, it is also compatible with third-party device for point cloud processing. The software is a powerful point cloud post-processing software that is supported by the system. The software has rich functions and is easy to operate. It supports loading and exporting point clouds in various formats. It can achieve a series of functions such as one-click point cloud denoising, point cloud splicing, shadow rendering, coordinate transformation, automatic horizontal plane fitting, automatic point cloud data report generation, forward photography and point cloud encapsulation. Windows Software ADVANTAGES PARTIAL FUNCTION DISPLAY 227mm 105mm Control Point Conversion Measurement of Pile Volume Multi Coordinate System Conversion Physical Weight 1.35 kg (handhold parts) Relative Accuracy 1cm (peak) Scanning Range 120 meters Scanning Speed 320,000 Points per second Scan positioning SLAM (No need for GPS) Solution method Hybrid algorithm Live preview Mobile APP Safety Level Class I Type Lithium ion battery (hot swap) Battery Time 4 hours X-Ray Display Mode Color Point Cloud ComNav Technology Ltd. Building 2, No. 618 Chengliu Middle Road, Email : [email protected] High Precision Positioning Empowers A Digital Era ©2023, ComNav Technology Ltd. All rights reserved. SinoGNSS* is the official trade mark of ComNav Technology Ltd., registered in People’s Republic of China, EU, USA and Canada. All other trademarks are the property of their respective owners. (July, 2023).
Open the catalog to page 1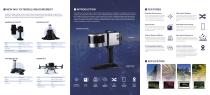
NEW WAY OF MOBILE MEASUREMENT Capable of multiple scanning modes, the LS300 Laser Scanning System is also suitable for a wide variety of applications. The GNSS module can be switched quickly, enabling scanning of the WGS84 coordinate systems point clouds, with absolute accuracy of about 2 cm with mapping software. The LS300 Laser Scanning System uses SLAM technology (simultaneous localization and mapping), which is real-time positioning and mapping technology. It does not rely on GNSS positioning, and performs self positioning and incremental 3D mapping in unknown environments, including indoors...
Open the catalog to page 2All ComNav Technology Ltd. catalogs and technical brochures
 A100 Series Smart Antenna
2 Pages
 N2 Palm GNSS Receiver
2 Pages
 N3 IMU GNSS Receiver
2 Pages
 EN-LiAir H600
2 Pages
 K706 GNSS Module
2 Pages
 SinoGNSS Jupiter Laser RTK
2 Pages
 K823 GNSS Module
2 Pages
 AT410 GNSS Antenna
2 Pages
 M900 GNSS Receiver
2 Pages
 U70 Datalink Module
1 Page
 Sinognss P6H Hanheld
2 Pages
 M100X GNSS Receiver
2 Pages
Archived catalogs
 AT500 Chock Ring Antenna
1 Page
 R200 Data Collector
2 Pages
 K700 GNSS Board
2 Pages
 K803 GNSS Module
2 Pages
 K705 GNSS OEM Board
2 Pages
 K708 GNSS OEM Board
2 Pages
 K706 GNSS OEM Board
2 Pages
 AT160 Helix Antenna
1 Page
 K726 GNSS OEM Board
2 Pages
 U50 Data Link Module
1 Page
 T300 Plus GNSS Receiver
2 Pages
 T300 GNSS Receiver_K8
2 Pages
 TS-C100 Total Station
2 Pages
 TS-C200 Total Station
2 Pages
 A100 Series Smart Antenna
2 Pages
 T20 Palm GNSS Receiver
2 Pages
 T30 IMU GNSS Receiver
2 Pages
 Z30 Portable GNSS Receiver
2 Pages
 LS300 Laser Scanning
2 Pages
 Venus Laser RTK
2 Pages
 Mars Laser RTK
2 Pages
 Mars Pro Laser RTK
2 Pages
 N2 GNSS Palm Receiver
2 Pages
 R60 Data Collector
2 Pages
 P8 Tablet
2 Pages
 AT360 Geodetic Antenna
1 Page
 N3 IMU GNSS Receiver
2 Pages
 M300 Pro 2023 GNSS Receiver
2 Pages
 AT600 Chock Ring Antenna
1 Page
 LS600 Laser Scanner
2 Pages
 AT190 Helix Antenna
1 Page
 AT340 Geodetic Antenna
1 Page
 R550 Data Collector
2 Pages
 R500 Data Collector
2 Pages
 G100 GNSS Receiver
2 Pages
 G200 GNSS Receiver
2 Pages
 M300 Plus GNSS Receiver
2 Pages
 T30 GNSS Receiver
2 Pages
 M300 Pro II GNSS Receiver
2 Pages
 T30 Surveying Solution
4 Pages
 T30 IMU Surveying Solution
4 Pages
 T300 Plus for UAV Solution
4 Pages
 CDL5 External Data Link
2 Pages
 M10 Mini GNSS Receiver
2 Pages
 T300 Plus GNSS Receiver
2 Pages
 P300 Series
2 Pages
 N5 IMU GNSS Receiver
2 Pages

- Management software solution
- Real-time software
- Computer-aided design software
- Cloud-based software
- Touch screen tablet
- Wireless tablet
- Design software solution
- Monitoring software solution
- Rugged tablet
- Interface software
- Bluetooth tablet
- WiFi tablet
- GNSS tablet
- Touch screen HMI
- Automated software
- Industrial tablet
- Windows tablet
- Network software
- GPS tablet