
GVD Series
GVD Series
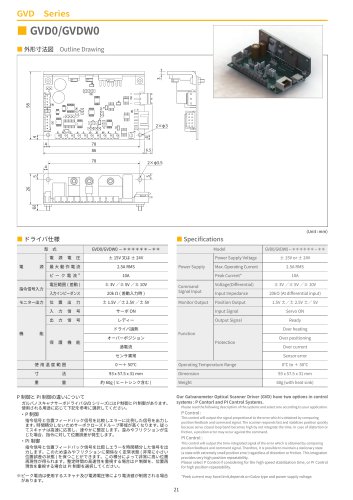
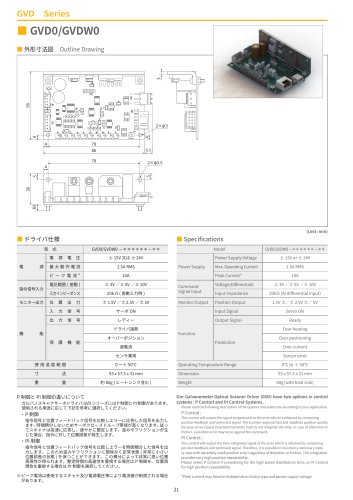
The document outlines the specifications for the GVD0/GVDW0 model of galvanometer optical scanner drivers. Key specifications include:
- Power Supply Voltage: ± 15V or ± 24V
- Max. Operating Current: 2.5A RMS
- Peak Current: 10A (may be limited by scanner type and power supply voltage)
- Command Signal Input Voltage Range: ± 3V, ± 5V, or ± 10V (differential)
- Input Impedance: 20kΩ (differential input)
- Monitor Output Position Output: ± 1.5V, ± 2.5V, or ± 5V
- Operating Temperature Range: 0℃ to +50℃
- Dimensions: 93 x 57.5 x 31 mm
- Weight: Approximately 60g (including heat sink)
- Input Signal: Servo ON
- Output Signal: Ready
- Protection Features: Overheating, over-positioning, over-current, and sensor error
The GVD series offers two control systems: P Control and PI Control.
- P Control: Outputs a signal proportional to the error between the command signal and position feedback. It provides fast response and stabilization but may result in position errors due to distortion or friction.
- PI Control: Outputs a time-integrated signal of the error, maintaining a stationary state with minimal position error, regardless of distortion or friction. It offers high position repeatability.
Catalog excerpts
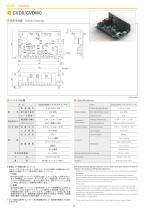
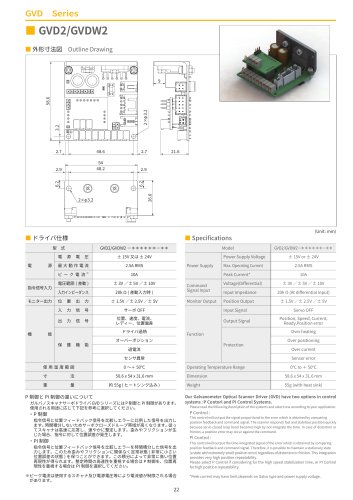
Outline Drawing 指令信号入力 モニター出力 Power Supply Command Signal Input Monitor Output ガルバノスキャナサーボドライバ GVD シリーズには P 制御と PI 制御があります。 使用される用途に応じて下記を参考に選択してください。 Peak Current* Voltage(Differential) Input Impedance Position Output Input Signal Operating Temperature Range Dimension Weight 20kΩ (At differential input) 1.5V ±/± 2.5V ±/ 5V Servo ON Ready Over heating Over positioning Over current Sensor error 60g (with heat sink) Our Galvanometer Optical Scanner Driver (GVD) have two options in control systems : P Contorl and PI Control Systems. Please read the following description of the systems and select one according to your application. This control will output the signal proportional to the error which is obtained by comparing position feedback and command signal. The scanner responds fast and stabilizes position quickly because servo closed loop band becomes high by not integrate the time. In case of distortion or friction, a position error may occur against the command. 指令信号と位置フィードバック信号を比較しエラーに比例した信号を出力し ます。時間積分しないためサーボクローズドループ帯域が高くなります。従っ てスキャナは高速に応答し、速やかに整定します。歪みやフリクションが生 じた場合、指令に対して位置誤差が発生します。 This control will output the time-integrate
Open the catalog to page 1All CITIZEN CHIBA PRECISION CO., LTD. catalogs and technical brochures
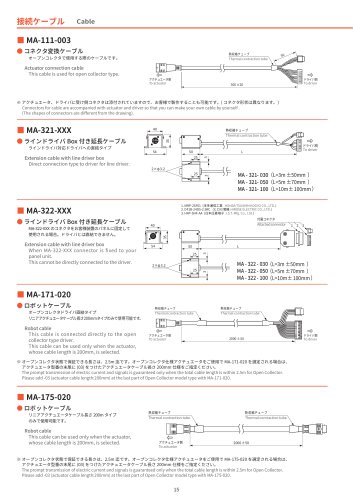 Connection cable
1 Page
 GVD2/GVDW2
1 Page
 GVD0/GVDW0
1 Page
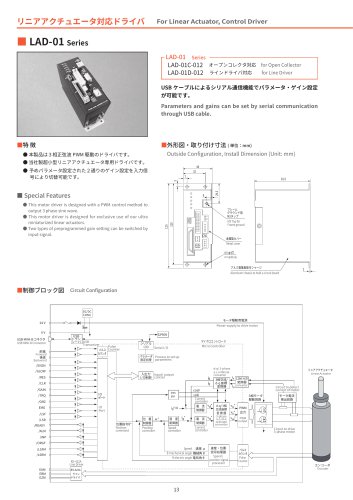 LAD-01 Series
2 Pages
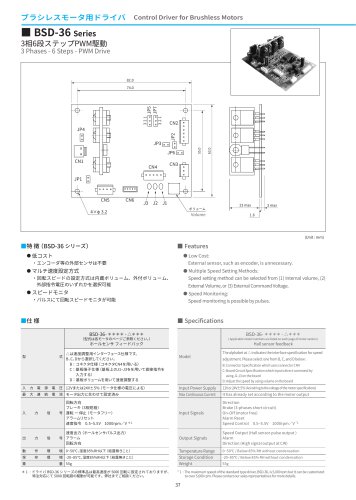 BSD-36 Series
2 Pages
 TSD-04-060
2 Pages
 Planetary Gearheads
3 Pages
 Linear Actuators
24 Pages
 Galvanometer Optical Scanners
28 Pages
 Coreless DC Motors
44 Pages
 Brushless Motors 2026
44 Pages
 Tachometer Generator
1 Page
 Miniaturized AC Servomotors
16 Pages
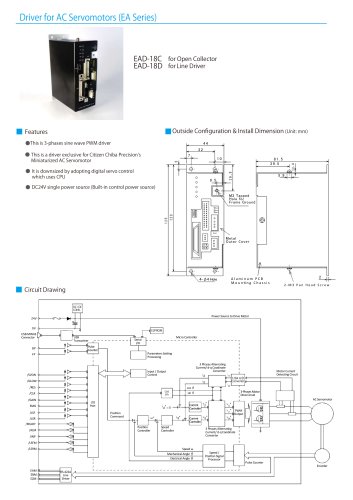


Archived catalogs
 Galvanometer Optical Scanner
24 Pages
 Brushless Motor
36 Pages
 Linear Actuator
20 Pages
 Coreless DC Servo Motor
36 Pages
 Planetary Gearheads
5 Pages
- CITIZEN electric motor
- CITIZEN DC motor
- CITIZEN synchronous motor
- CITIZEN actuator
- Multipole motor
- Angular encoder
- CITIZEN linear actuator
- CITIZEN planetary gear reducer
- CITIZEN coaxial gear reducer
- CITIZEN electric actuator
- Incremental encoder
- Electromotor for industrial applications
- CITIZEN brushless motor
- CITIZEN 24 V motor
- CITIZEN servomotor
- Incremental rotary encoder
- CITIZEN compact gear reducer
- Compact electromotor
- 2-pole motor
- CITIZEN 12 V motor