
- Catalogs
- CDS Cam Driven Systems
- MCR pick & place unit


- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
MCR pick & place unit

MCR pick & place unit
The MCR series is engineered for industrial automation, providing rapid and precise positioning. It includes programmable pick & place systems with rotational and lifting functions, powered by two servo motors for adaptable motion needs. Key advantages are high precision, swift cycle rates, and dependable 24/7 operation.
- Freely programmable positioning
- Maximum Payload: 20 kg
- Maximum vertical stroke: 100 mm
- Multiturn rotation
- Maximum pressing force: 1000 N at 200 mm
- Operates in any mounting position
- Fully programmable for flexible positioning
- Handles heavy parts with fast cycle rates
- Compact design suitable for clean rooms
- Simple mounting with main connection plate
- High mechanical rigidity and smooth operation
- Leakproof and maintenance-free with sealed oil bath components
- Calculate application inertia: JAPPL = mAPPL · r2APPL + JMCR
- Calculate payload: WMOV = WAPPL + WMCR
- Use diagrams to determine minimum rotation and lifting times
- Select or create a motion cycle using calculated times
The MCR C021/2 is a compact and adaptable automation solution for industries like food, automotive, pharma, and medical. It offers a maximum pressing force of 100 kg, can manage payloads up to 20 kg in one second, and is designed for high-speed operations with precision and cleanliness suitable for clean room standards.
The document provides a detailed guide for calculating application inertia and the weight to be mobilized. It includes formulas for inertia (JAPPL = mAPPL · r2APPL + JMCR) and weight (WMOV = WAPPL + WMCR), with specific values for internal inertia (JMCR = 0.01 kg m2) and internal weight (WMCR = 5.6 kg). It also explains how to use diagrams to determine movement times based on rotation angle and height.
Two essential diagrams are included: Diagram 1 for rotation, illustrating the relationship between rotation angle (ß) and inertia (JAPPL) to determine movement time (tß), and Diagram 2 for vertical stroke, showing the relationship between height (h) and payload (WMOV) to determine movement time (th).
The MCR C021/2 features an aluminum housing with components in an oil bath for lifetime lubrication, a gearbox ratio of 1/16, and servomotors for both rotation and vertical stroke. It includes mounting and dowel holes for installation.
The document provides examples of applications, highlighting the product's versatility in various industrial settings. It emphasizes the global presence of the company, with offices in the USA, China, Germany, and India, and mentions the Bettinelli Group's specialization in high precision mechanical components.
Catalog excerpts

PICK & PLACE UNIT MANIPOLATORE ELETTRONICO ROTANTE ELEKTRONISCHES DREHHANDHABUNGSGERÄT MANIPULATEUR ÉLECTRONIQUE ROTATIF MANIPULADOR ELECTRÓNICO ROTATIVO
Open the catalog to page 1
This catalogue cancels and replaces any preceding issue or revision. The data provided in the catalogue are not binding; in line with our commitment to on-going product improvement, we reserve the right to make changes without prior notice. The technical data not present in this catalog are available from our technical office. When in doubt, you are welcome to download the latest up-to-date version available on our web site: www.cdsindexers.com Importante Questo catalogo annulla e sostituisce ogni precedente edizione o revisione. I dati esposti nel catalogo non sono impegnativi e ci riserviamo...
Open the catalog to page 2
Caratteristiche tecniche Technische Eigenschaften Dimensioni d’ingombro Außenmaße
Open the catalog to page 3
The new MCR series of servo pick & place are designed for industrial automation applications requiring fast and accurate positioning. La nuova serie di pick&place MCR è progettata per coprire le esigenze di movimentazione e posizionamento veloci provenienti dall'automazione industriale. Die neue pick&place MCR Serie entspricht den Bedarf an schneller Bewegung und Positionierung in der Branche der industriellen Automation. MCR are programmable pick & place handling systems for automation processes where the output shaft rotates and lifts to properly manipulate the components. Il gruppo MCR è un...
Open the catalog to page 4
La nueva serie pick&place MCR está diseñada para satisfacer las necesidades de movilización y posicionamiento rápido de la automatización industrial. Le groupe MCR est un manipulateur programmable dont l’arbre de sortie du moteur effectue des courses linéaires et des mouvements rotatifs, afin de manutentionner différents types de pièces et/ou composants. El grupo MCR es un manipulador programable cuyo árbol de salida del movimiento realiza carreras lineales y movimientos rotativos para manipular diversos tipos de piezas y/o componentes. La nouvelle série de pick&place MCR est conçue pour répondre...
Open the catalog to page 5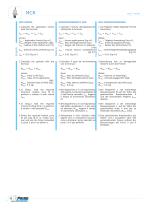
1. alculate the application inertia C with the formula: 1. alcolare l’inerzia dell’applicazione C utilizzando la formula: 1. ie Trägheit mittels folgender Formel D berechnen: JMCR: Internal inertia of MCR [kg m2] JMCR = 0.01 [kg m2] 2. alculate the payload with the C formula: where: JAPPL : Application Inertia [kg m2]; mAPPL:Weight of the application [kg]; rAPPL : Radius of the rotation arm [m] dove: JAPPL : Inerzia applicazione [kg m2]; mAPPL: Peso dell’applicazione [kg]; rAPPL : Raggio del braccio di rotazione [m] JMCR : Inerzia interna manipolatore [kg m2] JMCR = 0.01 [kg m2] Wobei: JAPPL...
Open the catalog to page 6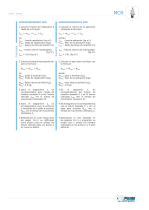
1. alculer l’inertie de l’application à C l’aide de la formule: 1. alcular la inercia de la aplicación C utilizando la fórmula: où: JAPPL : Inertie application [kg m2]; mAPPL: Poids de l’application [kg]; rAPPL : Rayon du bras de rotation [m] JMCR : Inertie interne manipulateur [kg m2] JMCR = 0.01 [kg m2] 2. alculer le poids à manutentionner C avec la formule: WMOV = WAPPL + WMCR donde: JAPPL : Inercia aplicación [kg m2]; mAPPL: Peso de la aplicación [kg]; rAPPL : Radio del brazo de rotación [m] JMCR : Inercia interna del manipulador [kg m2] JMCR = 0.01 [kg m2] 2. alcular el peso para movilizar...
Open the catalog to page 7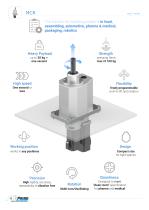
The solution for handling problems in food, assembling, automotive, pharma & medical, packaging, robotics Heavy Payload High speed freely programmable both in lift and rotation Working position Compact size for tight spaces High rigidity, accuracy, repeatability & vibration free Rotation Multi-turn/Oscillating Designed to meet "clean room" specification for pharma and medical
Open the catalog to page 8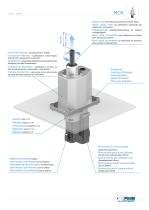
• Output shaft with surface treatment for smooth motion • Albero uscita moto con trattamento superficiale per un'estrema scorrevolezza Oberflächenbehandlung für extreme Leichtgängigkeit • Arbre sortie mouvement avec traitement de surface pour une douceur extrême • Árbol salida movimiento con tratamiento de superficie para un extremo deslizamiento Strength • Aluminum housing - All components in oil bath • Carcassa in alluminio - Lubrificazione a vita in bagno d'olio di tutti i componenti in movimento • Alugehäuse - Lebenslange Ölbadschmierung während der Bewegung von allen Komponenten - Lubrification...
Open the catalog to page 9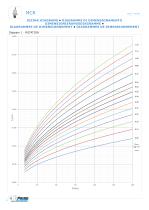
SIZING DIAGRAMS • DIAGRAMMI DI DIMENSIONAMENTO DIMENSIONIERUNGSDIAGRAMME • DIAGRAMMES DE DIMENSIONNEMENT • DIAGRAMMES DE DIMENSIONNEMENT Diagram 1 - ROTATION 0.800
Open the catalog to page 10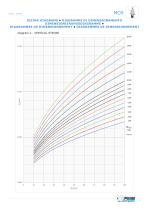
SIZING DIAGRAMS • DIAGRAMMI DI DIMENSIONAMENTO DIMENSIONIERUNGSDIAGRAMME • DIAGRAMMES DE DIMENSIONNEMENT • DIAGRAMMES DE DIMENSIONNEMENT Diagram 2 - VERTICAL STROKE 20.00
Open the catalog to page 11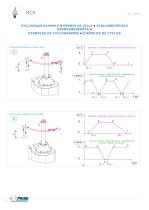
CYCLOGRAM EXAMPLE • ESEMPI DI CICLI • ZYKLUSBEISPIELE ÜBERGABEGERÄTE • EXEMPLES DE CYCLOGRAMME • EJEMPLOS DE CYCLOS CYCLE • CICLO • ZYKLUS • CYCLE • CICLO ROTATION - ROTAZIONE - ROTATION - ROTATION - ROTACIÓN CYCLE • CICLO • ZYKLUS • CYCLE • CICLO ROTATION - ROTAZIONE - ROTATION - ROTATION - ROTACIÓN VERTICAL STROKE - CORSA VERTICALE - HUBBEWEGUNG 1 MONTE ET BAISSE - ELEVACIÓN ROTATION - ROTAZIONE - ROTATION - ROTATION - ROTACIÓN VERTICAL STROKE - CORSA VERTICALE - HUBBEWEGUNG ß1-2 ß5-1 MONTE ET BAISSE - ELEVACIÓN ROTATION - ROTAZIONE - ROTATION - ROTATION - ROTACIÓN B CYCLE • CICLO • ZYKLUS...
Open the catalog to page 12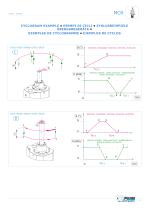
VERTICAL STROKE - CORSA VERTICALE - HUBBEWEGUNG MONTE ET BAISSE - ELEVACIÓN CYCLOGRAM EXAMPLE • ESEMPI DI CICLI • ZYKLUSBEISPIELE ÜBERGABEGERÄTE • 0 EXEMPLES DE CYCLOGRAMME • EJEMPLOS DE 4 CYCLOS 3 t h2-3 t h4-5 0 CYCLE • CICLO • ZYKLUS • CYCLE • CICLO ROTATION - ROTAZIONE - ROTATION - ROTATION - ROTACIÓN t ß1-2 VERTICAL STROKE - CORSA VERTICALE - HUBBEWEGUNG MONTE ET BAISSE - ELEVACIÓN CYCLE • CICLO • ZYKLUS • CYCLE • CICLO ROTATION - ROTAZIONE - ROTATION - ROTATION - ROTACIÓN VERTICAL STROKE - CORSA VERTICALE - HUBBEWEGUNG MONTE ET BAISSE - ELEVACIÓN
Open the catalog to page 13All CDS Cam Driven Systems catalogs and technical brochures
 HT Ring table
20 Pages
 IG-IGA Roller gear index drives
41 Pages
 TRP Index table
52 Pages
 IT Mechanical index tables
34 Pages
 TR Mechanical index tables
45 Pages
 MHP Rotary parts-handlers
23 Pages
 GT Technical Guide
43 Pages
 CR Cycloidal reducers
20 Pages
 TCR Cycloidal table
20 Pages
 CPC Chain pallet conveyors
52 Pages
 LA Linear actuator
24 Pages
 FTP Ring table
24 Pages
 FT Ring table
24 Pages
 EL Part Elevator
28 Pages
 Products brochure
25 Pages
 IP Parallel index drives
26 Pages
 ITP Index table
48 Pages
 LHP Linear parts-handlers
17 Pages
 CU Tool changer
20 Pages
 CPT Pallet changer
20 Pages
 MUL Linear tool magazine
8 Pages


- Rail conveyor
- Actuator
- Transport rail conveyor
- Belt conveyor
- Horizontal conveyor
- Conveying belt
- Conveyor for the food industry
- Turntable
- Chain conveyor
- Industrial conveyor belt
- Electric rotary table
- Work conveyor
- Manipulator for industrial applications
- Flush grid conveyor belt
- Food conveyor
- Modular conveyor
- Manipulator with gripping tool
- Rotary actuator
- Horizontal rotary table
- Modular conveyor belt