
- Catalogs
- ATI Industrial Automation
- Tooling & Production Robotic deburring : making choice

- Products
- Catalogs
- News & Trends
- Exhibitions
Tooling & Production Robotic deburring : making choice

Tooling & Production Robotic deburring : making choice
Robotic deburring and surface-finishing are crucial in lean manufacturing, particularly in aerospace, automotive, and shipbuilding industries. These systems offer cost savings and efficiency improvements over manual deburring, which poses health risks and higher costs.
Key Requirements for Successful Deburring
Effective deburring involves complete burr removal, smooth surfaces, and minimal parent material removal. While humans adapt to changing conditions, they lack consistency. Robots provide consistency but need adaptive tools for varying part tolerances and burr sizes.
Force Control Tools
Active and passive force control tools are essential. Active tools, like those from ATI Industrial Automation, adjust the robot's trajectory in real-time for higher accuracy. Passive tools adapt independently but are less precise.
Deburring as an Art and Science
Deburring requires precision similar to a jeweler's work, demanding dynamic adjustments in force, location, and speed. Automation is preferred due to human limitations in consistency and stamina.
Scientific Principles
The process depends on consistent media surface speed, contact pressure, and feedrate. Robotic systems often fail without feedback mechanisms to adapt to inconsistent parts and burrs.
Compliance in Deburring
Compliance maintains contact and cutting force, reducing variables to 'feed and speed.' Active systems offer high repeatability and accuracy but are costly. Passive systems are less expensive and suitable for loose tolerances.
Active Force Control Systems
These systems adjust cutting force in real-time using feedback, ideal for demanding surface requirements.
Passive Force Control Systems
These systems apply constant force without measuring cutting forces, suitable for consistent burrs but poor part tolerances.
Conclusion
The choice between active and passive force control systems depends on application requirements, part consistency, and surface finish demands. Active systems offer precision, while passive systems provide cost-effective solutions.
Pneumatic Passive Force Control Devices
These devices are unaffected by inertial loading and can be mounted on floors or robots. They are controlled with programmable pressure regulators to vary cutting force.
Types of Passive Compliant Tools
1. Linear Compliance: Allows deflection along one axis with constant contact force, ideal for cone cutters or cup brushes.
2. Radial Compliance: Allows 360º movement along a radius, suitable for radial brushes.
3. Rotational Compliance: Deflection about a fixed point along an arc, providing stiffness in the path direction.
4. Combination Tools: Combine axial and radial compliance, best for light-duty applications.
Conclusion
Robotic deburring of inconsistent or complex parts is challenging with rigid tools. The document emphasizes choosing the correct system based on application and desired results. Active systems are recommended for tight tolerances, while passive systems like VersaFinish or Flexdeburr are suitable for looser tolerances.
References
The document cites works by Shiakolas, McGillis, Alfonso, and Godwin, providing insights into robotic force control and industrial applications.
Catalog excerpts
production strategies
Open the catalog to page 1
Successful robotic deburring is really a matter of choices By Aaron Odham, application engineer, ATI Industrial Automation Robotic deburring and surface-finishing applications continue to grow in number as lean manufacturing techniques demand more from less. Automated surface finishing is a process that can be widely used in the manufacturing technology industry for a variety of applications ranging from aerospace to automotive to ship industry.1 Coupled with increased healthcare costs associated with maintaining dangerous manual deburring systems, these robotic deburring systems have a huge...
Open the catalog to page 2
demanded in most deburring or surfacefinishing applications today. And now the science Deburring, grinding, and surface finishing are basically quite simple. For a given material (assuming the material composition and characteristic doesn’t change during the process) and given media (assuming the abrasiveness doesn’t change), the end result is dependent only upon the media’s surface speed, the contact pressure of the media (contact force divided by contact area), and the rate at which the media is presented to the workpiece (feedrate). Most of these “feed and speed” variables are readily available...
Open the catalog to page 3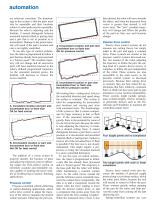
automation are relatively consistent. The disadvantage to this system is that the parts must also be repeatable and their locations relative to robot path must be repeatable. Because the robot is adjusting only the feedrate, it cannot distinguish between unwanted material (flash or parting line) and a part that is out of position or is inconsistent. Damage to the parent material will result if the part’s location and size is not tightly controlled. To use this type of control architecture, the robot is programmed to follow a part that has already been processed and is a “known good.” The resultant...
Open the catalog to page 4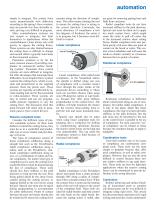
simple to integrate. The contact force varies proportionally with deflection according to the spring’s force constant, and can provide less than desirable resuits, proving very difficult to program. Mass counterbalance systems are also simple to integrate, but limit themselves to applications where the counterbalance’s mass always acts with gravity to oppose the cutting forces. These systems are also limited because the cutting force is difficult to change and inertial effects typically limit them to floor-mounted systems. Pneumatic actuation is by far the most common means of providing compliance...
Open the catalog to page 5
ing of active and passive force control techniques how they are applied to compliant tools. Choosing the correct system is dependent upon what the application is, but more importantly, what the end result must be. If tolerances are very tight, then an active force control system using ATI’s Six-Axis Force Torque Sensor is justifiable. If the tolerances are loose, then the more cost-effective passive force controlled VersaFinish or Flexdeburr will suffice. All of these factors must be thoroughly examined and defined prior to purchasing any type of robotic compliant deburring system. ATI Industrial...
Open the catalog to page 6All ATI Industrial Automation catalogs and technical brochures
 Manual tool changers
2 Pages
 Robotic & CNC Deburring Tools
12 Pages
 Collision Sensor catalog
8 Pages
 Utility coupler
2 Pages
 Corporate overview
8 Pages


- Coupler
- Tool changer
- Deburring tool
- Robotic tool changer
- Automatic tool changer
- Pneumatic tool changer
- Metal deburring tool
- Mechanical coupler
- Electronic coupler
- Coupler for industrial applications
- Force and torque sensor
- Steel deburring tool
- Pneumatically-actuated tool changer
- Automatic deburring tool
- Compact coupler
- Manual tool changer
- 6-axis force and torque sensor
- Analog force and torque sensor
- I/O coupler
- Pneumatic deburring tool