
- Catalogs
- ATESTEO GmbH & Co. KG
- Manual DF dual series
- Company
- Products
- Catalogs
- News & Trends
- Exhibitions
Manual DF dual series
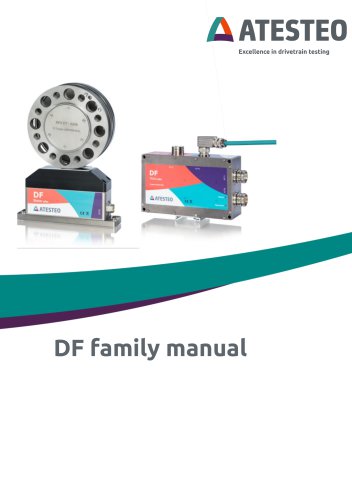
Manual DF dual series
This manual provides comprehensive guidance for the ATESTEO DF series, including product variants DF plus, DF ibex, and DF dual. It emphasizes the importance of understanding safety instructions and the potential dangers associated with the DF series. The document also highlights the manufacturer's right to make technical changes without explicit documentation.
The manual includes a detailed change log from versions 2.3 to 2.9, noting significant updates such as the addition of product variants, improvements in CAN bus connections, and updates to the web interface and safety features.
Lists the latest software versions for various components like TCU5 firmware and rotor firmware, indicating that software updates occur more frequently than manual updates.
Details the contact information for ATESTEO GmbH & Co.KG, including service contact details.
Mentions compliance with FCC rules for certain components of the DF series, subject to specific operational conditions.
Includes general safety instructions, appropriate use guidelines, and responsibilities of operators. It also covers transport, storage, and safety notes for assembly and operation.
Provides technical data and system overviews, including electrical, mechanical, and functional areas. It also covers calibration documents and telemetry measurement ranges.
Details procedures for transporting, lifting, and mounting components like the rotor and stator. It also includes grounding and wiring instructions.
Guides the initial setup, including network connections and web interface usage. It covers settings for power supply, alarms, torque meter, and more.
Describes pin allocations for power supply, frequency output, and other connections.
Offers recommendations for zero adjustment and includes tables of figures and tables for reference.
This document outlines the compliance requirements for radio apparatus, including FCC and ISED regulations. Devices must not cause interference and must accept any interference received. Specific labeling requirements for components are mentioned, and installation guidelines require a minimum distance of 50 cm between the equipment and users.
Electrical and electronic products must be disposed of according to specific regulations to prevent environmental damage. Packaging is recyclable, and disposal varies by country. The European Directive 2002/96/EC applies to waste electrical and electronic equipment.
The package includes a torque meter, stator, Torque Control Unit (TCU), connectors, an operating manual, and a test report. An optional speed detection system is available.
The DF-series measures torque dynamically with high resolution. It includes a torque measuring flange, stator, and evaluation unit. The system uses bidirectional telemetry and inductive power supply. Data is transmitted via RS422 interface, and the system can be configured via a web interface.
Safety instructions emphasize the importance of reading the manual before use. Only qualified personnel should perform maintenance. Modifications without ATESTEO's consent void warranties. Safety measures include proper installation and use of protective equipment.
The system operates on a 24V DC power supply with various output options. It supports CAN interface and has specific temperature and protection class ratings. The document includes detailed technical specifications for operation and storage conditions.
Figures illustrate the electrical system and central cable setup, providing a visual guide to the system's components and connections.
The document provides a comprehensive overview of the ATESTEO DF family manual, version 2.9, detailing the system's functional, mechanical, and location aspects. It includes descriptions of the system's components such as the rotor, TCU, and stator, along with the positioning of nameplates and FCC/ISED labels.
The DF series measuring system is accompanied by a test report indicating sensitivity in digits/Nm. Optional calibration protocols are available, and calibration can be performed in-house according to DIN 51309 or VDI/VDE 2646 standards, accredited by DAkkS.
The DF torque meters offer single and dual range telemetry options. Single range meters have one amplifier, while dual range meters have two, allowing for parallel signal transfer. The document outlines the available output signals and the procedure for switching measurement ranges, emphasizing the importance of pre-test range selection.
Key functions include zero adjustment, test signals, IP address reset, filtering, and a fail-safe channel for overload analysis. The document provides detailed instructions for each function, including LED coding for system status.
The installation section covers transport, lifting, and mounting procedures for the rotor and stator. It includes detailed dimensions and specifications for various components, as well as guidelines for proper alignment and grounding.
Specific instructions are provided for mounting the rotor and stator, including the use of torque wrenches and the importance of correct positioning. The document also details the components of the ibex/dual stator and the necessary mounting distances.
The DF family manual version 2.9 provides detailed instructions for the mechanical and electrical installation of the DF ibex/dual system, including the stator components, speed-measuring system, evaluation unit, and grounding requirements.
There are two methods for mounting the stator: separating it into three components for step-by-step installation (recommended) or installing it as one part (not recommended). The upper part of the stator ring contains a strong magnet, which must be kept away from magnet-sensitive objects.
The manual outlines the process of separating and installing the stator components, including the use of lock washers for electrical connections and securing the stator to a vibration-resistant base plate. It also details the alignment of the stator with the rotor and the necessary mounting distances.
An optional magnetic speed detection system is described, including the alignment of the speed sensor and the significance of LED indicators for signal strength.
The evaluation unit should be installed in a dry environment and can be mounted on a DIN rail or metal plate. Proper grounding is essential to avoid electromagnetic interference.
A point-to-point grounding concept is recommended to prevent electromagnetic emissions. Power cables should be separated from sensitive signal lines.
The manual specifies the types of cables and connectors to be used for the evaluation unit and emphasizes the importance of shielding to comply with EMC standards.
Before initial power-up, ensure all components are correctly connected. The system uses LEDs to indicate operating status, and a web interface is used for configuration.
Instructions are provided for setting up network connections and configuring IP settings for the TCU5.
The web interface is used for device management and measurement configuration. It includes features for zero adjustment and signal testing.
The document provides guidance on using the ATESTEO DF family manual, version 2.9, focusing on the web interface for monitoring and controlling torque sensors. The navigation menu can be accessed by clicking the company logo, and the signal bar is displayed on the right side of the website.
Torque, acceleration, speed, and temperature inputs are graphically represented, but not in real-time, which may cause delays. The system's connection state and alarm states are monitored, with alarms triggered if thresholds are exceeded.
The torque sensor's supply voltage is crucial for optimal performance, ideally set at 8.0 V ±0.5 V. The power supply can be adjusted manually or automatically, with interruptions possible if the voltage fluctuates beyond acceptable limits.
Alarm thresholds for speed and torque can be configured. The torque meter display is locked for input, with settings adjustable in the menu. Output channels can be switched, affecting analogue and frequency outputs.
The speed detection system parameters are adjustable, with rotation angles calculated using two methods. The resolution depends on the rotor's impulse number, and zero-point adjustments can be triggered via the web interface or CAN bus.
Analog output voltage ranges and frequency settings can be adjusted, with calibration recommended only for trained personnel. The TCU provides a digital IIR filter for torque input channels, with cut-off frequencies ranging from 1 Hz to 4000 Hz.
The CAN interface settings include scaling factors, transmission states, and configuration of measurement and debug signals. CAN messages can be formatted in Intel or Motorola formats, with up to four messages configurable. Debug signals help monitor system performance, with error counters indicating transmission issues.
Various CAN commands can be received for zero adjustments, test signals, counter resets, and power supply management, ensuring comprehensive control over the system's operation.
The document outlines the CAN command list, specifying that commands must be included in the first 4 bytes of data. It distinguishes between Motorola and Intel formats and describes the response message structure, which includes an identifier and state parts.
The status word uses all 8 bytes of a CAN message, divided into two parts, each 32 bits long. The document provides a detailed table of bit functions, including connectivity, system supply, test/service, and alarm/error categories.
Instructions for configuring Ethernet settings for the embedded measurement system are provided. It warns that improper settings can damage the device, necessitating factory reprogramming. A CAN command can query forgotten network settings.
Initial access credentials are provided, with guidelines for password creation. It emphasizes the importance of recording passwords securely.
The service section includes firmware version details and manufacturer contact information. It allows exporting system parameters for service purposes.
The document details pin allocations for various connectors, including power supply, frequency output, and CAN/Alarm/Input. It specifies signal descriptions, cable colors, and cross-sections. Important notes on connecting outputs to RS422 receivers and the consequences of incorrect connections are highlighted.
Frequency outputs represent torque outputs, and speed-pulses outputs represent speed tracks. The document advises on proper connections to avoid damage.
A step-by-step procedure for resetting the IP configuration to factory settings is provided, emphasizing security measures.
Descriptions of analog outputs for torque, speed, and rotation angle are included. Alarm outputs indicate when thresholds are exceeded, with reset procedures detailed.
The document explains channel selection for dual variant torque meters, including signal definitions and startup checks.
Instructions for Ethernet connections using standard cables and special connectors for permanent installations are provided. Central cable pin allocations are detailed for indoor use.
The document outlines the specifications for double telemetry systems, where Channel 1 corresponds to the measuring channel with the lower rated torque, and Channel 2 corresponds to the channel with the higher rated torque. It also includes a table (Table 24) detailing specific data related to X775/X776.
The document provides detailed recommendations for zero adjustment of torque measuring systems. It highlights that zero drift can occur due to thermal influences, hysteresis, aging, and lateral forces. Each of these factors is explained, with emphasis on maintaining the sensor within calibration tolerance.
Zero drift can occur due to temperature fluctuations, despite complex temperature compensation. The document specifies a temperature stability of 0.05%/10K.
Drift can occur if a sensor is mostly loaded in one direction during a test. This is attributed to the natural hysteresis of the sensor and strain gauges.
Long-term dynamic loading can cause zero drift, affecting sensor sensitivity. However, ATESTEO sensors have low drift due to low sensitivity at nominal torque.
Lateral forces from components linked to the sensor can affect the measuring signal, but proper installation minimizes this influence.
Zero-reset is advised only when the real load is zero. If a significant zero shift is observed, the torque meter should be checked by ATESTEO.
The document includes a comprehensive list of figures and tables, detailing system overviews, component dimensions, and technical data.
For further information or service requests, contact details for ATESTEO GmbH & Co. KG are provided.
Catalog excerpts
Excellence in drivetrain testing
Open the catalog to page 1
Your contact for service requests ATESTEO GmbH & Co. KG Konrad-Zuse-Str. 3 52477 Alsdorf Germany ATESTEO DF family manual - Version 2.9
Open the catalog to page 2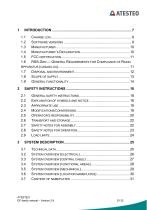
1.6 RSS-Gen — General requirements for Compliance of Radio DF family manual - Version 2.9
Open the catalog to page 3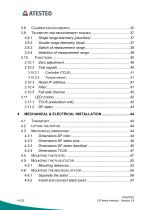
ATESTEO DF family manual - Version 2.9
Open the catalog to page 4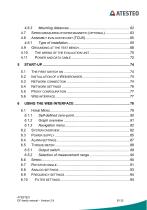
DF family manual - Version 2.9
Open the catalog to page 5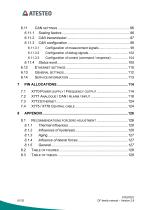
ATESTEO DF family manual - Version 2.9
Open the catalog to page 6
Thank you for choosing an ATESTEO quality product. Please read the system description carefully so you make the most of the versatile features of your product. This operating manual is a component of the DF-series and should always be carefully kept with the DF series until it is disposed of. It is impossible to eliminate every danger to people or material that the DF series might present. For this reason, every person working at the DF series or is involved in its transport, setting up, control, maintenance or repair must be properly instructed and be informed of the possible dangers. For this...
Open the catalog to page 7
AATESTEO kind of suggestion or criticism that you may wish to make. Please let us know or write to us. This will help us to make the operating instruction still more user-friendly in taking account of your wishes and requirements. • Product variants ibex and dual added • Remark to connect Digital GND for CAN bus added • Central cable pin count mistakes removed • 11R filter explained more detailed • Screenshots of web interface updated • Fail safe channel: Description updated and cleaned up • CAN debug signal description added • Format fixed for better readability • Format review • Update of drawing...
Open the catalog to page 8
Introduction AATESTEO • Information about FCC updated. • Mounting distances of speed detection updated. • Information regarding ping protocol added. • Description of some functions added in separate chapters. • Description of zero adjustment added. • Inline concept description removed. • Document structure updated. • Lifting & transport remarks for rotors added. • IP reset description updated. • Technical data added. • Safety remarks enhanced (Fuse in building electricity, operation only inside, avoid oscillations). • Pin assignment of central cable updated (X775/X776 instead of X773). • CAN...
Open the catalog to page 9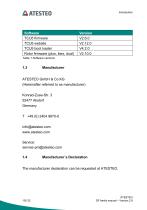
Table 1 Software versions 1.3 Manufacturer ATESTEO GmbH & Co.KG (Hereinafter referred to as manufacturer) Konrad-Zuse-Str. 3 52477 Alsdorf Germany The manufacturer declaration can be requested at ATESTEO. ATESTEO DF family manual - Version 2.9
Open the catalog to page 10
The components of DF series mentioned in Table 2 comply with part 15 of the FCC Rules. Operation is subject to the following two conditions: (1) This device may not cause harmful interference, and (2) this device must accept any interference received, including interference that may cause undesired operation. Product changes are only allowed with the acceptance of ATESTEO. The FCC ID or a unique component ID is labelled on the components (see 3.6 and 3.7). This device contains licence-exempt transmitter(s)/receiver(s) that comply with Innovation, Science and Economic Development Canada’s licence-exempt...
Open the catalog to page 11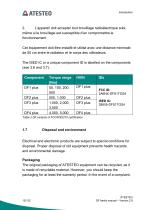
2. L’appareil doit accepter tout brouillage radioelectrique subi, meme si le brouillage est susceptible d’en compromettre le fonctionnement Cet equipement doit etre installe et utilise avec une distance minimale de 50 cm entre le radiateur et le corps des utilisateurs. The ISED IC or a unique component ID is labelled on the components (see 3.6 and 3.7). Table 2 DF variants of FCC/RSS210 certification Electrical and electronic products are subject to special conditions for disposal. Proper disposal of old equipment prevents health hazards and environmental damage. The original packaging of ATESTEO...
Open the catalog to page 12
Introduction AATESTEO the torque flange, as well as the accessories, must be returned in the original packaging. Due to ecological aspects, the return of the empty packaging should be waived. Electrical and electronic devices bearing the symbol / ^'i'\ are subject to the European Directive 2002/96 / EC on waste electrical and electronic equipment. The symbol indicates that waste equipment that is no longer usable must be disposed of separately from regular household waste in accordance with European environmental protection and recycling regulations. However, the disposal regulations vary from...
Open the catalog to page 13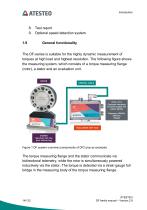
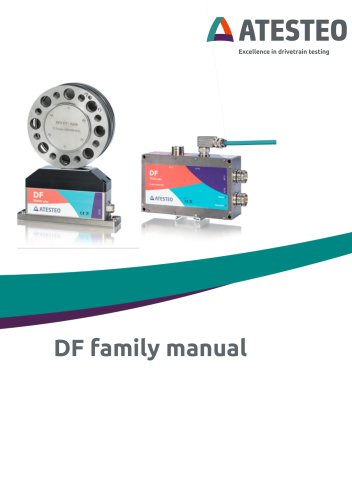
AATESTEO Introduction 9. Optional speed detection system The DF-series is suitable for the highly dynamic measurement of torques at high load and highest resolution. The following figure shows the measuring system, which consists of a torque measuring flange (rotor), a stator and an evaluation unit. CENTRAL CABLE X770 / X771 Customer interfaces for power supply and output signals ibex/dual: with ring plus: without ring Figure 1 DF system overview (components of DF2 plus as example) The torque measuring flange and the stator communicate via bidirectional telemetry, while the rotor is simultaneously...
Open the catalog to page 14
The electrical difference voltage of the full bridge is amplified in the torque measuring flange and digital data words are converted. For error-free signal transmission, the data words are supplemented by a checksum and transmitted modulated to the stator. The stator demodulates the data words and transmits them via an RS422 interface to the evaluation unit. In the evaluation unit, the signals can additionally be filtered with an adjustable low-pass filter. The evaluation unit also offers the connection options for the system peripherals. These include a CAN interface, two frequency outputs...
Open the catalog to page 15
sent from the measuring flange, which enables automatic configuration of the evaluation unit. The new measuring flange is immediately ready for use. Optionally, the measuring system can be equipped with a speed measurement. For the capture, a magnet ring on the rotor and a sensor head on the stator are in use. The magnetic ring has two pole tracks, which are offset by 90 ° to each other. So the speed can be determined as well as the direction of rotation. The two tracks can be tapped as RS422 signals at the system outputs. In addition, the speed is measured in the evaluation unit and made available...
Open the catalog to page 16All ATESTEO GmbH & Co. KG catalogs and technical brochures
 Flyer DF-family
4 Pages
 Data sheet F4 RTS
7 Pages
 Data sheet DF4 ibex
21 Pages
 Data sheet DF5 ibex
21 Pages
 Data sheet F4xS
21 Pages
 Data sheet DF5 dual
23 Pages
 Data sheet DF4 dual
23 Pages
 Data sheet DF3 dual
23 Pages
 Data sheet DF2 dual
23 Pages
 Data sheet DF1 dual
23 Pages
 Manual CapSync HVT
68 Pages
 Data sheet CapSync HVT
7 Pages
 Manual IRTS series
116 Pages
 Data sheet IRTS-P
11 Pages
 Manual VETAS 3
30 Pages
 Manual VECTO
26 Pages
 Manual steering wheel
17 Pages
 Data sheet steering wheel
9 Pages
 Manual DST series
69 Pages
 Data sheet DST series
13 Pages
 Data sheet TiS Z50
20 Pages
 Manual T series
124 Pages
 Data sheet TeS Z50
21 Pages
 Manual RT11 series
124 Pages
 Data sheet RT11eS-B
20 Pages
 Data sheet RT11eS
17 Pages
 Manual HSTTeS series
124 Pages
 Data sheet HSTTeS series
20 Pages
 Data sheet F23 RTS
7 Pages
 Data sheet F3 RTS
7 Pages
 Data sheet F5xS
18 Pages
 Data sheet F34xS
21 Pages
 Data sheet F3xS
27 Pages
 Data sheet F23xS
21 Pages
 Manual Fx series
124 Pages
 Data sheet F2xS
35 Pages
 Data sheet F1xS
27 Pages
 Data sheet F0xS
51 Pages
 Data sheet F0xS-SV
27 Pages
 Data sheet DF RTS
11 Pages
 Data sheet DF plus HS
20 Pages
 Manual DF plus series
132 Pages
 Data sheet DF plus series
41 Pages
 Manual DF ibex series
132 Pages
 Data sheet DF3 ibex
21 Pages
 Data sheet DF2 ibex
21 Pages
 Data Sheet DF1 ibex
21 Pages
- ATESTEO dynamic torque sensor
- ATESTEO rotary torque sensor
- ATESTEO analog torque sensor
- ATESTEO strain gauge torque sensor
- ATESTEO digital torque sensor
- ATESTEO non-contact torque sensor
- ATESTEO high-accuracy torque sensor
- ATESTEO DC torque sensor
- ATESTEO torque sensor with flange connection
- Compact torque sensor
- Modular temperature control
- ATESTEO voltage output torque sensor
- USB torque sensor
- 12VDC torque sensor
- Flange-mounted torque sensor
- ATESTEO test bench torque sensor
- ATESTEO torque sensor with integrated electronics
- Custom torque sensor
- Torque sensor with rotary encoder